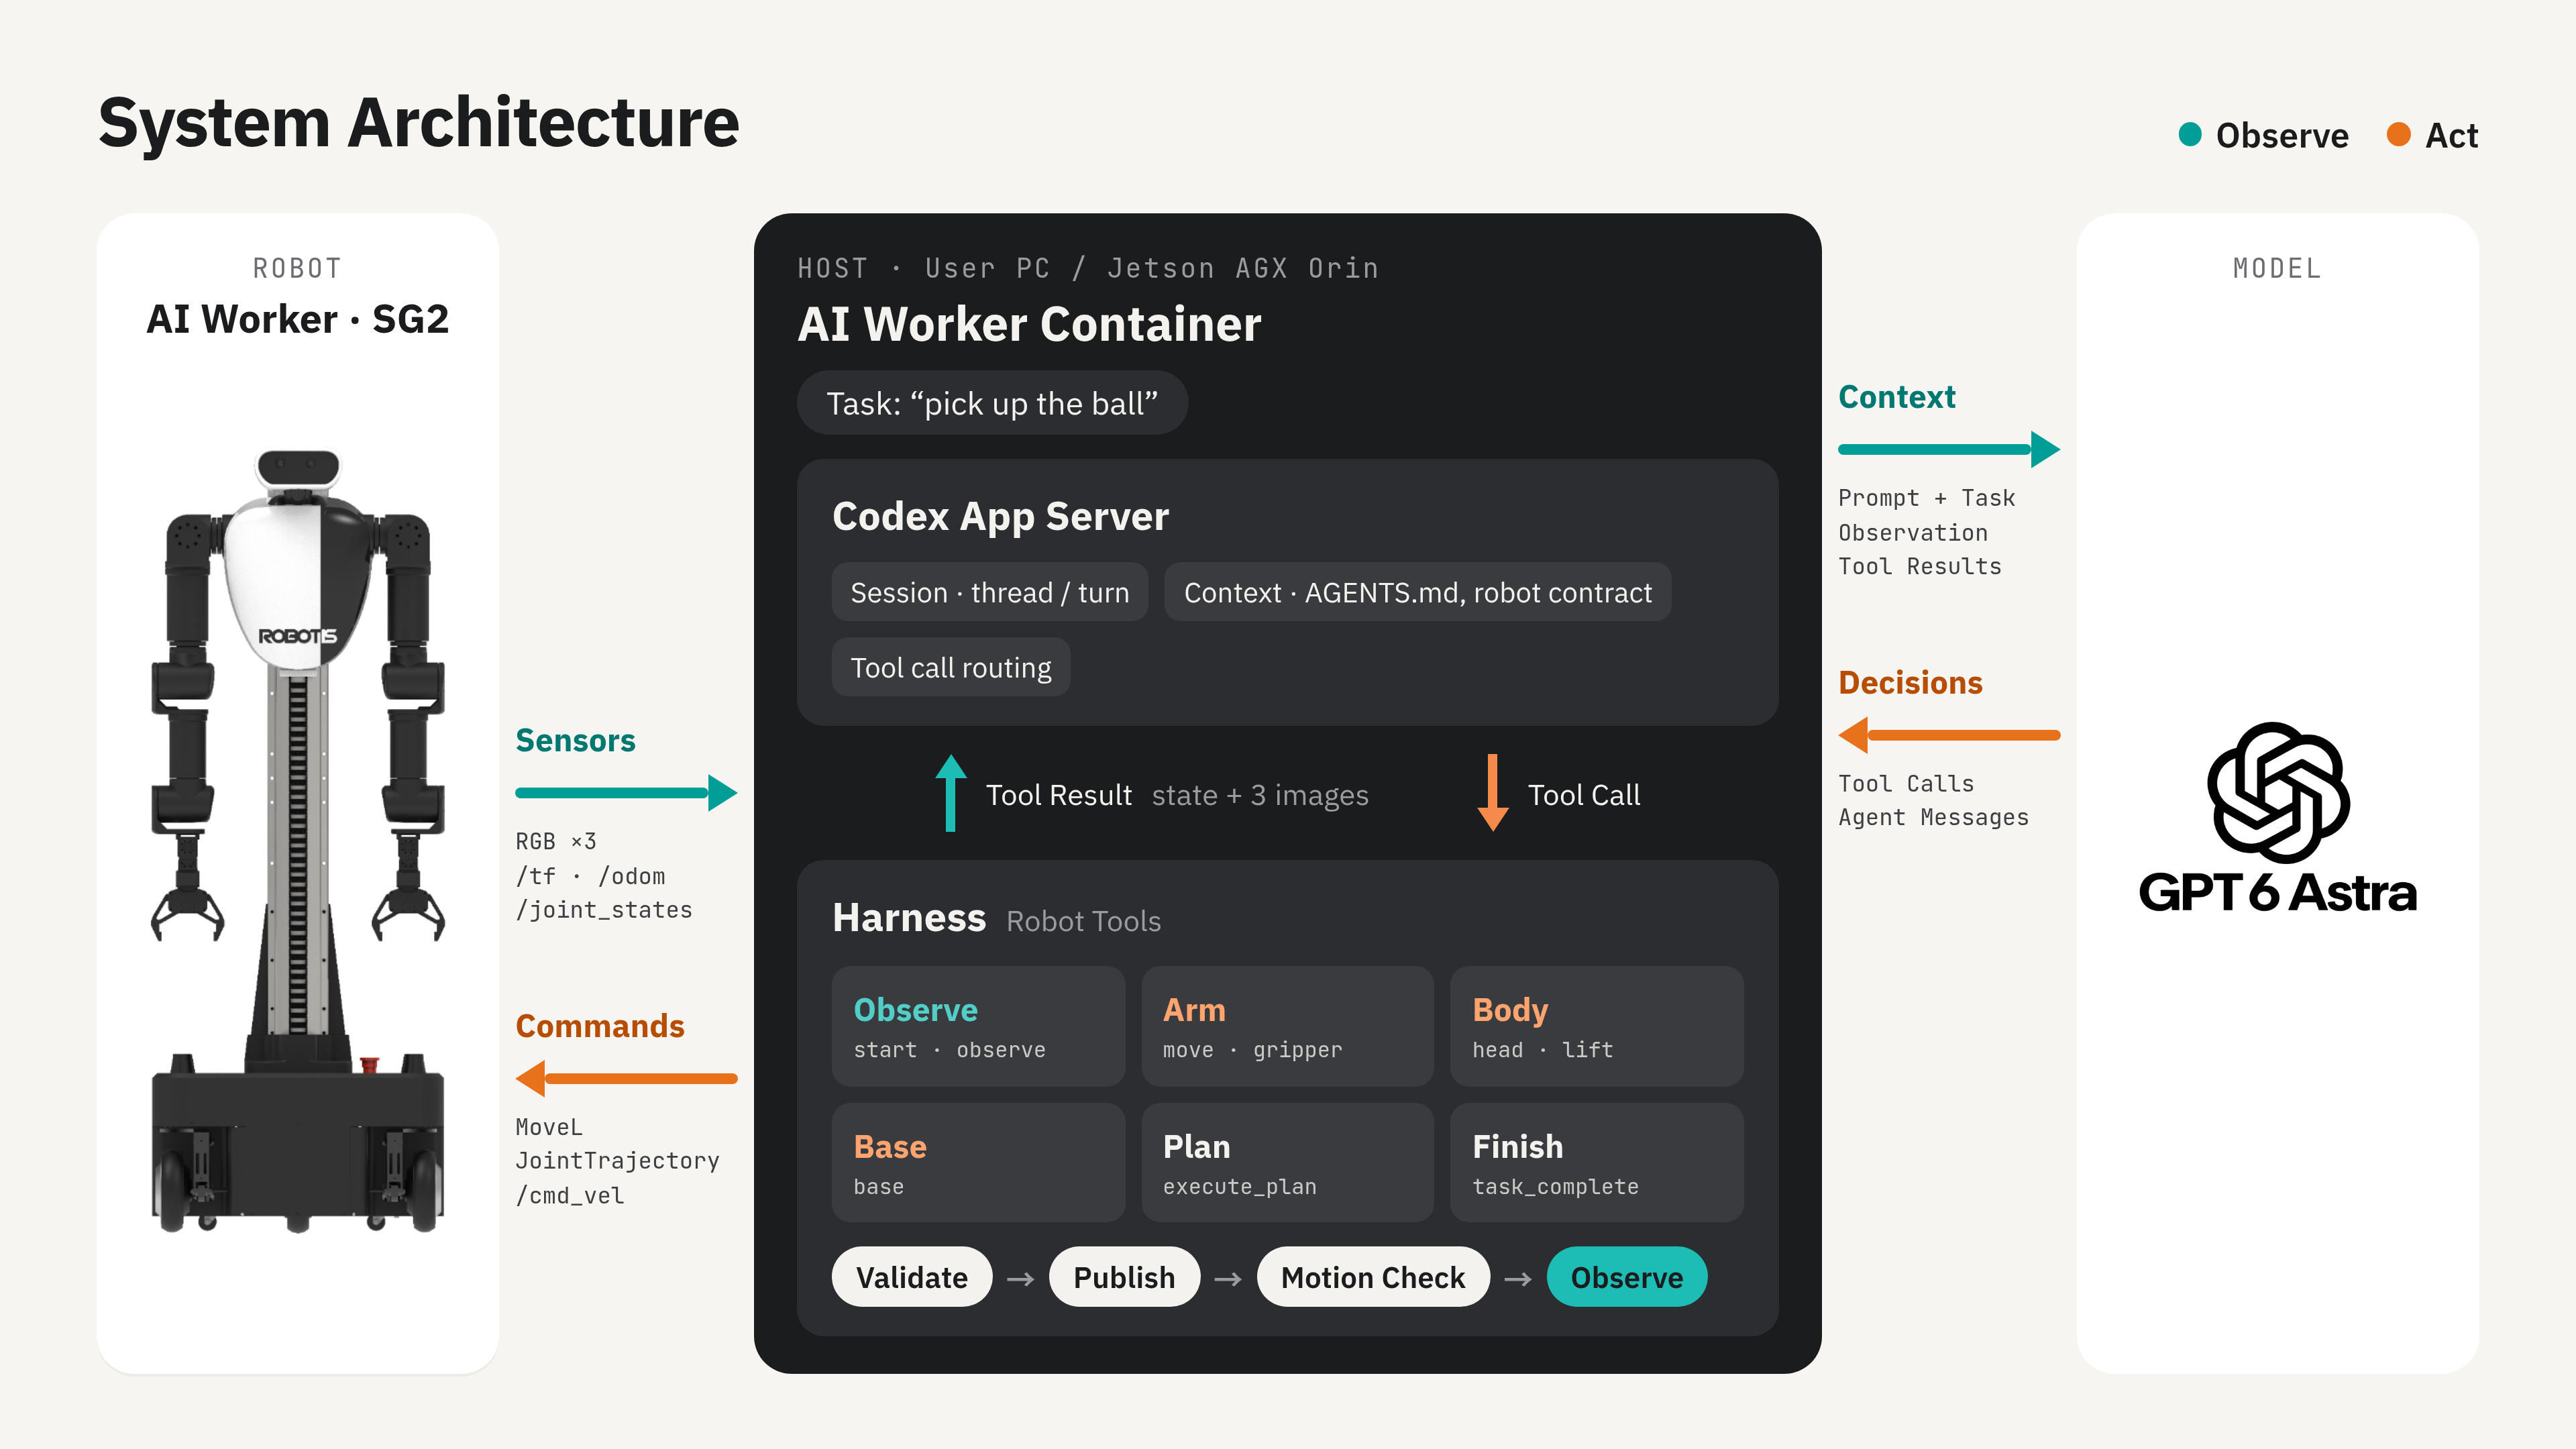
GPT-6 Astra on the AI Worker
Connect GPT-6 Astra to AI Worker through the Codex App Server and ROS 2 to carry out natural-language instructions.
로봇을 움직이는 기술과 실험을 만나보세요. 로봇과 기술 태그로 관심 있는 스토리를 찾아보세요.
12개의 스토리
Connect GPT-6 Astra to AI Worker through the Codex App Server and ROS 2 to carry out natural-language instructions.
Use fingertip pressure to help ACT interpret contact when the hand hides objects during pick-and-place.
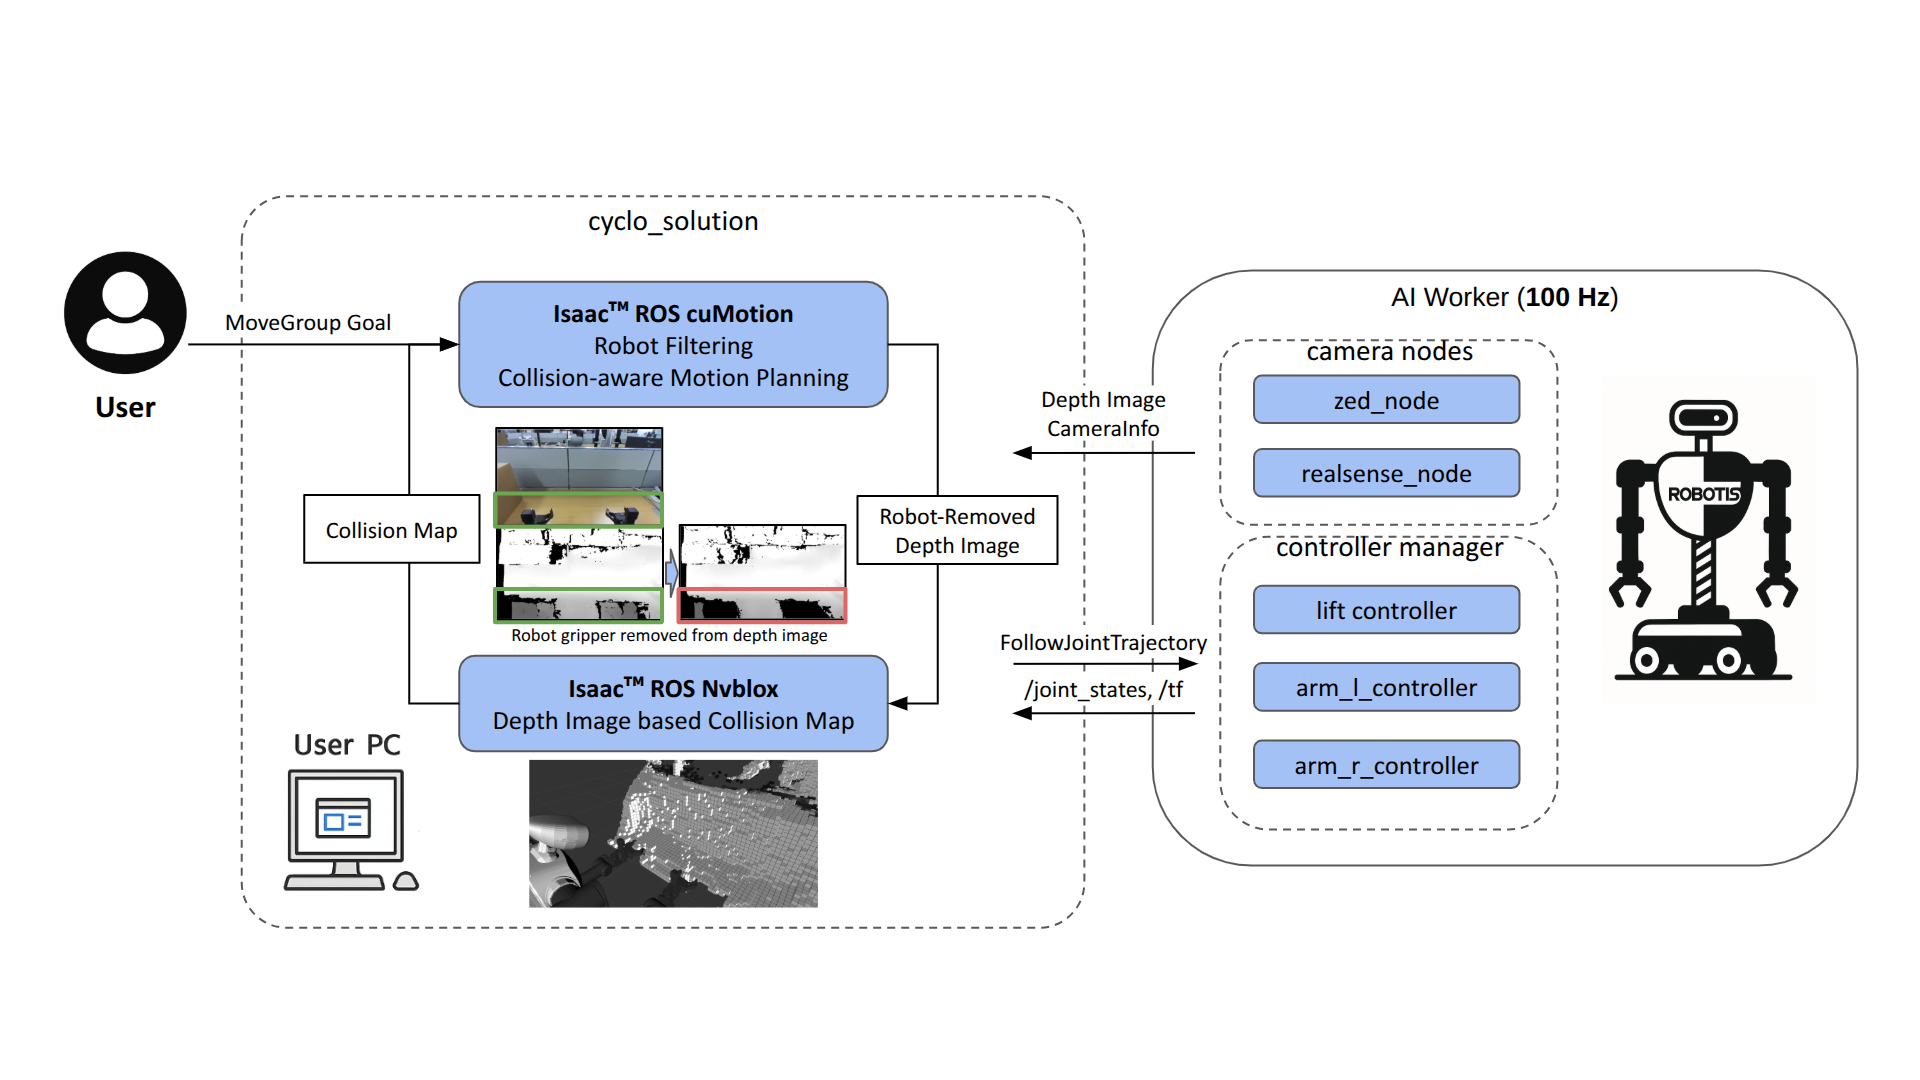
Collision-aware motion planning with NVIDIA Isaac ROS cuMotion, Nvblox ESDF mapping, and object attachment.
From whole-body motion to manipulation: building humanoid skills with reinforcement learning, motion generation, and NVIDIA GR00T.
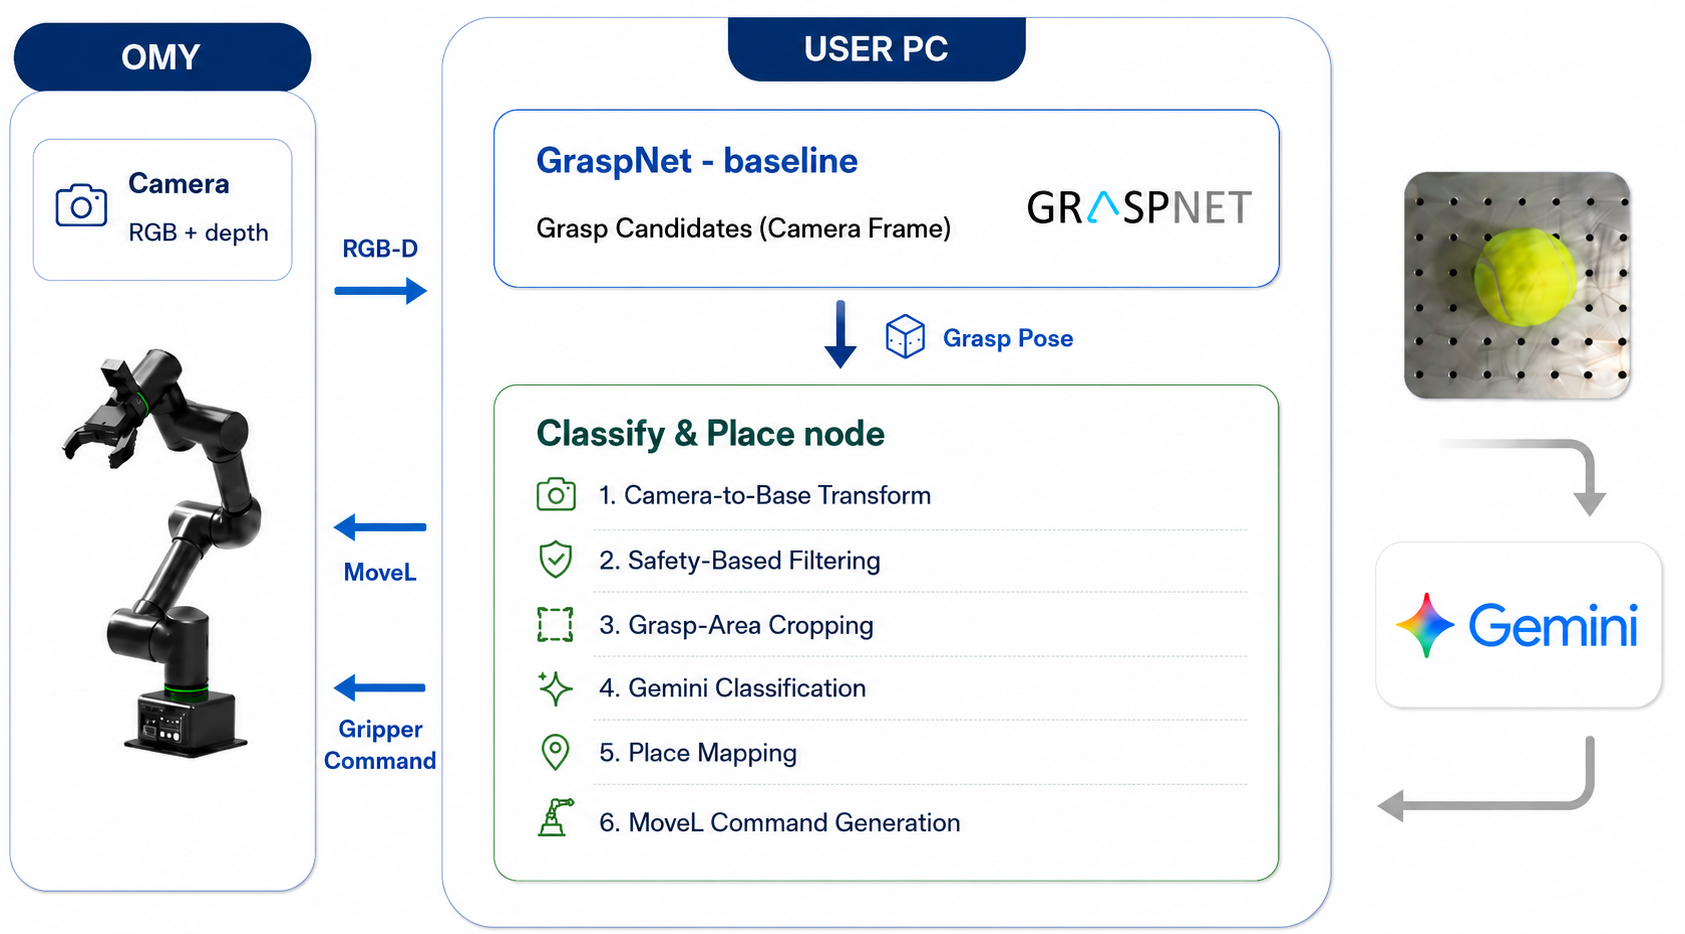
Combine GraspNet point cloud grasp inference and Gemini object classification for pick-and-place on OMY.
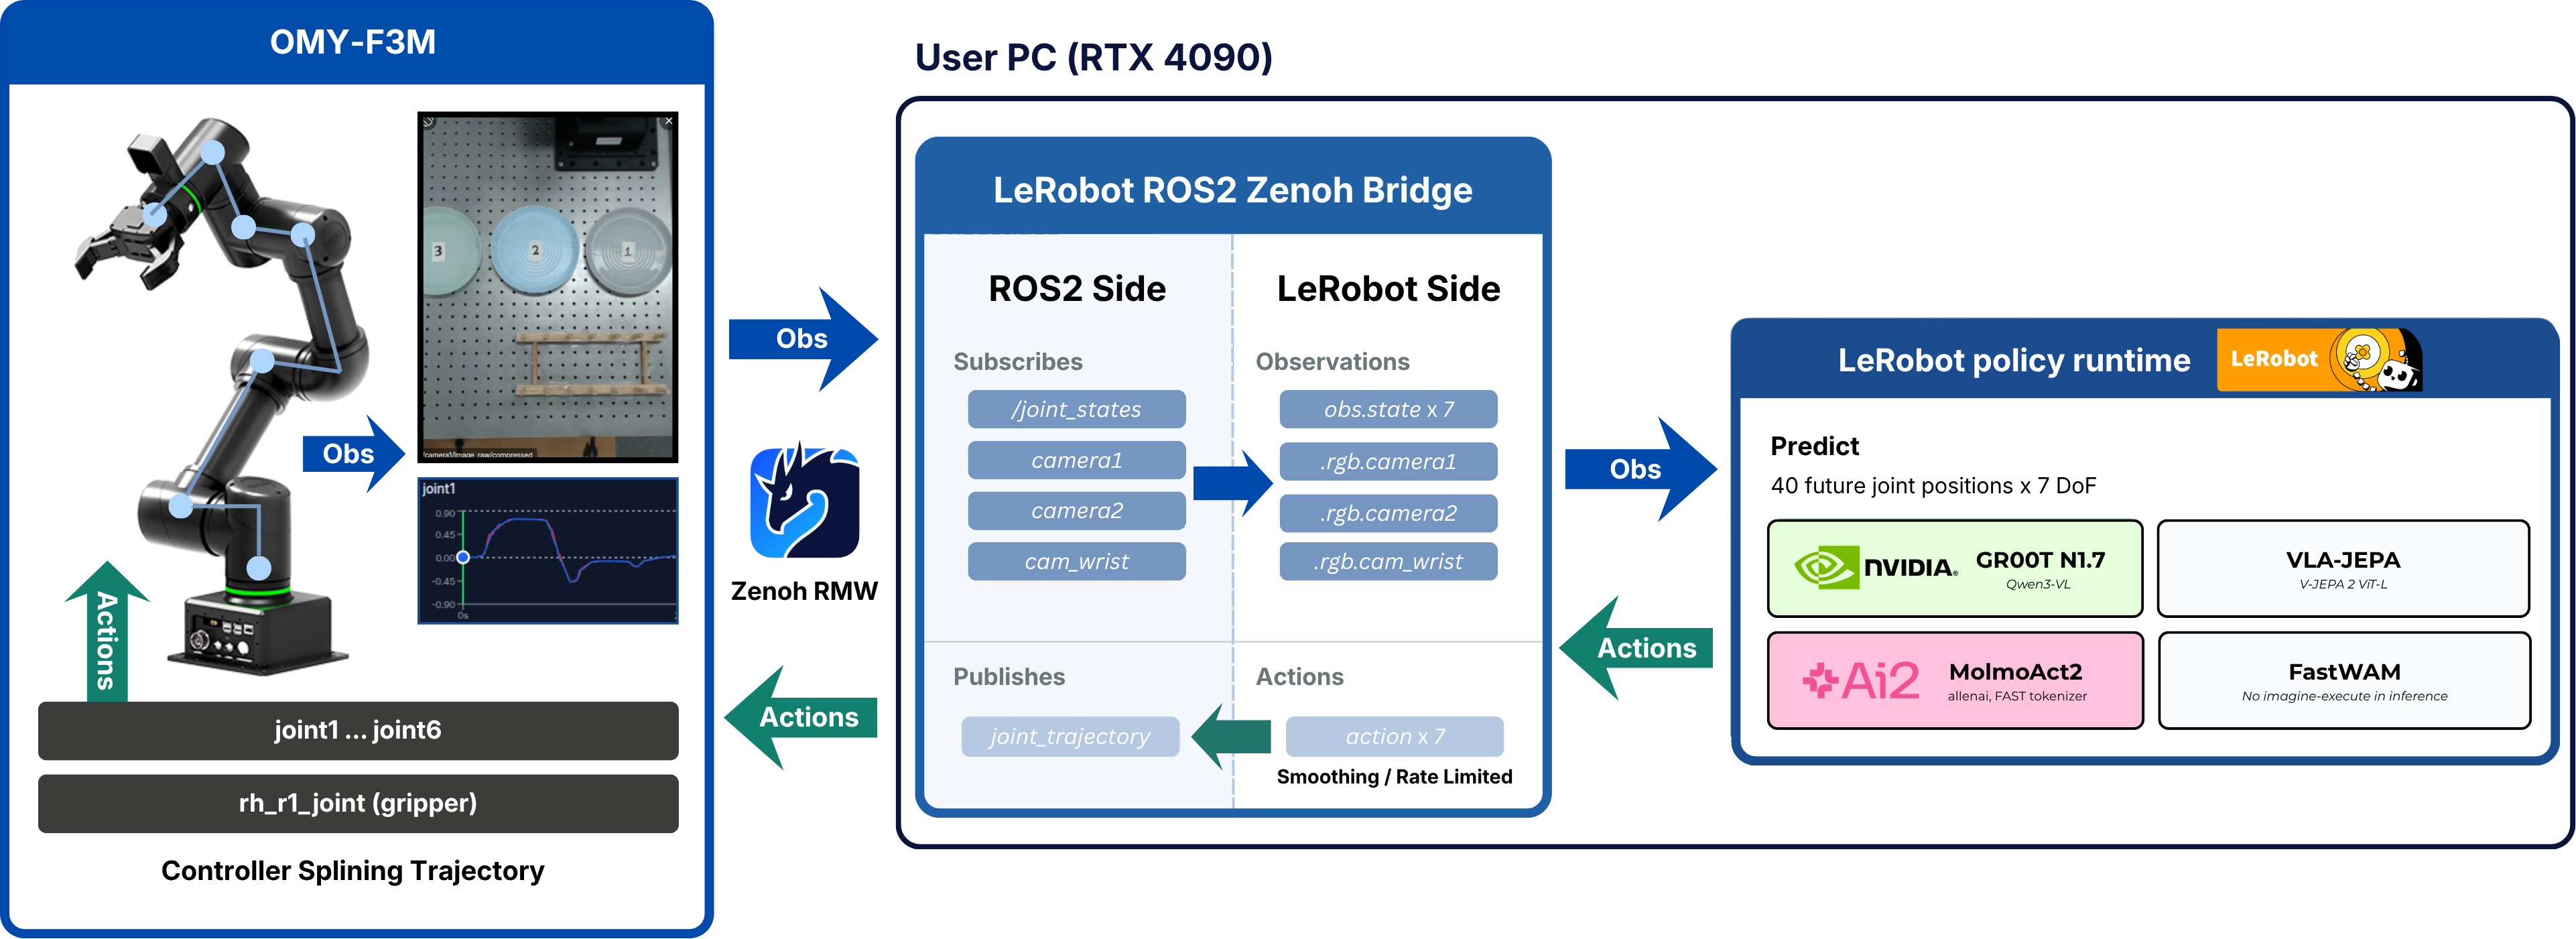
Run GR00T N1.7, MolmoAct2, VLA-JEPA, and FastWAM on OMY with LeRobot and a ROS 2 Zenoh bridge.
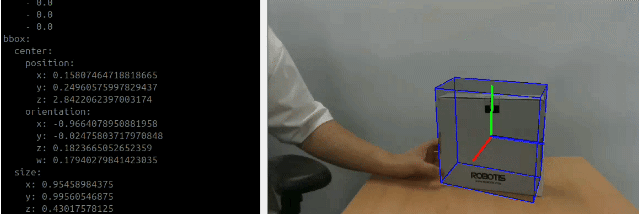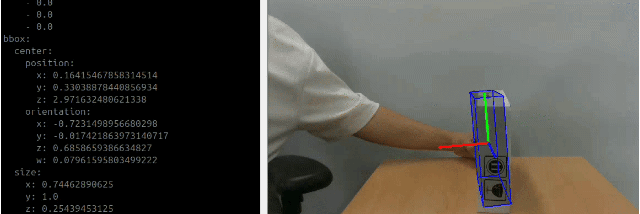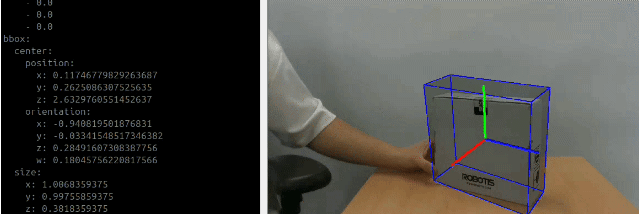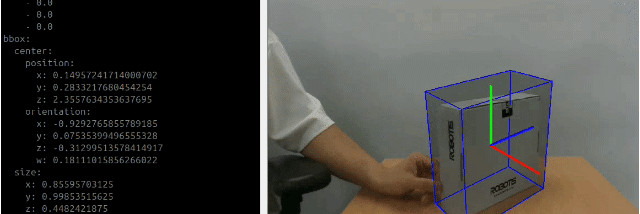
Build pick-and-place with Isaac ROS CenterPose, 6DoF object pose estimation, and a ZED camera.
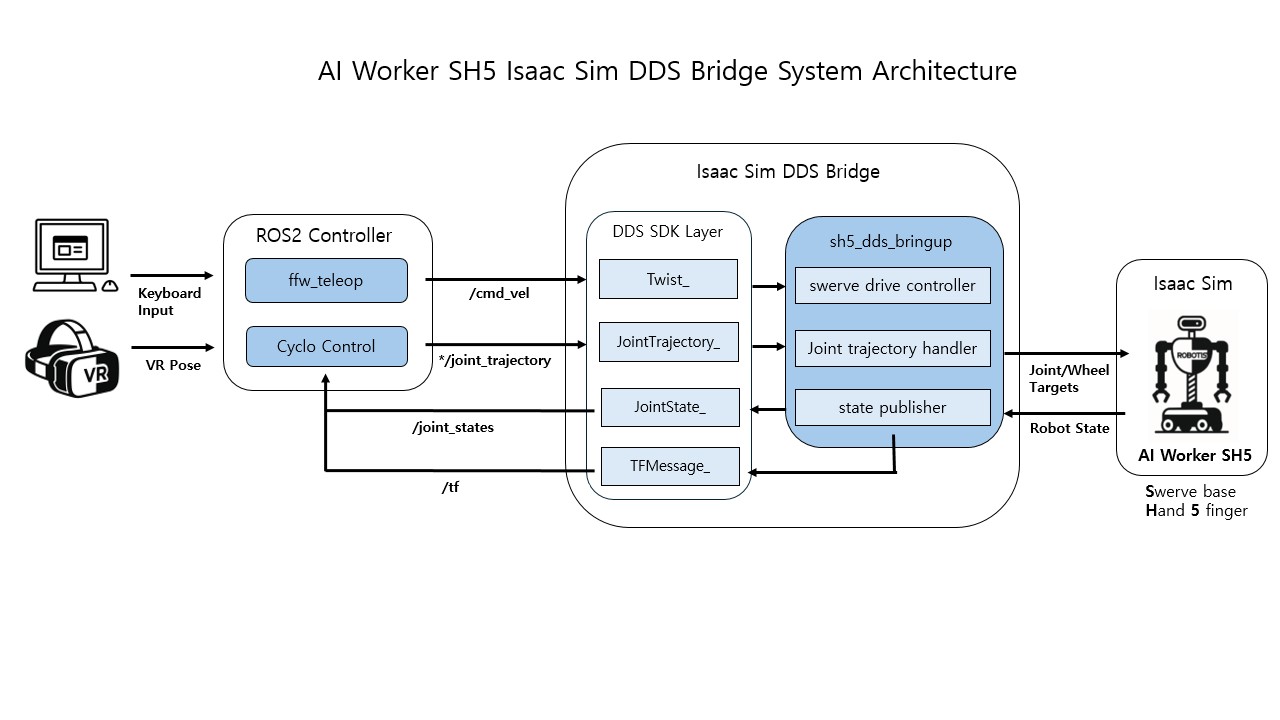
Explore VR and keyboard teleoperation, pick-and-place, and mobile manipulation in Isaac Sim.
Train AI Worker to sort convenience store items with imitation learning and NVIDIA GR00T N1.5.
Build autonomous navigation with ROS 2 Nav2, holonomic driving, and custom behavior trees.
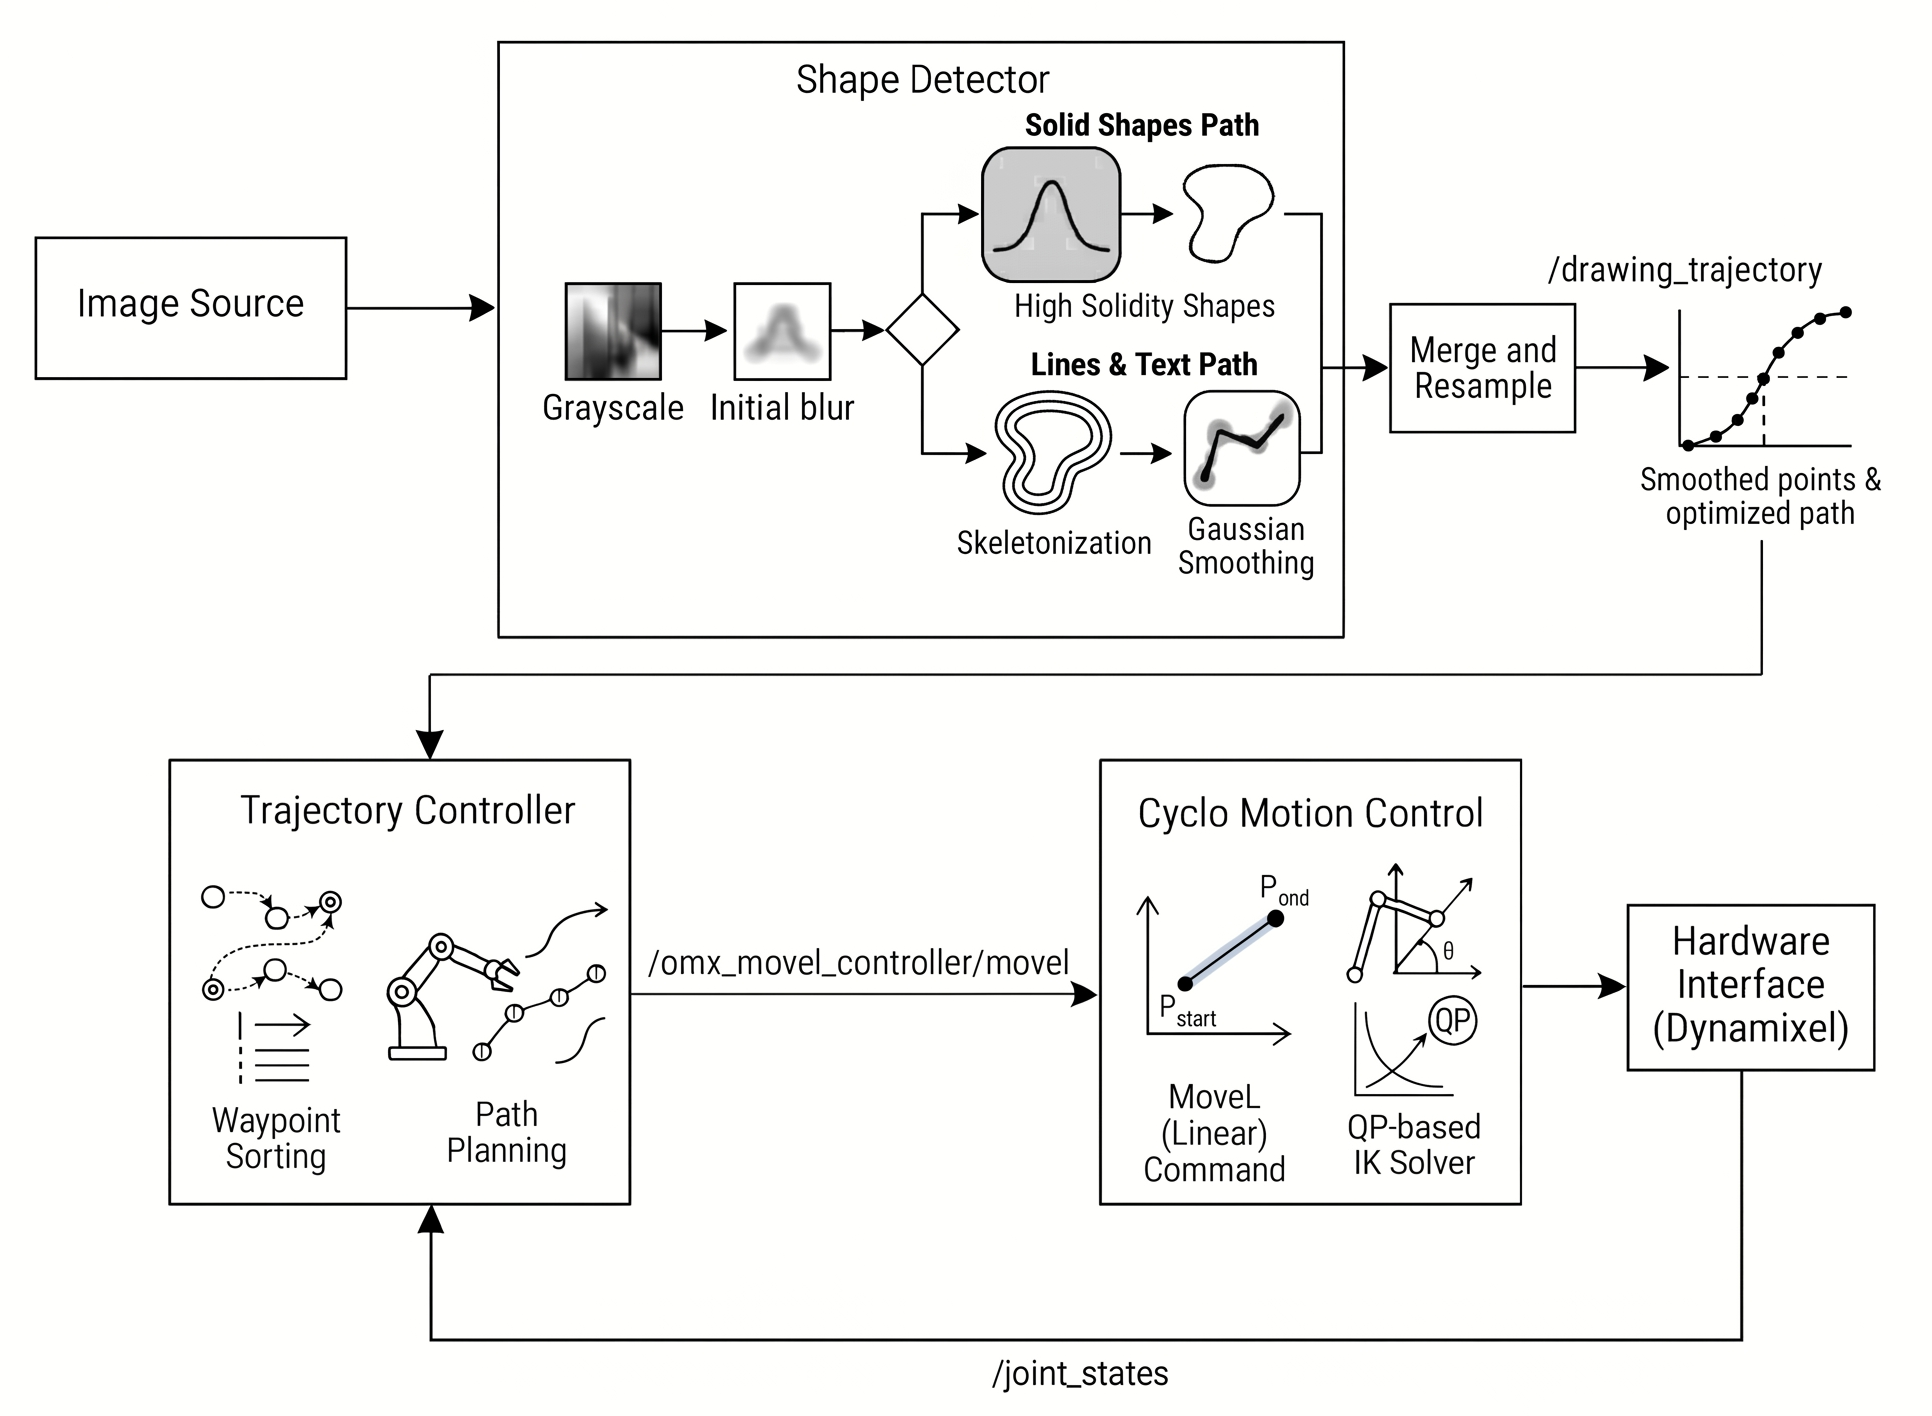
Turn drawings into precise OMX motion with an end-to-end drawing pipeline.
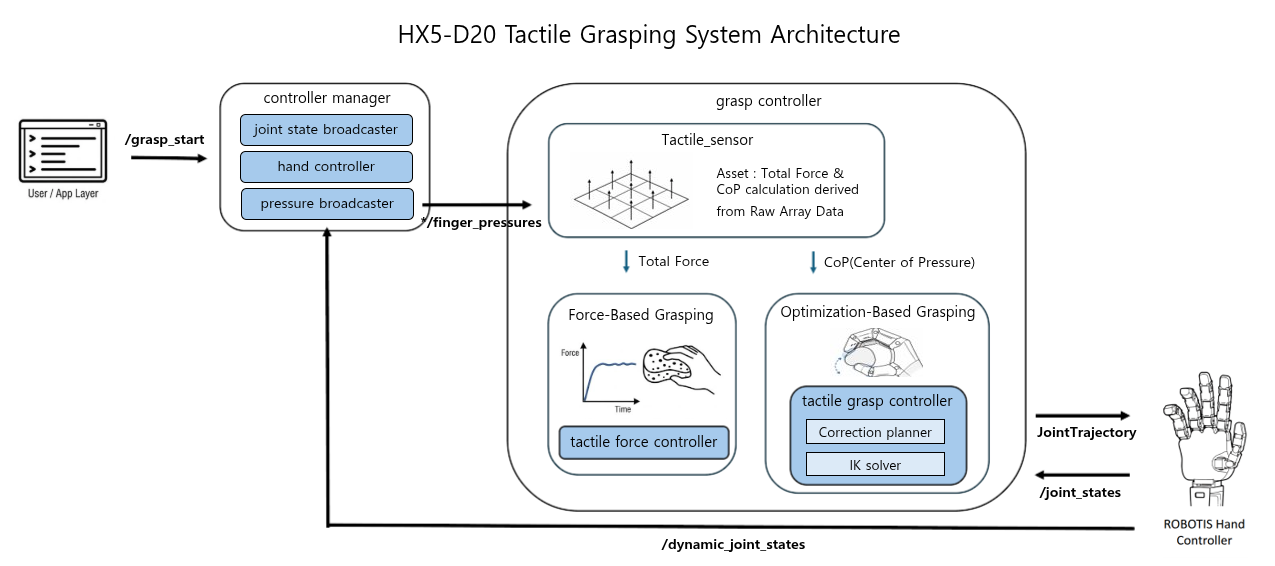
Combine tactile sensing, force-based grasping, and feedback correction for stable grasps on the HX5-D20.