HX Friends
HX Friends is a collection of robot hand designs built on the DYNAMIXEL ecosystem.
The Community Showcase shows how individuals, universities, and companies already use DYNAMIXEL actuators to build open-source robots — including many robotic hands. HX Friends continues that idea: explore diverse hand layouts on the same modular foundation, then invent your own.
Why the DYNAMIXEL Ecosystem
| Strength | What it means for hand builders |
|---|---|
| Versatile actuators | One actuator family scales from a simple finger or gripper to high-DOF anthropomorphic hands and full robot platforms |
| Open-source culture | Labs and companies publish DYNAMIXEL-based designs and tools you can study, remix, and extend |
| Proven for hands | Peer projects such as MIDAS Hand, Orca Hand, Leap Hand, House of Dextra, OpenHand, and others already choose DYNAMIXEL for dexterous manipulation |
| Modular building blocks | Familiar protocols and replaceable joints keep designs maintainable as you iterate |
| Global community | A worldwide network of makers and researchers sharing projects proudly Powered by DYNAMIXEL |
Together, these strengths give you an open, modular, and practical path to invent the hand that fits your robot and your problem.
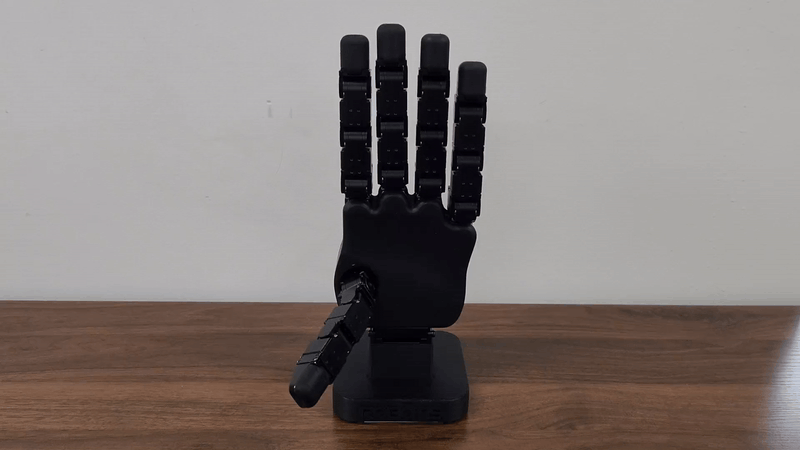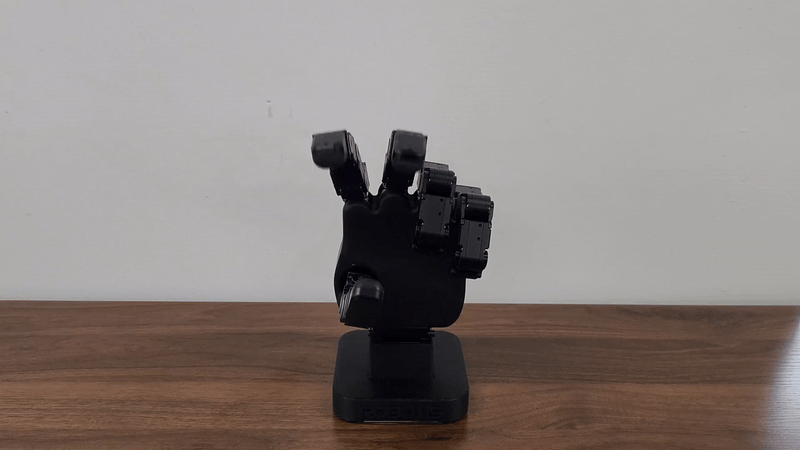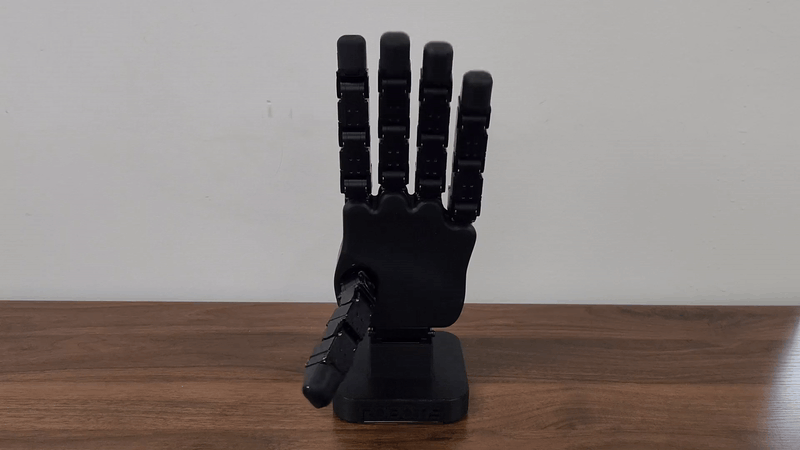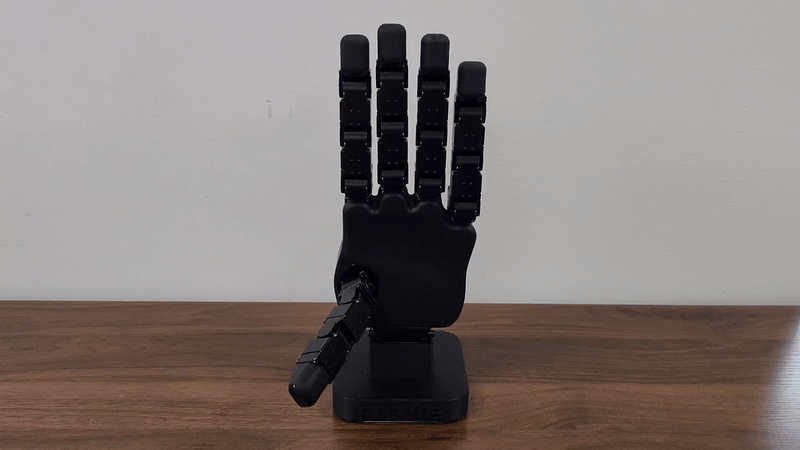
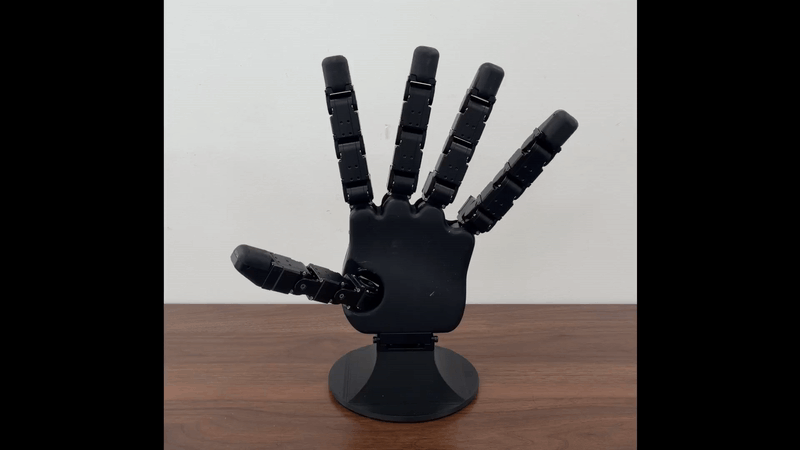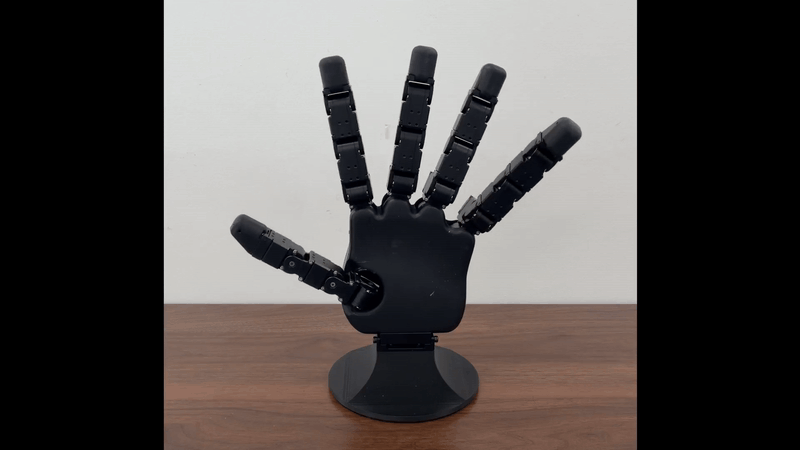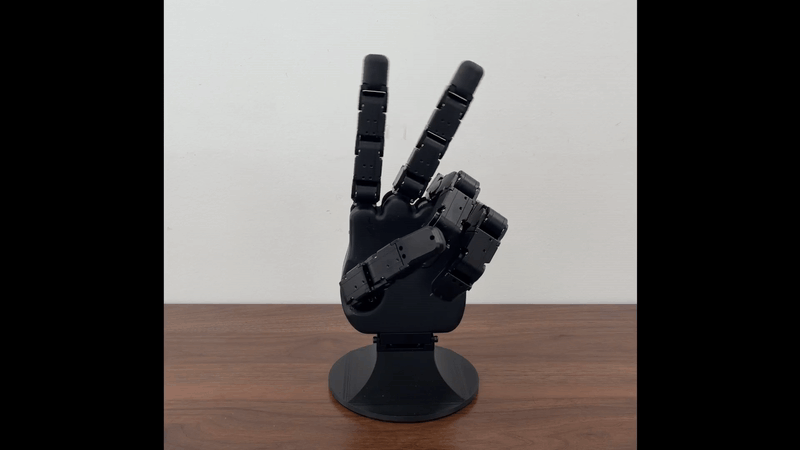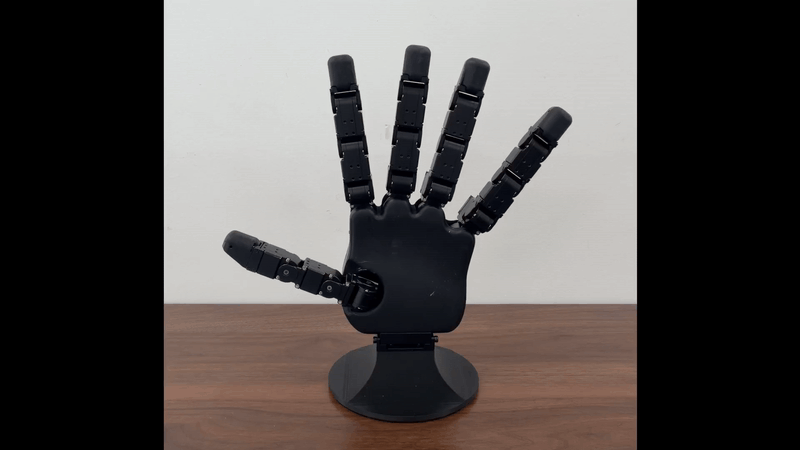
HX Friends: HX5-D20
- Type: Hand
- Features: A 20 DOF anthropomorphic reference with a thumb and four fingers — useful when you want to explore human-like coverage and fine multi-finger coordination.
- Components
- Twenty DYNAMIXEL XM335-T323-T
- Five tactile sensors at the fingertips
HX Friends: HX4-D12
- Type: Hand
- Features: A 12 DOF design with a thumb and three fingers — a middle ground between dexterity and mechanical simplicity.
- Components
- Twelve DYNAMIXEL XM335-T323-T
- Four tactile sensors at the fingertips
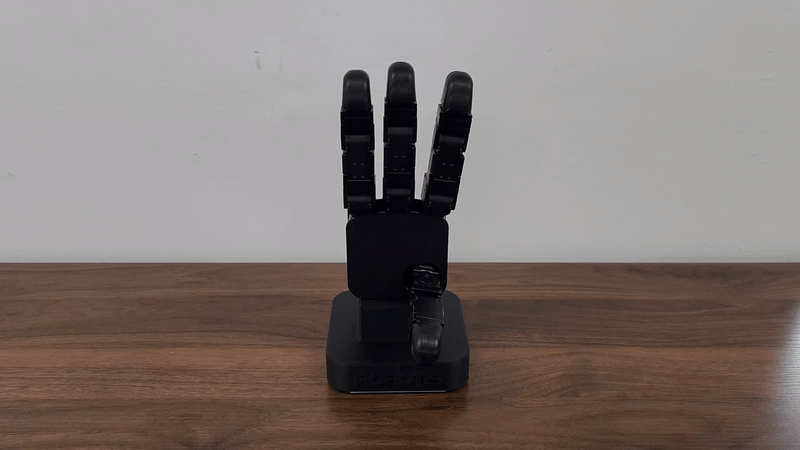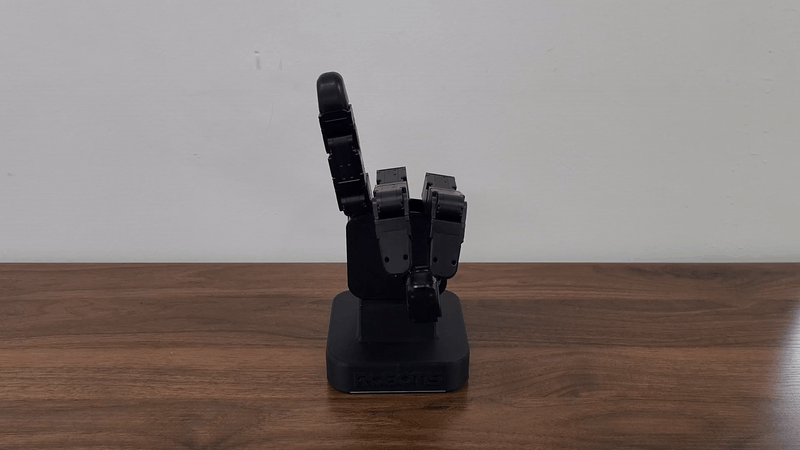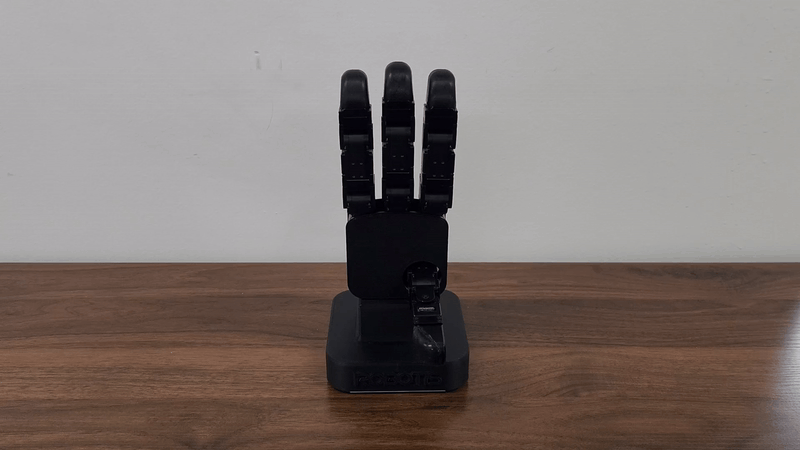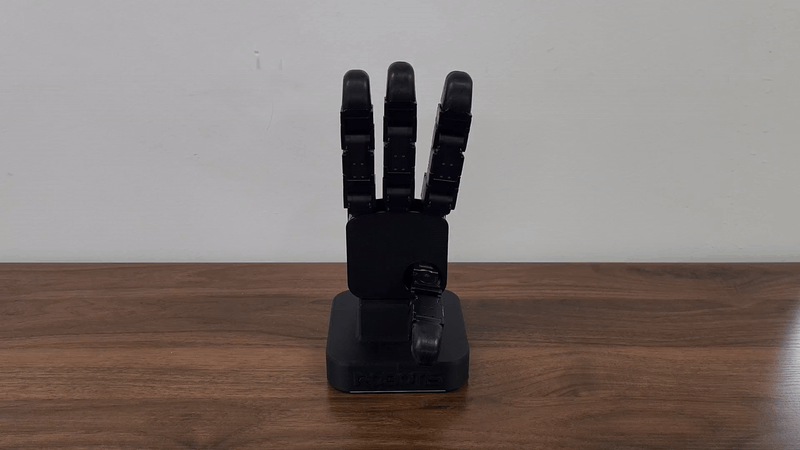
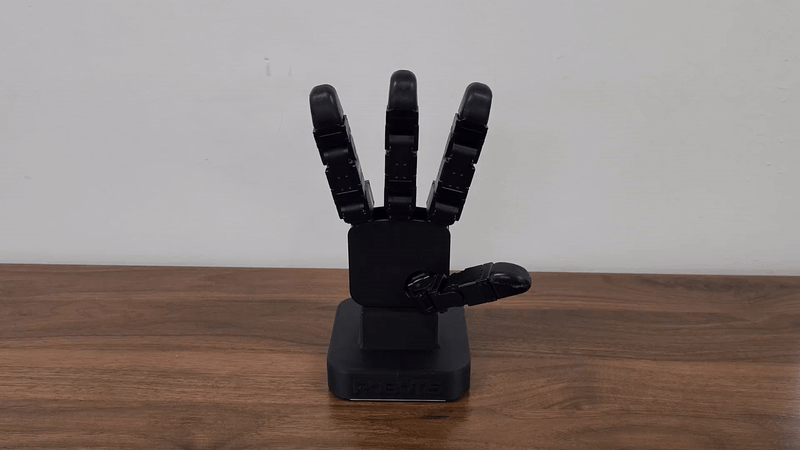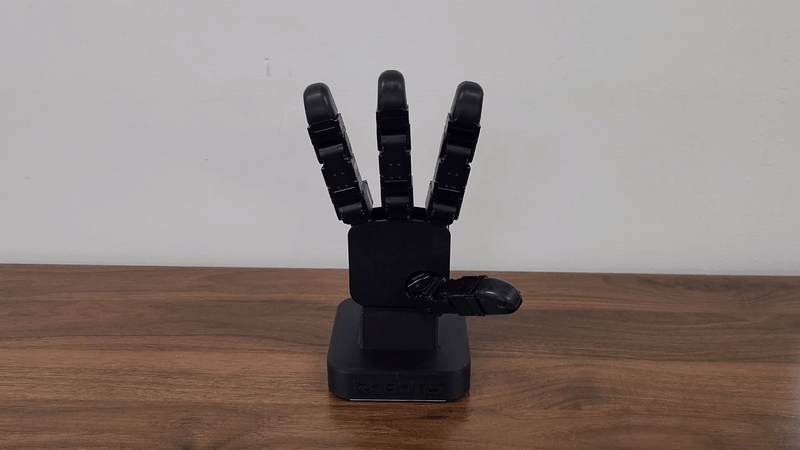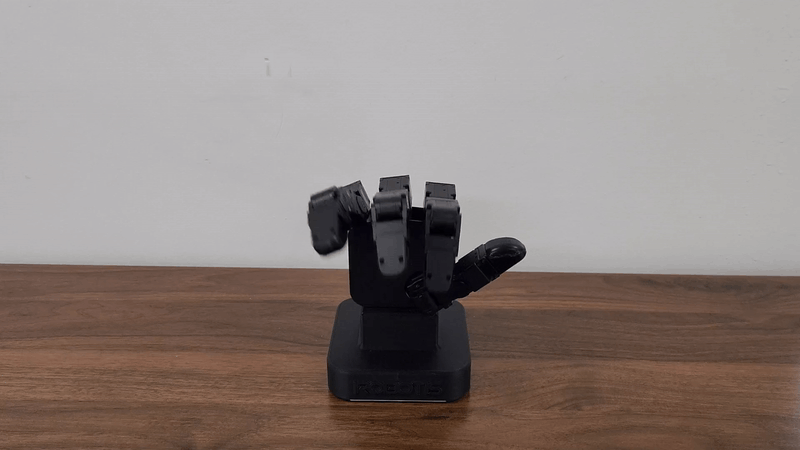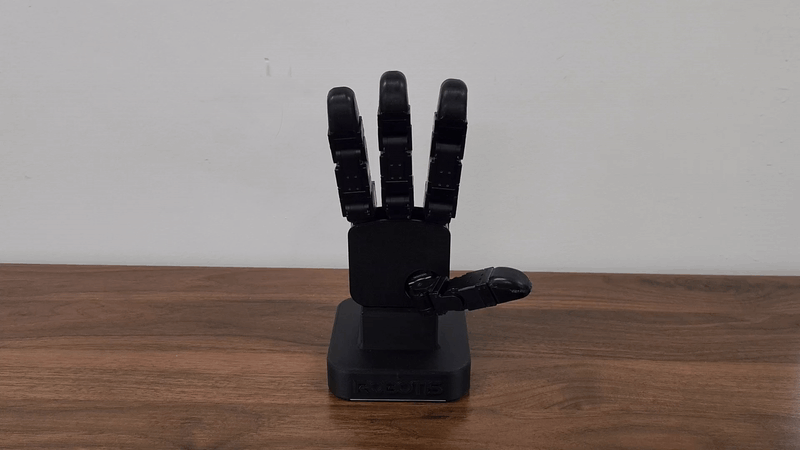
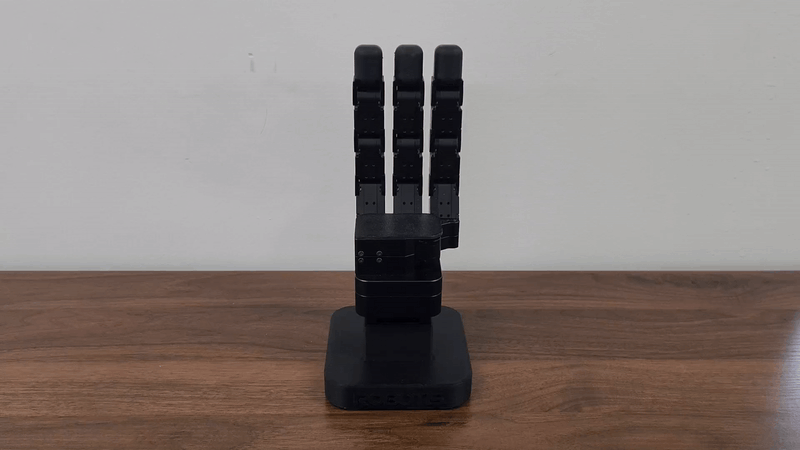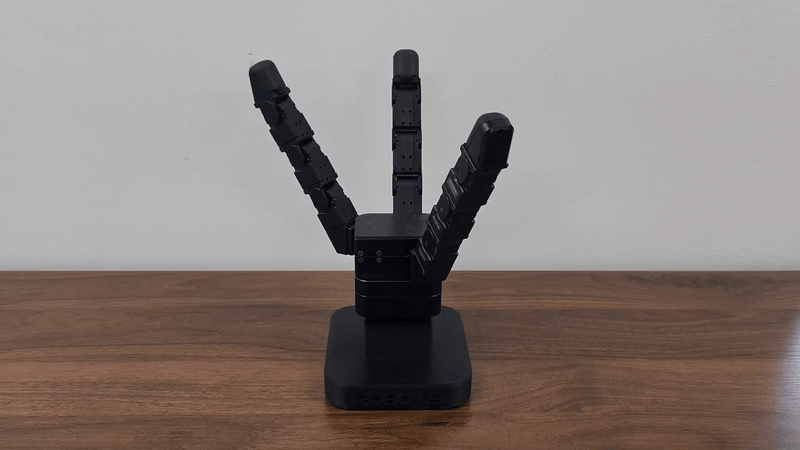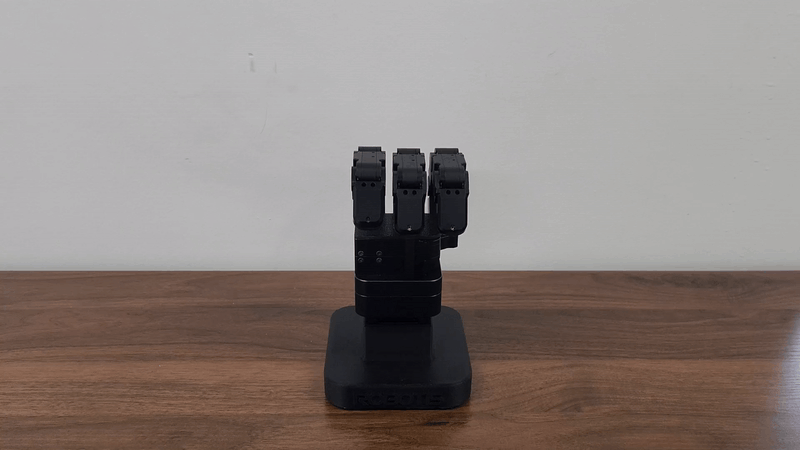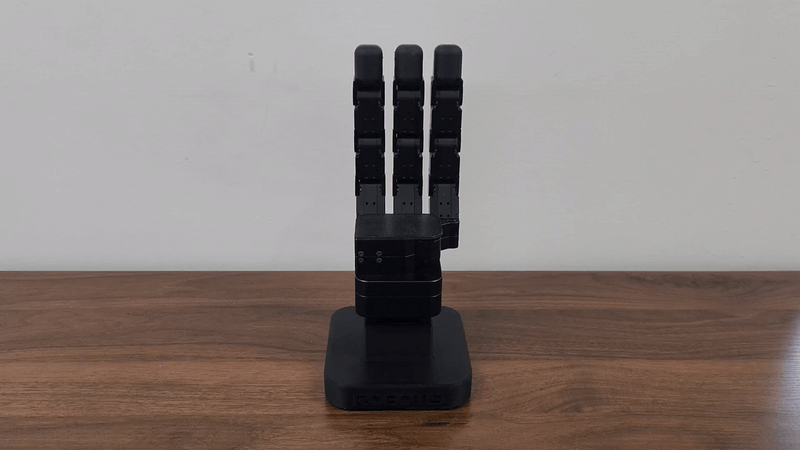
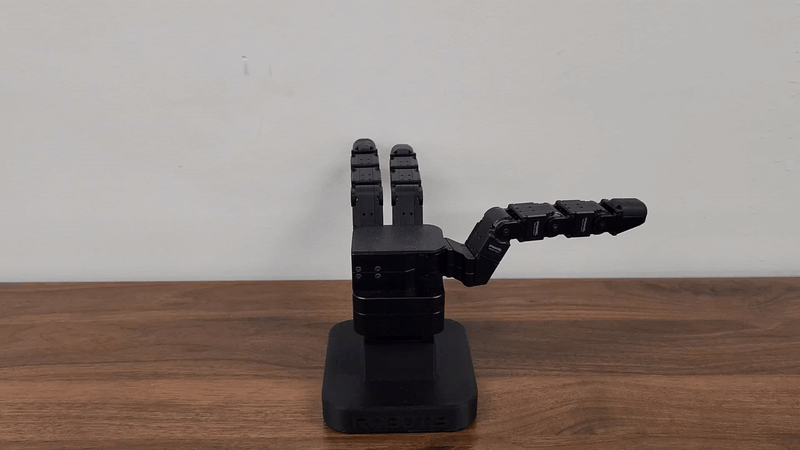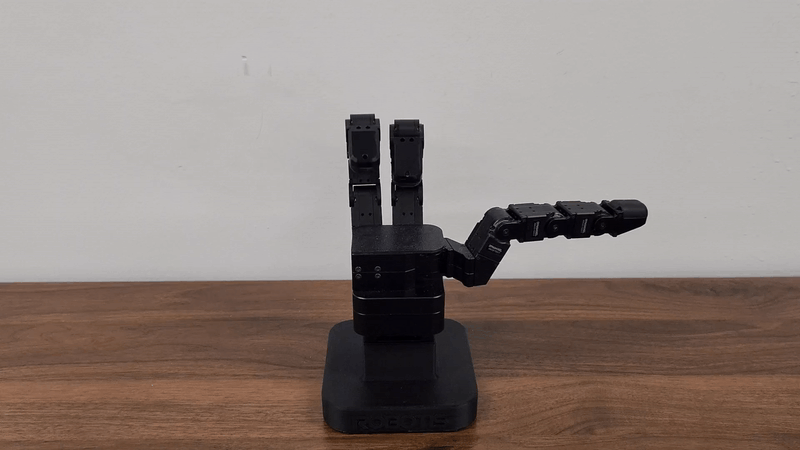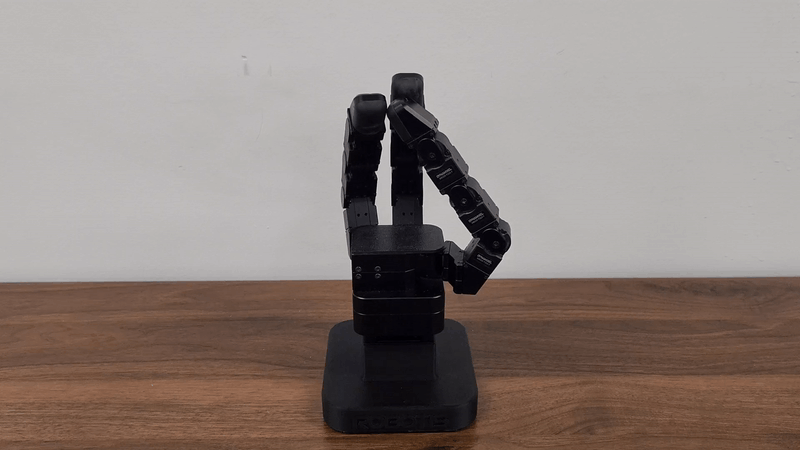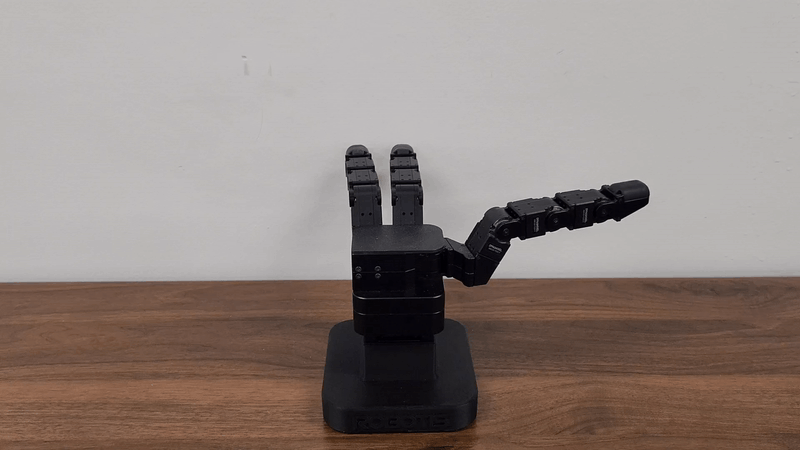
HX Friends: HX3-D11
- Type: Hand
- Features: An 11 DOF three-finger reference — a more compact multi-finger option with fewer parts to manage.
- Components
- Eleven DYNAMIXEL XM335-T323-T
- Three tactile sensors at the fingertips
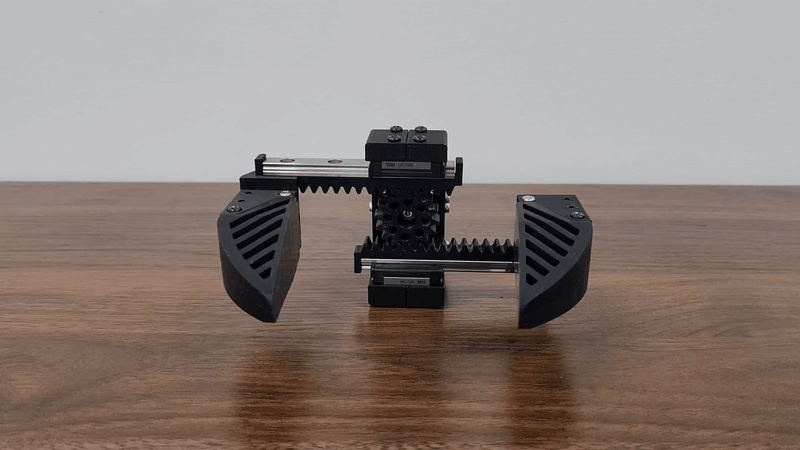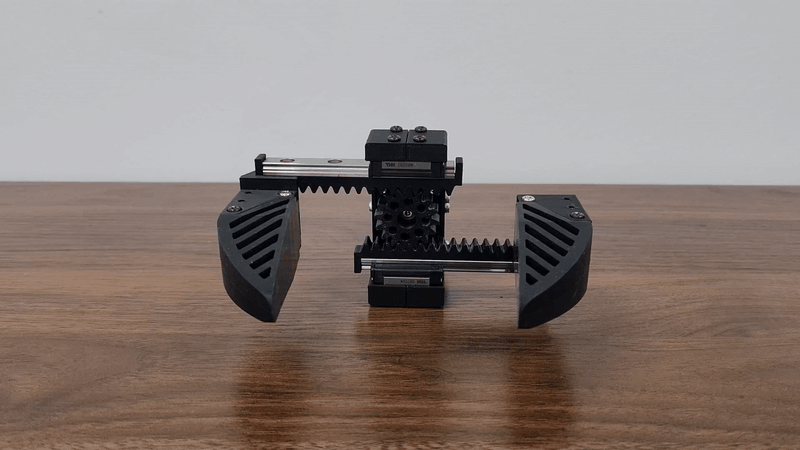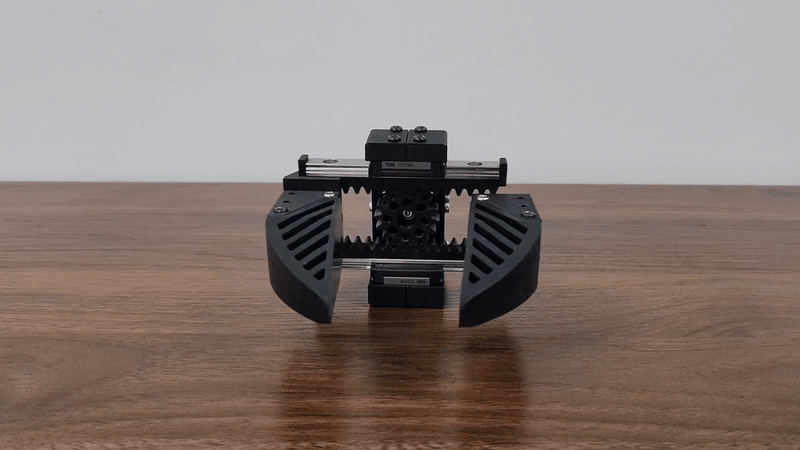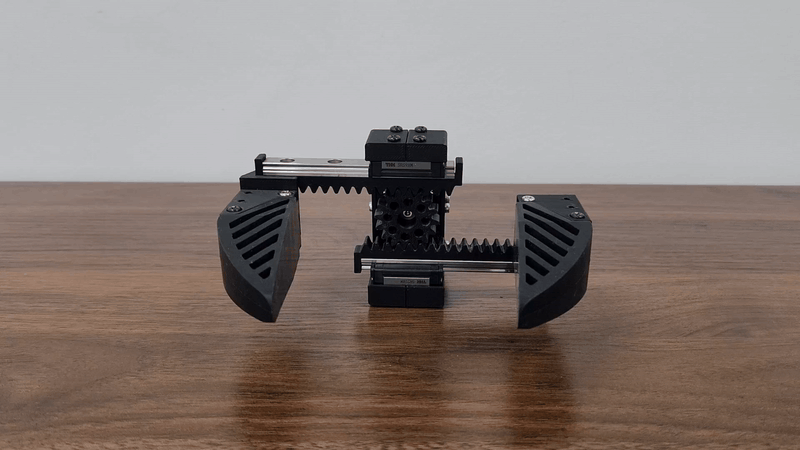
HX Friends: HX2-D01
- Type: Gripper
- Features: A gripper built with XM430-W210-R — an example of using a different DYNAMIXEL series for a simpler, robust grasp form factor.
- Components
Interactive 3D model coming soon.
HX Friends: HX1-D03
- Type: Finger
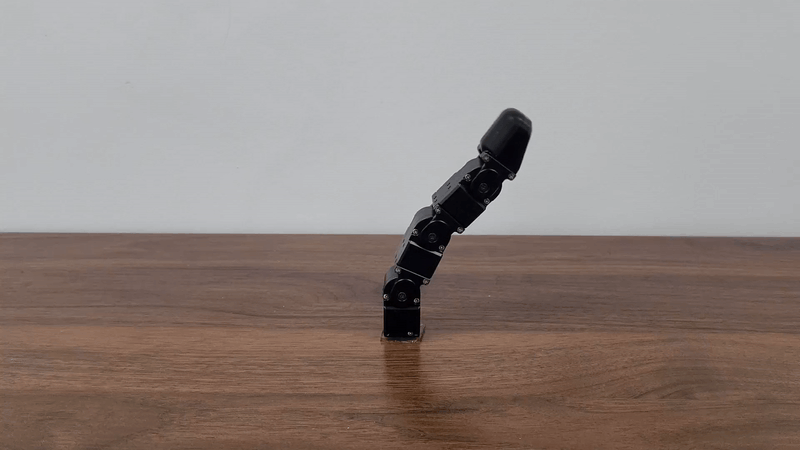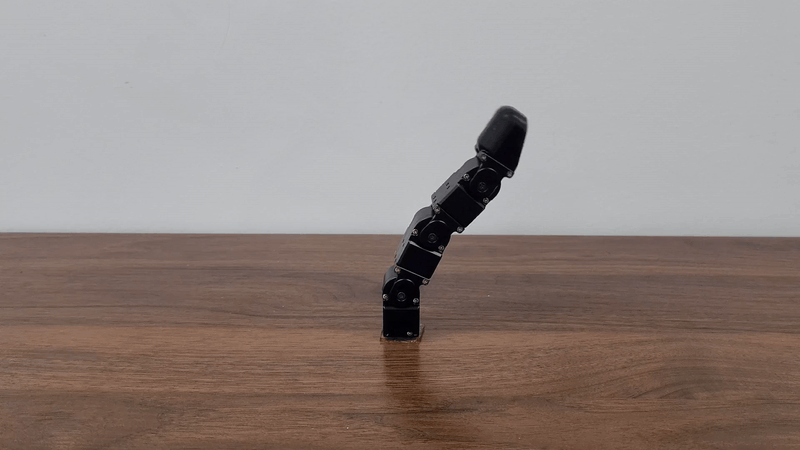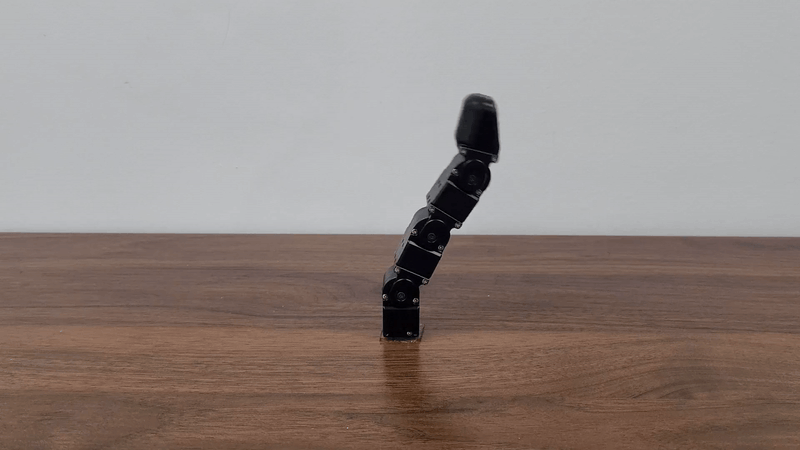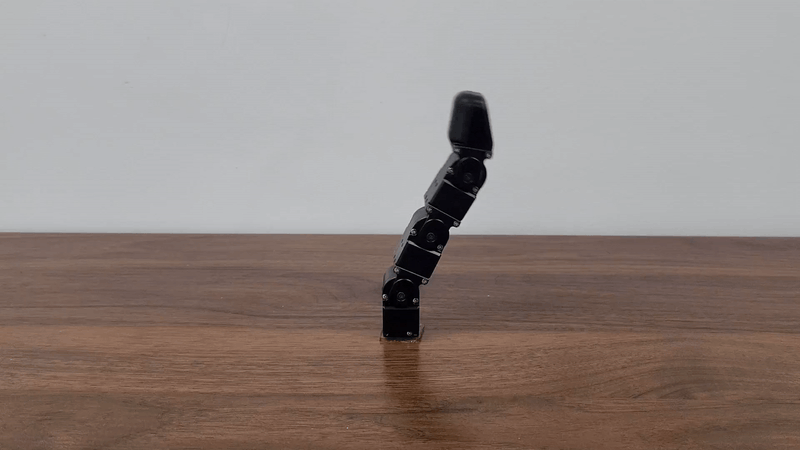
- Features: A 3 DOF all-pitch finger — a minimal block for studying joint stacking and finger motion before you scale to a full hand.
- Components
- Three DYNAMIXEL XM335-T323-T
- One tactile sensor at the tip
Get Inspired
Use these designs as references, not rules. Pose the joints, compare layouts, and notice how actuator choice and DOF change the feel of a hand.
Then invent something we have not shown: a new finger arrangement, a lighter gripper, a task-specific mechanism, or a hybrid that only your application needs. The best next HX Friend is the one you create.
Explore More from the Community
HX Friends is one slice of a larger DYNAMIXEL world. See what universities, companies, and makers are already building — and bring your own project into that circle.
→ Community Showcase / Ecosystem
You can also dig into ROBOTIS Hand open-source resources: Open Source · Discord