Hardware Specification
The AI Worker hardware platform combines advanced robotics with AI-powered capabilities to create a versatile semi-humanoid robot. Built around ROBOTIS DYNAMIXEL actuators, it features a mobile base with swerve drive, dual 7-DOF arms with dexterous hand/grippers, and a sensor suite that includes RGBD cameras and LiDARs. The system is powered by an NVIDIA Jetson AGX Orin computer to handle complex computations and AI tasks. The robot is designed for industrial applications, capable of performing tasks such as assembly, inspection, and logistics in dynamic environments. This comprehensive hardware design enables the AI Worker to perform complex manipulation tasks through imitation learning and reinforcement learning in various industrial environments.

Product Models


Included Common Items
| Item | Qty |
|---|---|
| Follower | 1 |
| Leader | 1 |
| SMPS for robot | 2 |
| SMPS for LG2 | 1 |
| E stop remote controller | 1 |
| USB cable | 1 |
Follower Specification
In the W1 / W2 tables below, bold text highlights specifications that differ from BG2 / SG2, respectively.
BG2 is sold in Korea only. FFW-SH3P is currently in preparation for release.
- W1 / W2
- SG2 / BG2
| Properties | Specification (W2) | Specification (W1) |
|---|---|---|
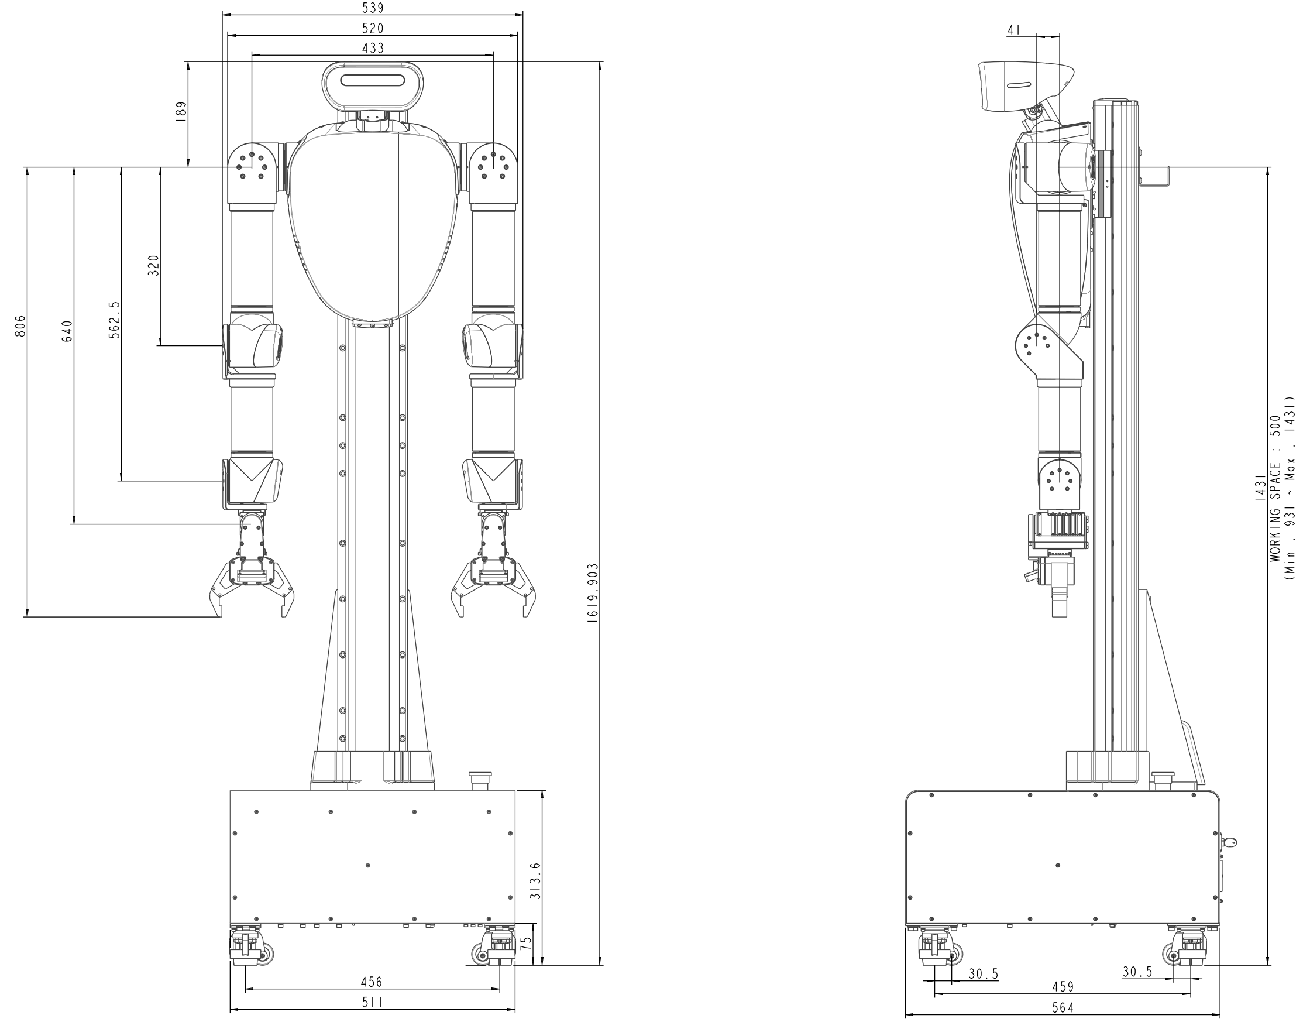
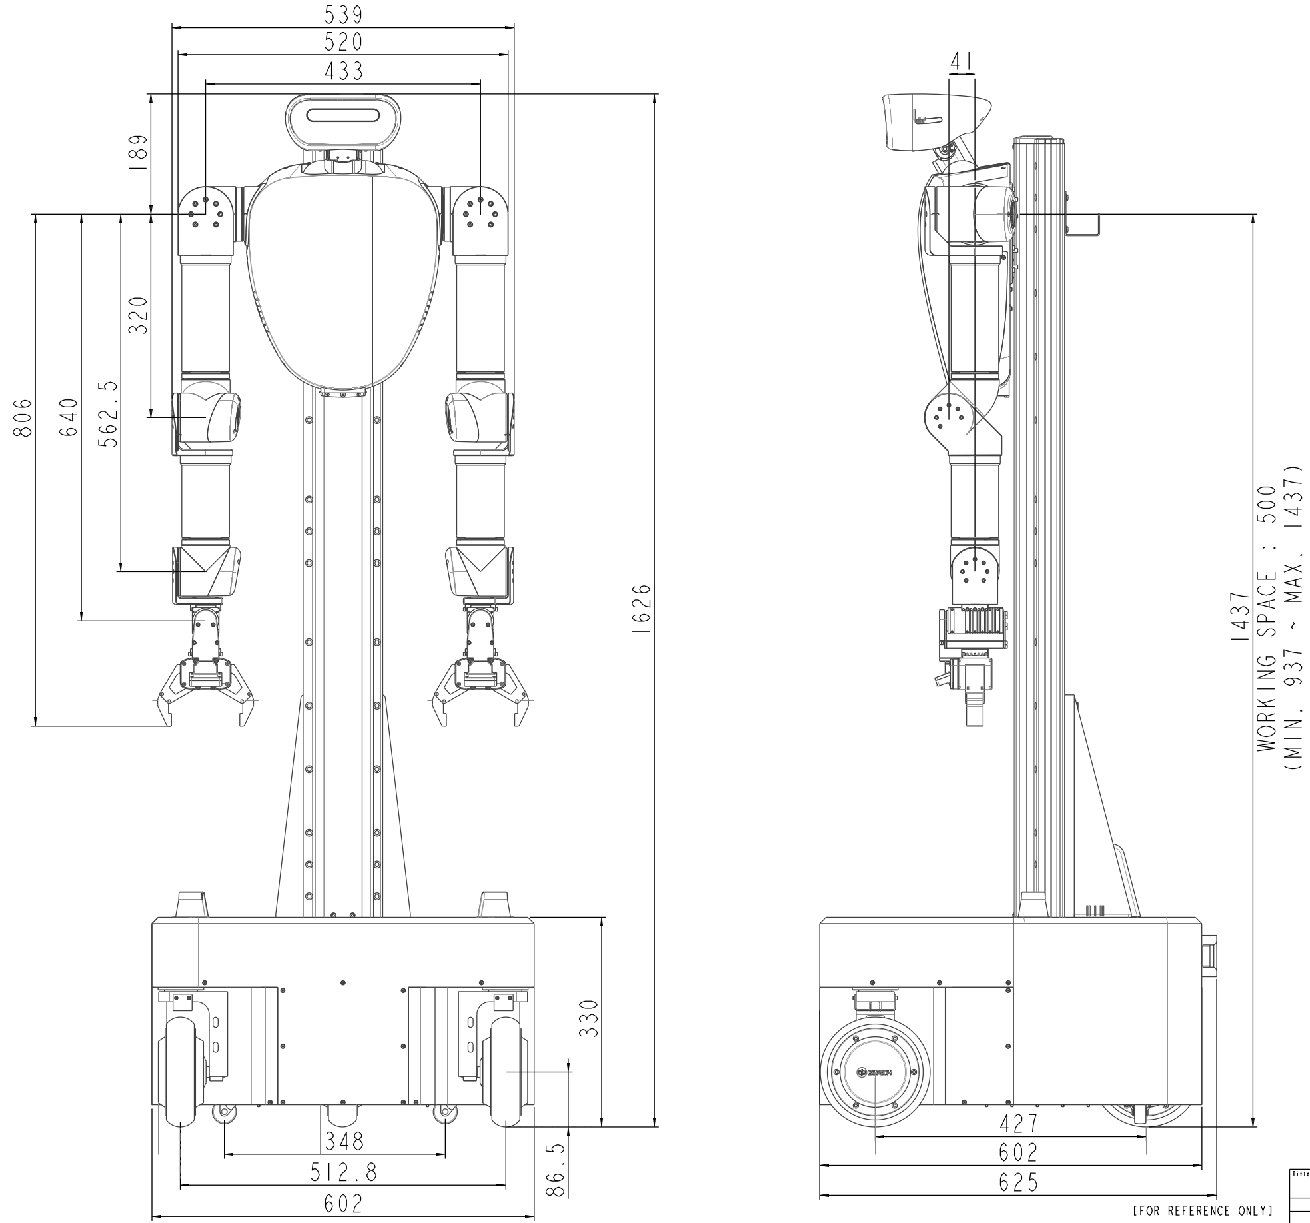
| Dimensions (WxDxH) | 625x602x1,626 (mm) 24.6x23.7x64 (inch) | 604x564x1,607 (mm) 23.8x22.2x63.2 (inch) |
| Weight | 90 kg (198 lb) | 85 kg (187 lb) |
| Actuator | Arm Joint 1 ~ 6: DYNAMIXEL-Y Arm Joint 7: DYNAMIXEL-P Head: DYNAMIXEL-X Lift: DYNAMIXEL-Y (see DYNAMIXEL Details) | Arm Joint 1 ~ 6: DYNAMIXEL-Y Arm Joint 7: DYNAMIXEL-P Head: DYNAMIXEL-X Lift: DYNAMIXEL-Y (see DYNAMIXEL Details) |
| Degrees of Freedom | - Total: 25 DOF - Arm: 7 DOF x 2 - Gripper: 1 DOF x 2 - Head: 2 DOF x 1 - Lift: 1 DOF x 1 - Mobile: 6 DOF | - Total: 19 DOF - Arm: 7 DOF x 2 - Gripper: 1 DOF x 2 - Head: 2 DOF x 1 - Lift: 1 DOF x 1 |
| Arm Reach | 640 mm (to wrist) + hand | 640 mm (to wrist) + hand |
| Arm Payload (Nominal) | 3.0 kg (single arm) 6.0 kg (dual arm) | 3.0 kg (single arm) 6.0 kg (dual arm) |
| Arm Payload¹ (Peak) | 5.0 kg (single arm) 10.0 kg (dual arm) | 5.0 kg (single arm) 10.0 kg (dual arm) |
| Joint Resolution | -π(rad) ~ π(rad) -262,144 ~ 262,144 (pulse/rev) | -π(rad) ~ π(rad) -262,144 ~ 262,144 (pulse/rev) |
| Joint Range | (see Joint Configuration) | (see Joint Configuration) |
| Gripper/Hand | Standard: RH-P12-RN (see Gripper Specification) Optional: HX5-D20 (sold separately) | Standard: RH-P12-RN (see Gripper Specification) Optional: HX5-D20 (sold separately) |
| Mobile Type | Swerve Drive | None |
| Mobile Operation Velocity | 1.5 m/s | None |
| Power | Battery: 25V, 80Ah (2,040Wh) | AC powered via SMPS: 24VDC, 80A, 1,920W |
| Ambient Operating Temperature | 0 ~ 40℃ | 0 ~ 40℃ |
| Exterior Materials | Aluminum, Plastic | Aluminum, Plastic |
| Sensor | RGBD Camera x 3, LiDAR x 2, IMU (see Camera Specification) | RGBD Camera x 3 (see Camera Specification) |
| Host Interface | Ethernet (up to 100 Mbps) | Ethernet (Direct connection to a host PC) |
| Internal Router | Archer AX23V | None |
| Internal Communications | RS-485 | RS-485 |
| Communication Baudrate | 4 Mbps | 4 Mbps |
| Computer | NVIDIA Jetson AGX Orin 32GB | NVIDIA Jetson AGX Orin 32GB |
| Software | ROS 2 Support, Python, C++, Web UI | ROS 2 Support, Python, C++, Web UI |
| Properties | Specification (SG2) | Specification (BG2) |
|---|---|---|
| Dimensions (WxDxH) | 604x602x1,623 (mm) 23.8x23.7x63.8 (inch) | 604x564x1,607 (mm) 23.8x22.2x63.2 (inch) |
| Weight | 90 kg (198 lb) | 85 kg (187 lb) |
| Actuator | Arm Joint 1 ~ 6: DYNAMIXEL-Y Arm Joint 7: DYNAMIXEL-P Head: DYNAMIXEL-X Lift: DYNAMIXEL-Y (see DYNAMIXEL Details) | Arm Joint 1 ~ 6: DYNAMIXEL-Y Arm Joint 7: DYNAMIXEL-P Head: DYNAMIXEL-X Lift: DYNAMIXEL-Y (see DYNAMIXEL Details) |
| Degrees of Freedom | - Total: 25 DOF - Arm: 7 DOF x 2 - Gripper: 1 DOF x 2 - Head: 2 DOF x 1 - Lift: 1 DOF x 1 - Mobile: 6 DOF | - Total: 19 DOF - Arm: 7 DOF x 2 - Gripper: 1 DOF x 2 - Head: 2 DOF x 1 - Lift: 1 DOF x 1 |
| Arm Reach | 641 mm (to wrist) + hand | 641 mm (to wrist) + hand |
| Arm Payload (Nominal) | 3.0 kg (single arm) 6.0 kg (dual arm) | 3.0 kg (single arm) 6.0 kg (dual arm) |
| Arm Payload¹ (Peak) | 5.0 kg (single arm) 10.0 kg (dual arm) | 5.0 kg (single arm) 10.0 kg (dual arm) |
| Joint Resolution | -π(rad) ~ π(rad) -262,144 ~ 262,144 (pulse/rev) | -π(rad) ~ π(rad) -262,144 ~ 262,144 (pulse/rev) |
| Joint Range | (see Joint Configuration) | (see Joint Configuration) |
| Gripper/Hand | Standard: RH-P12-RN (see Gripper Specification) Optional: HX5-D20 (sold separately) | Standard: RH-P12-RN (see Gripper Specification) Optional: HX5-D20 (sold separately) |
| Mobile Type | Swerve Drive | None |
| Mobile Operation Velocity | 1.5 m/s | None |
| Power | Battery: 25V, 80Ah (2,040Wh) | AC powered via SMPS: 24VDC, 80A, 1,920W |
| Ambient Operating Temperature | 0 ~ 40℃ | 0 ~ 40℃ |
| Exterior Materials | Aluminum, Plastic | Aluminum, Plastic |
| Sensor | RGBD Camera x 3, LiDAR x 2, IMU (see Camera Specification) | RGBD Camera x 3 (see Camera Specification) |
| Host Interface | Ethernet (up to 100 Mbps) | Ethernet (Direct connection to a host PC) |
| Internal Router | TP-Link AC1200 | None |
| Internal Communications | RS-485 | RS-485 |
| Communication Baudrate | 4 Mbps | 4 Mbps |
| Computer | NVIDIA Jetson AGX Orin 32GB | NVIDIA Jetson AGX Orin 32GB |
| Software | ROS 2 Support, Python, C++, Web UI | ROS 2 Support, Python, C++, Web UI |
¹ Peak payload capacity may vary depending on the robot's posture and motion profile.
Leader Specification
A1 Model
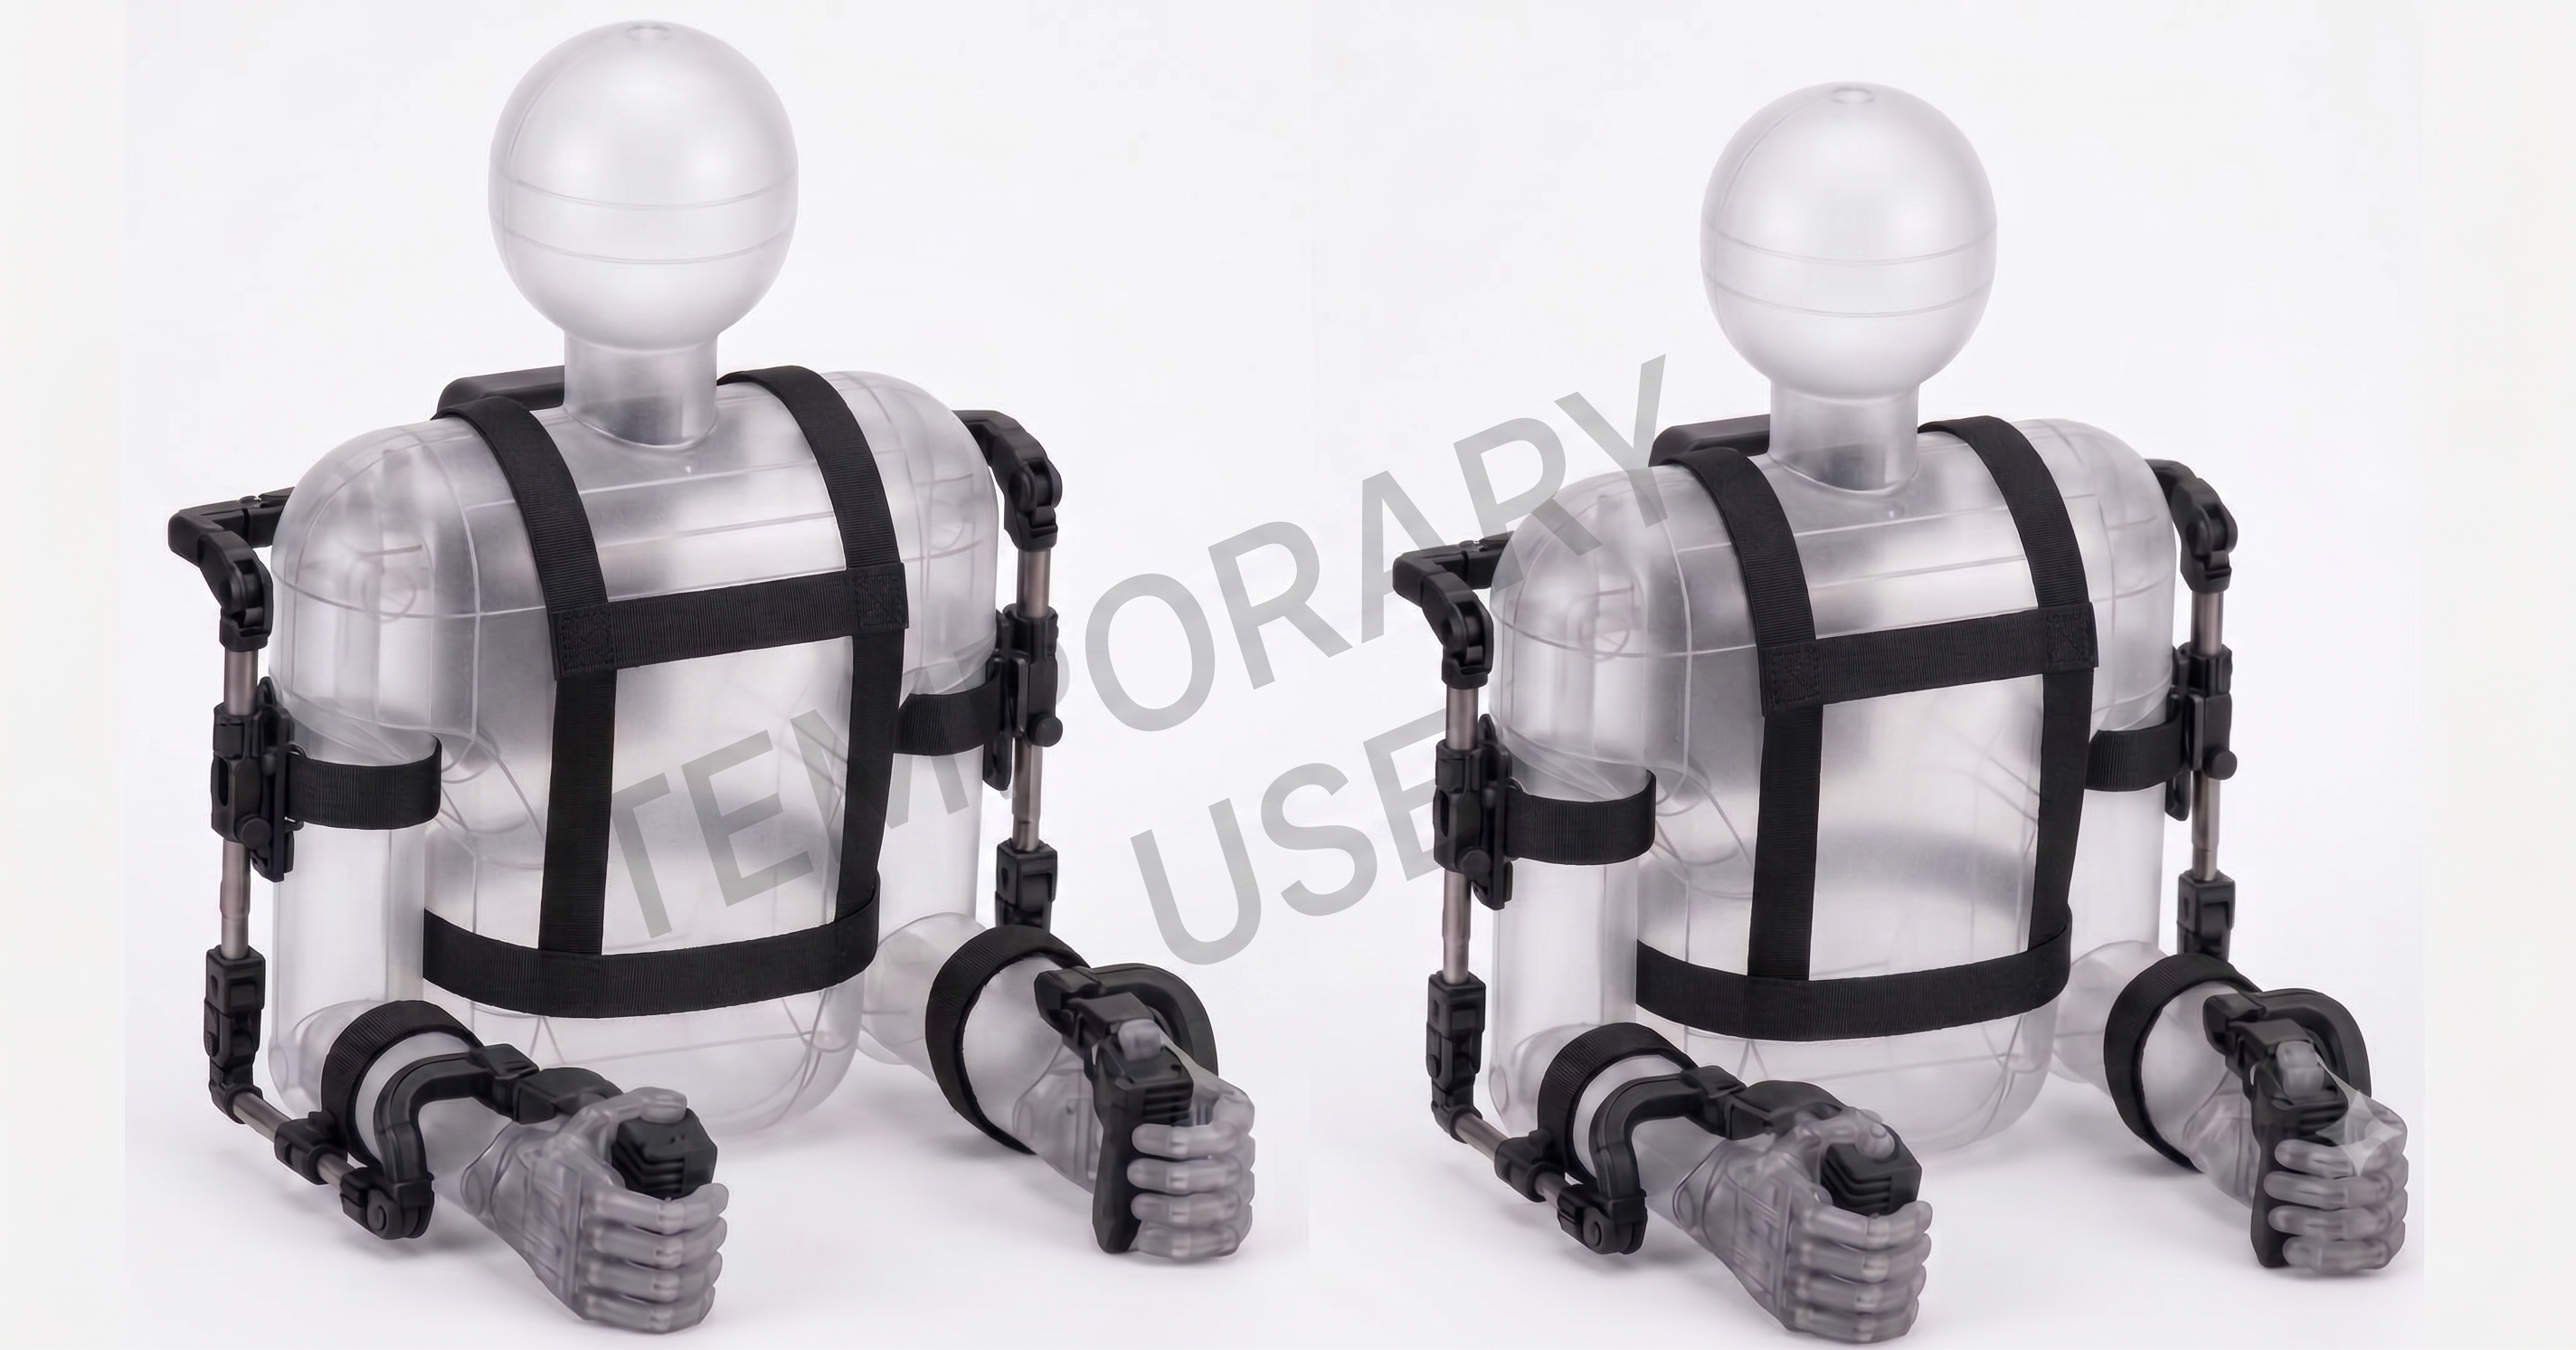
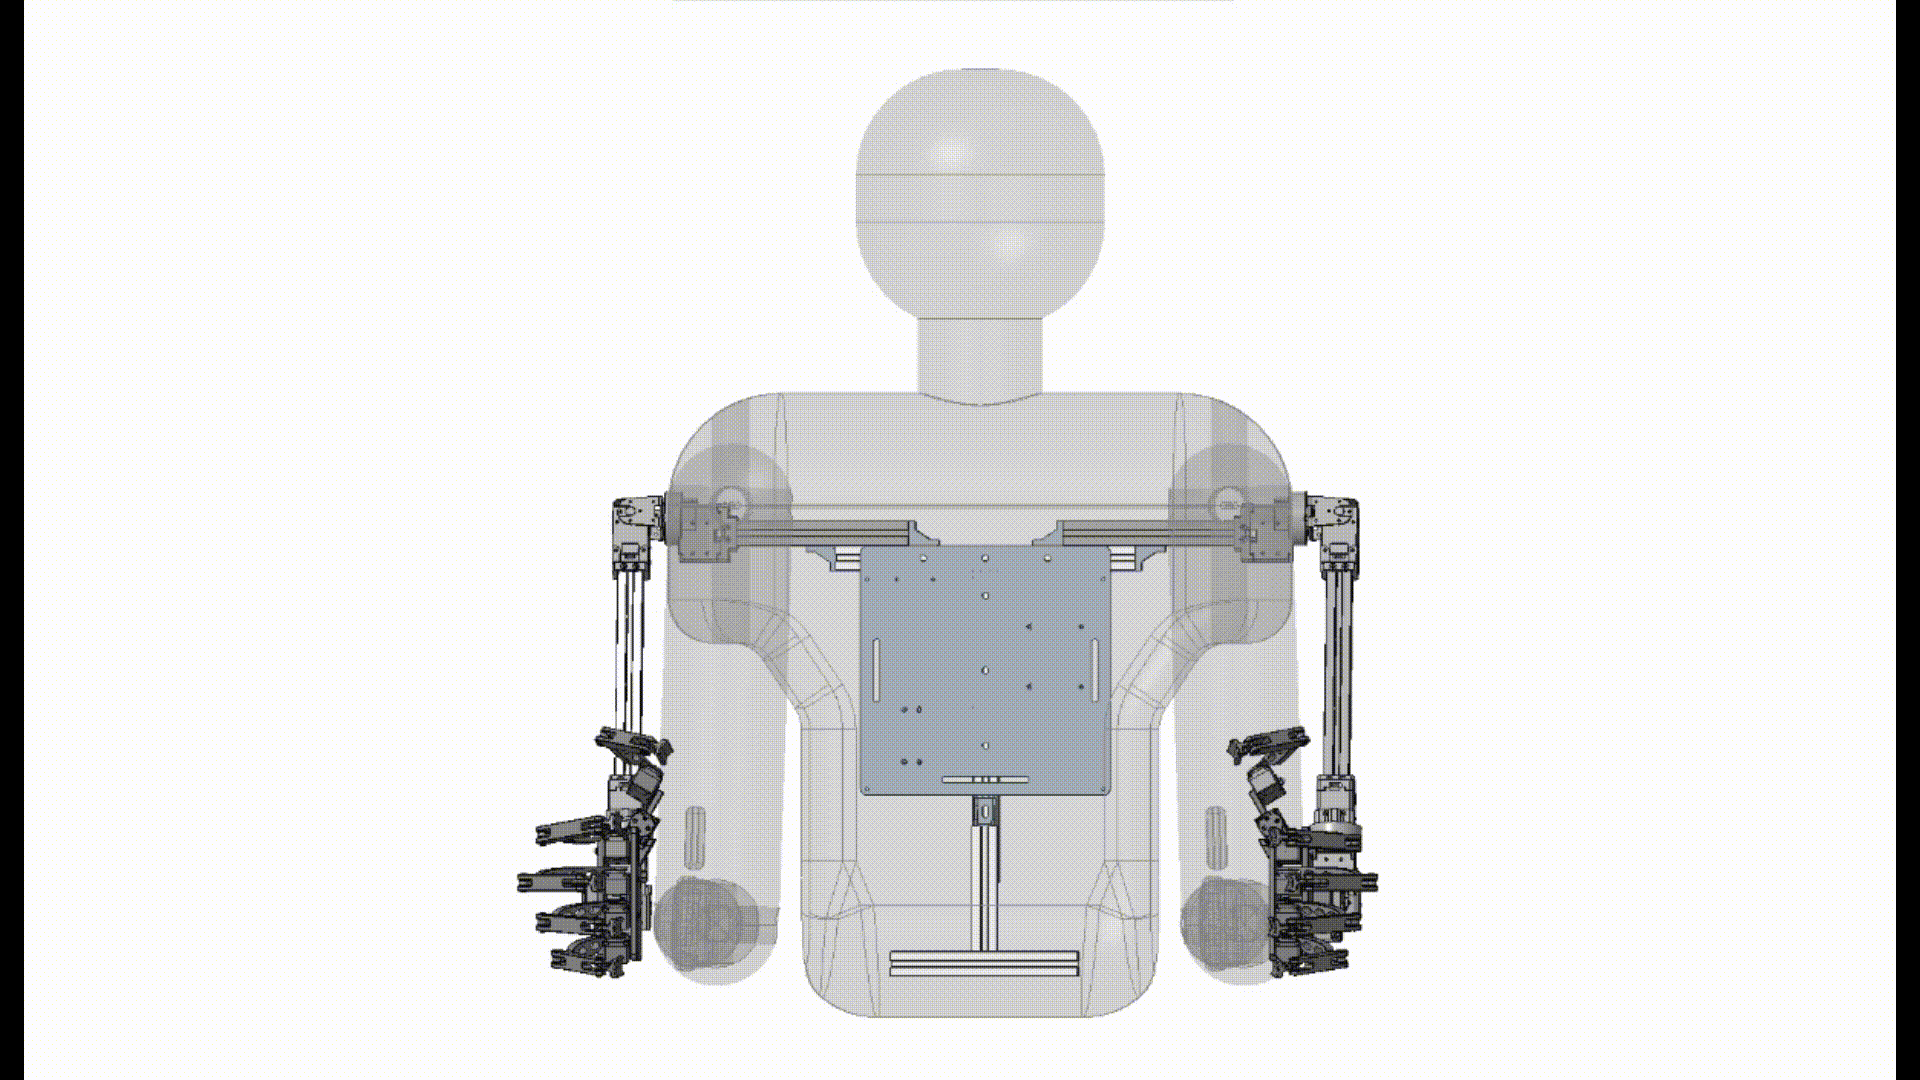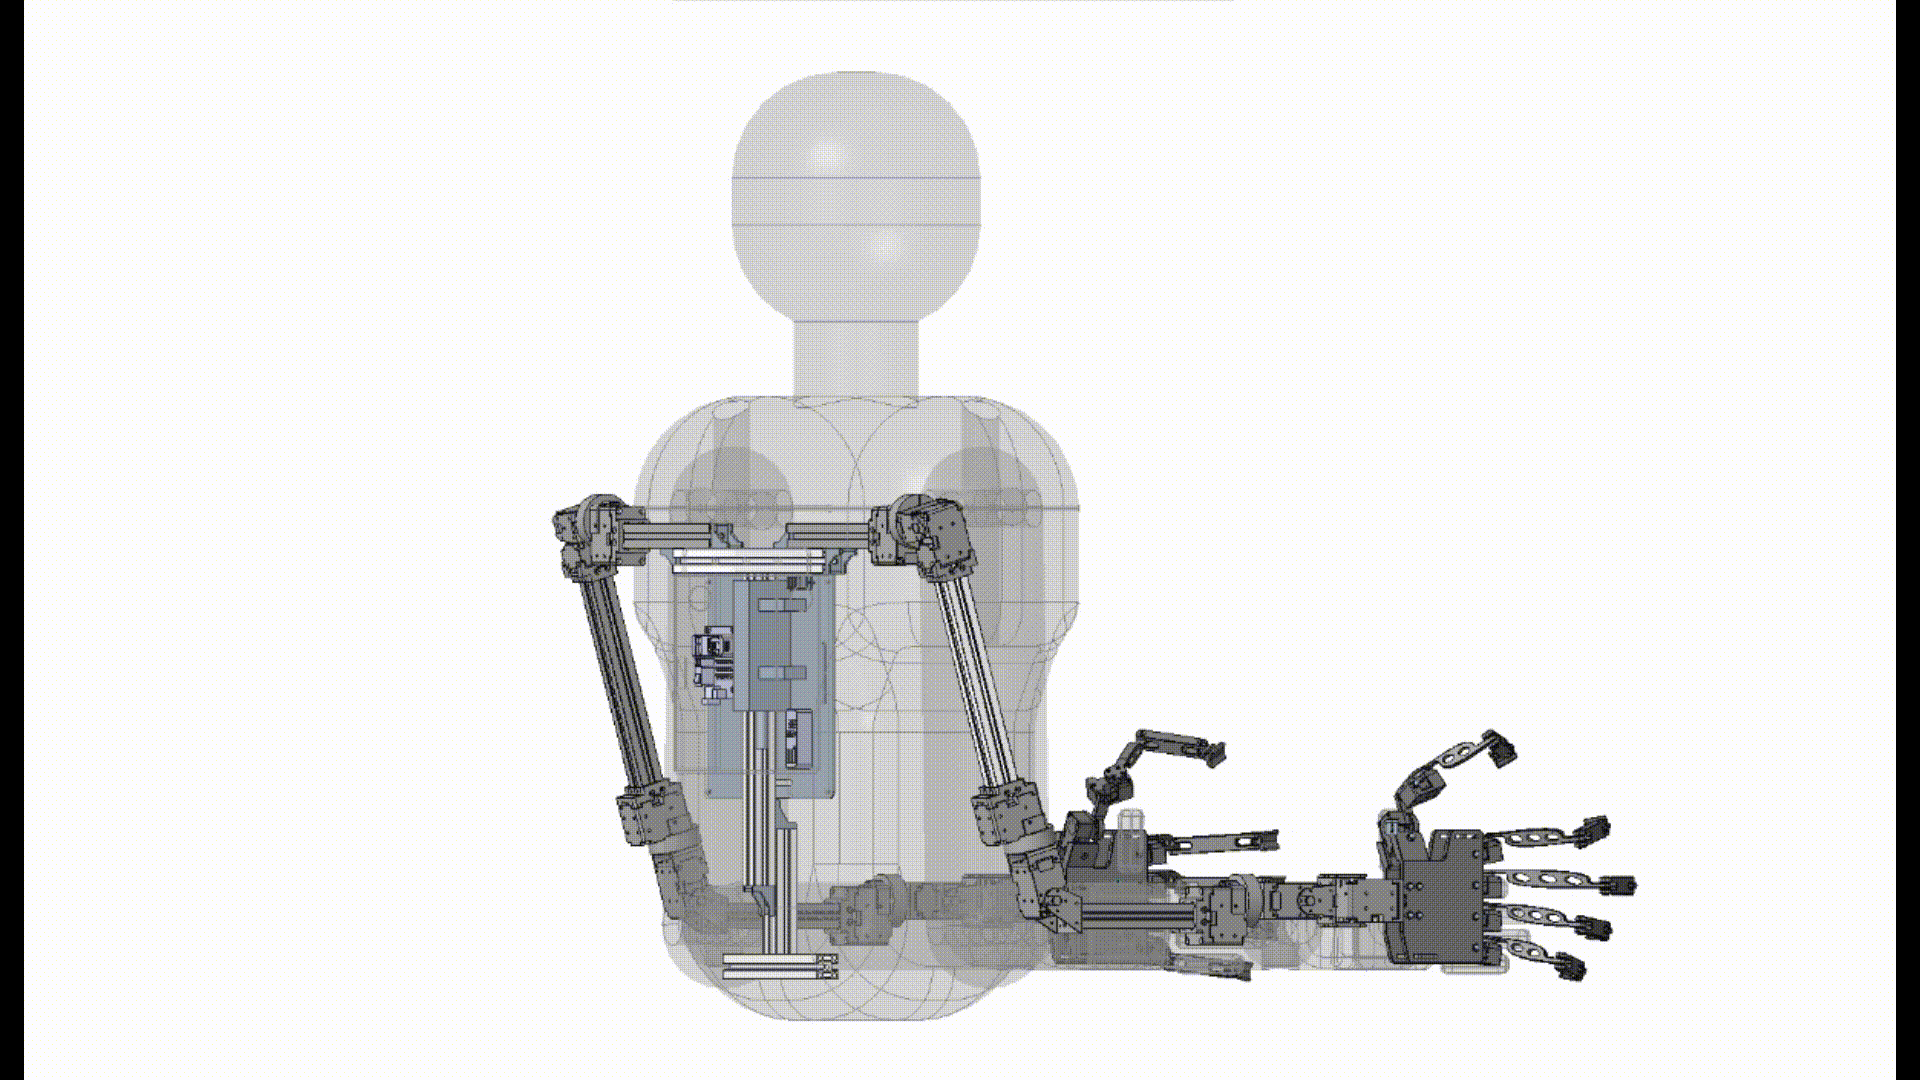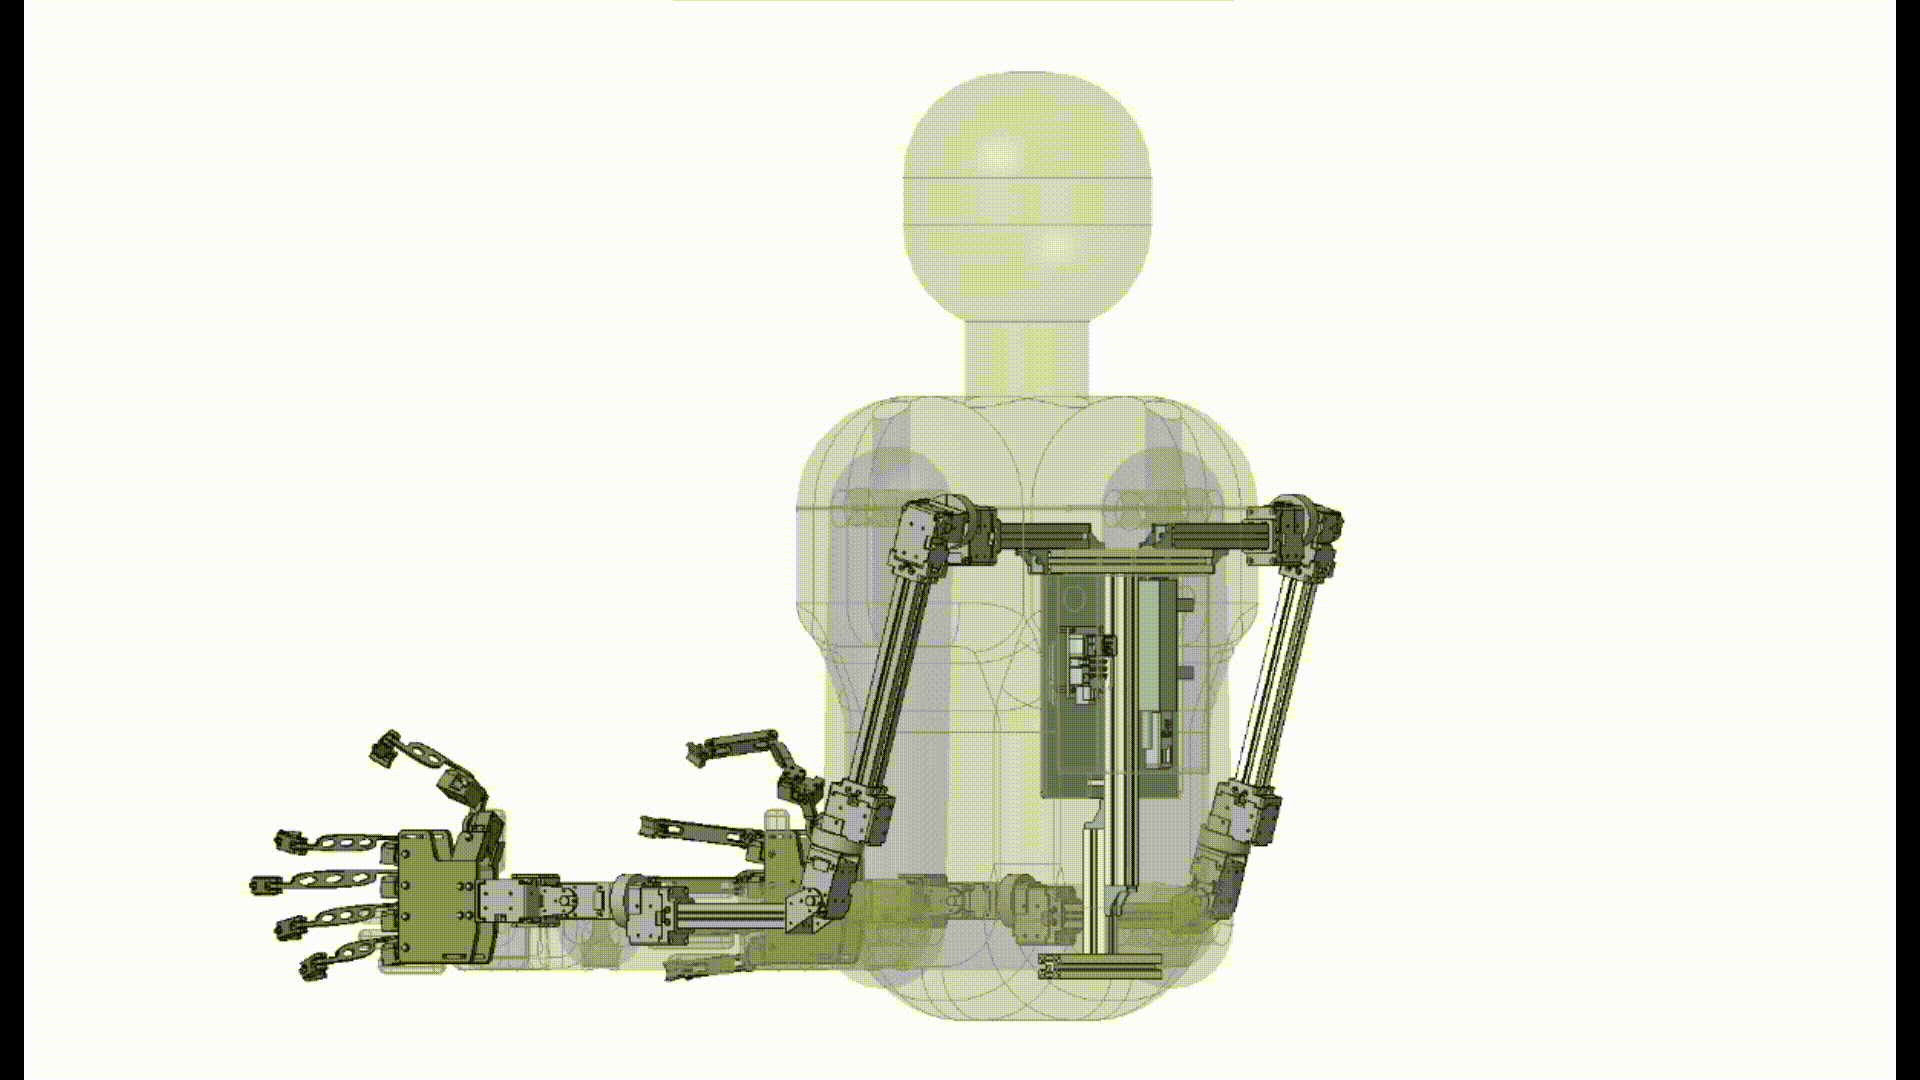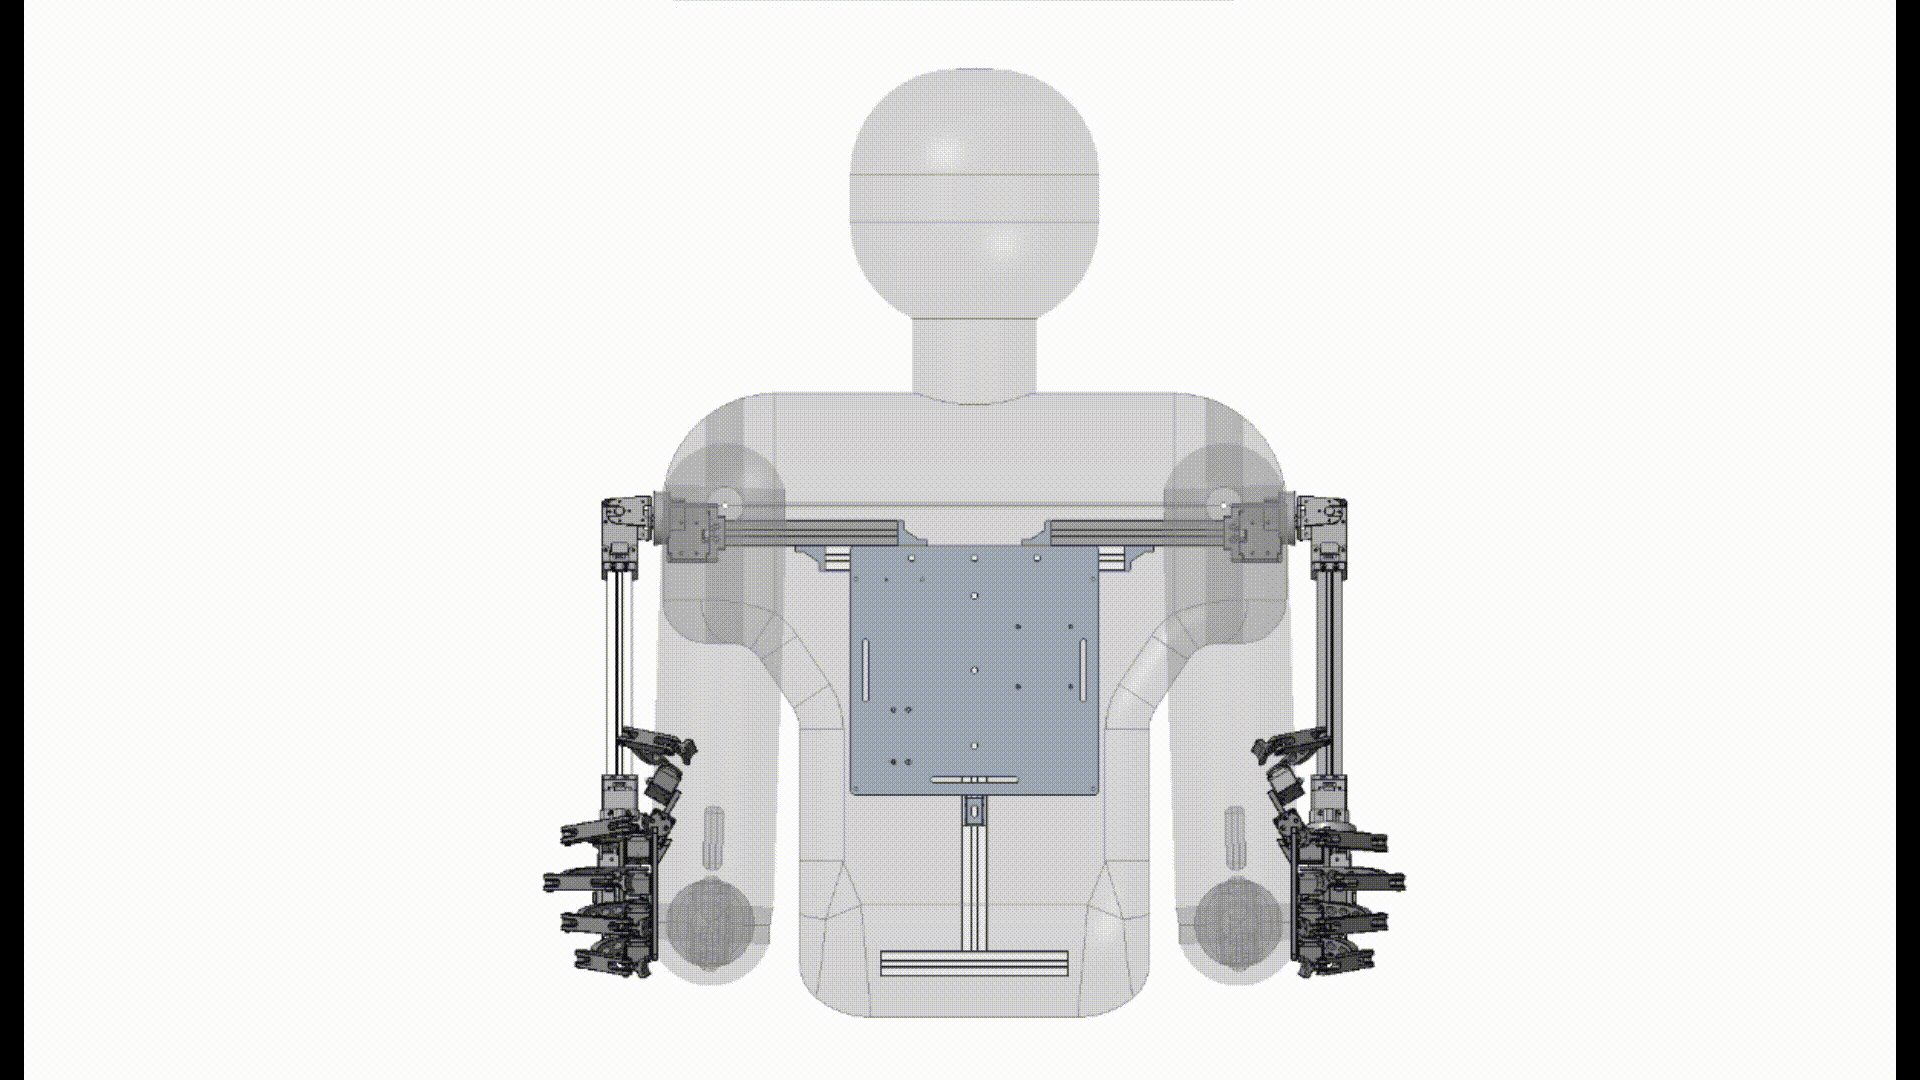
LG2 Model
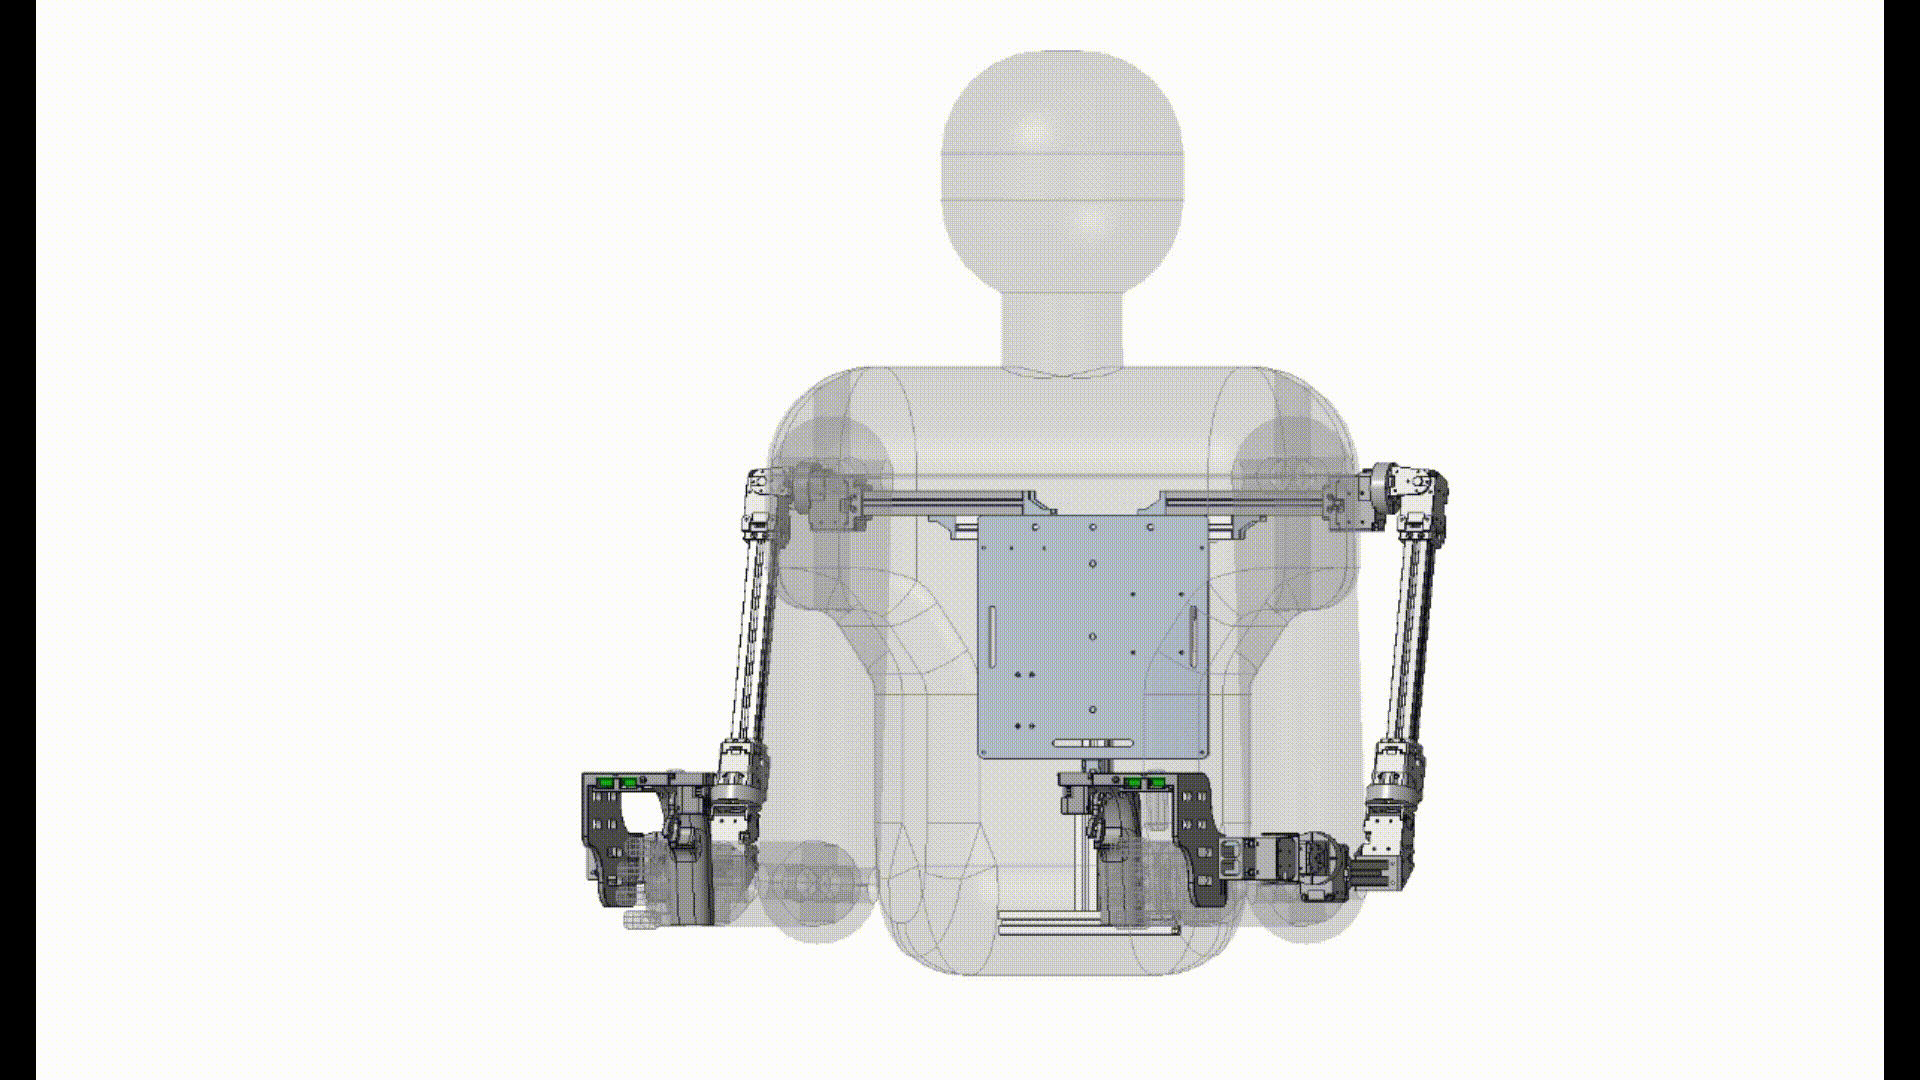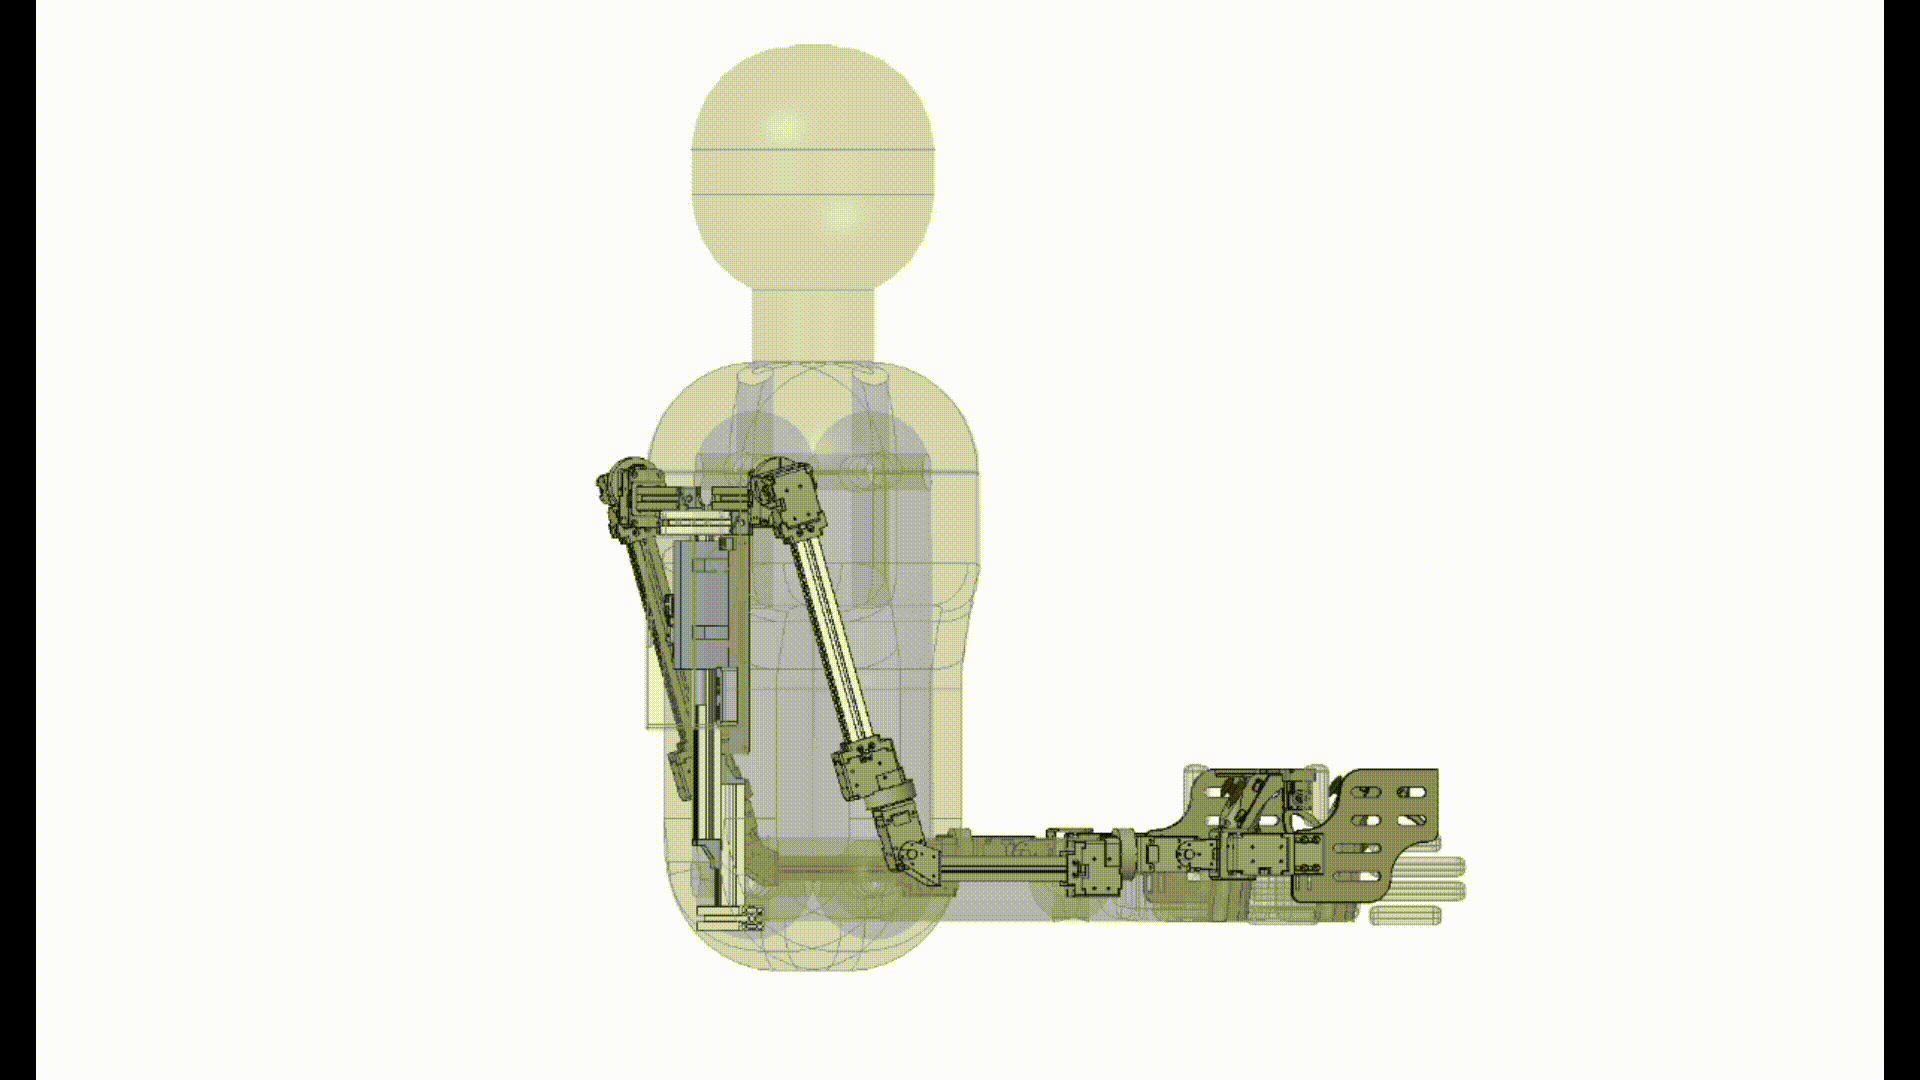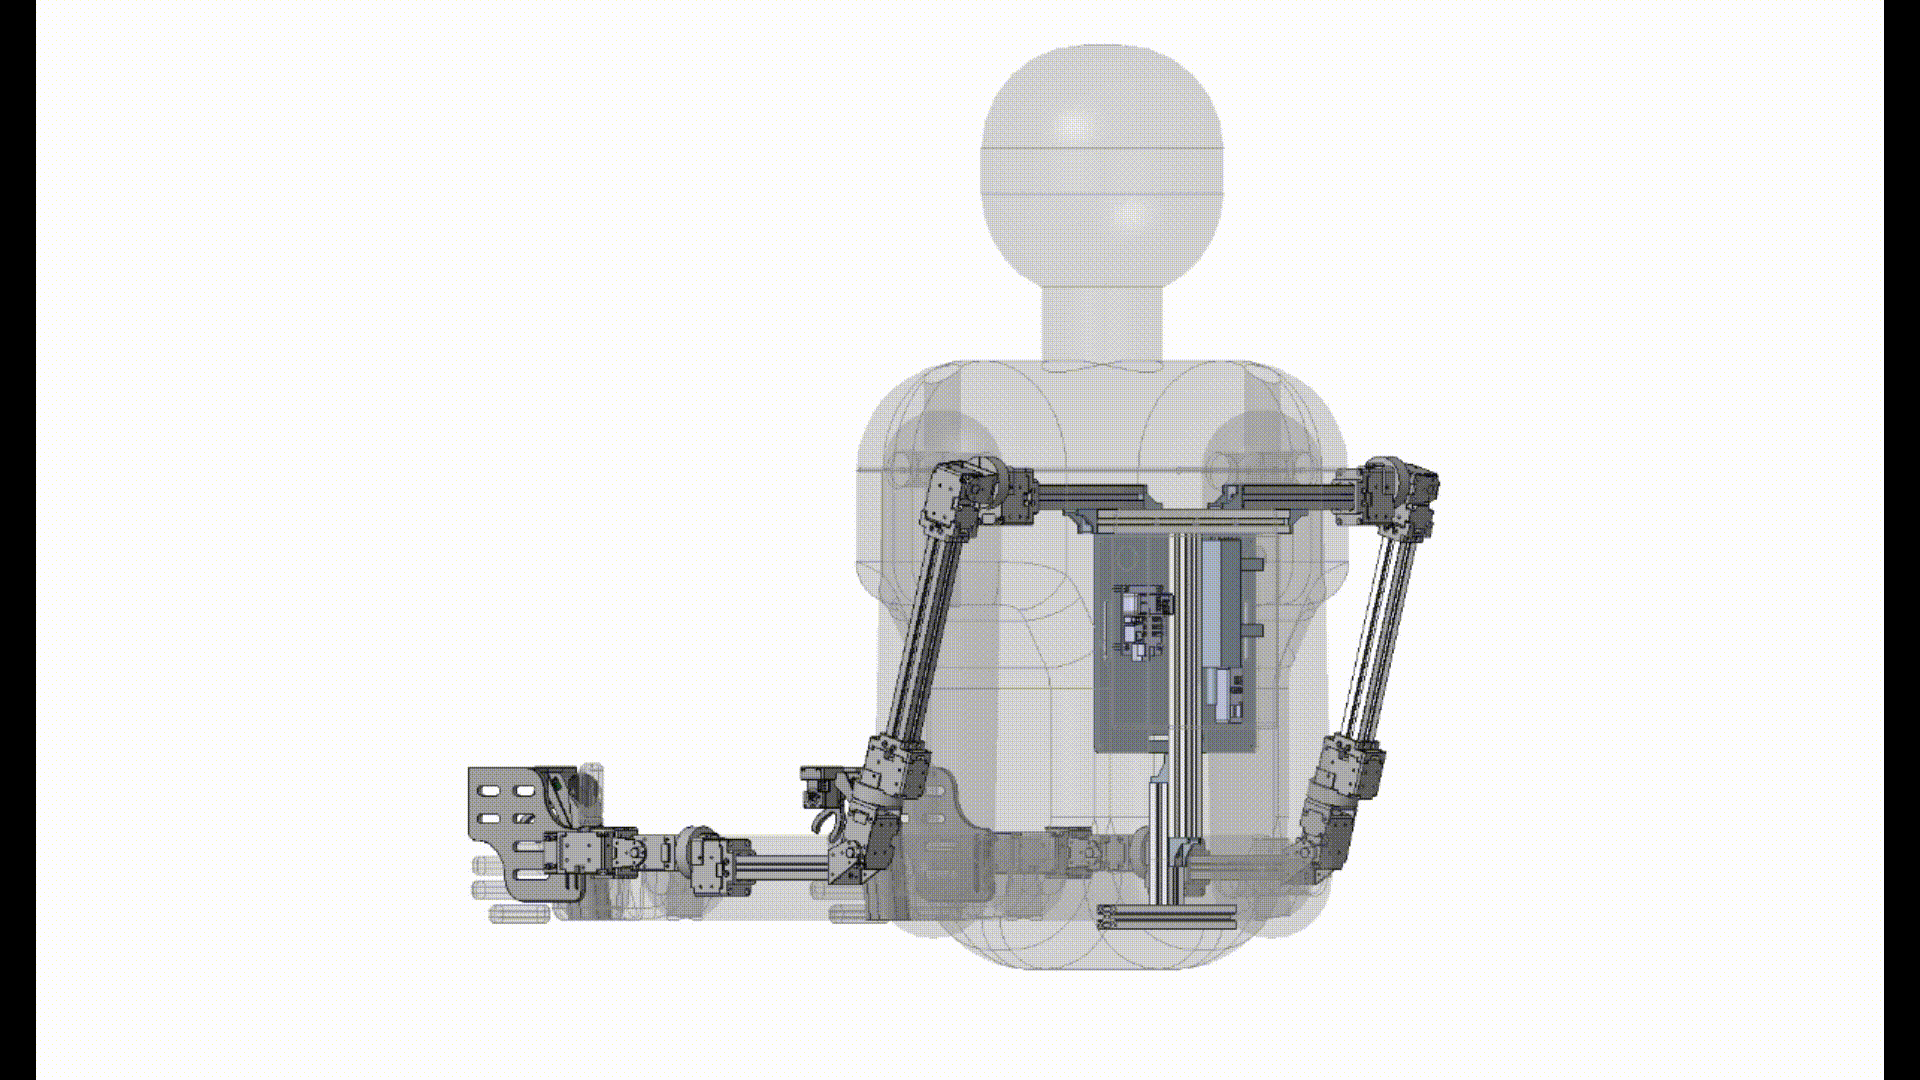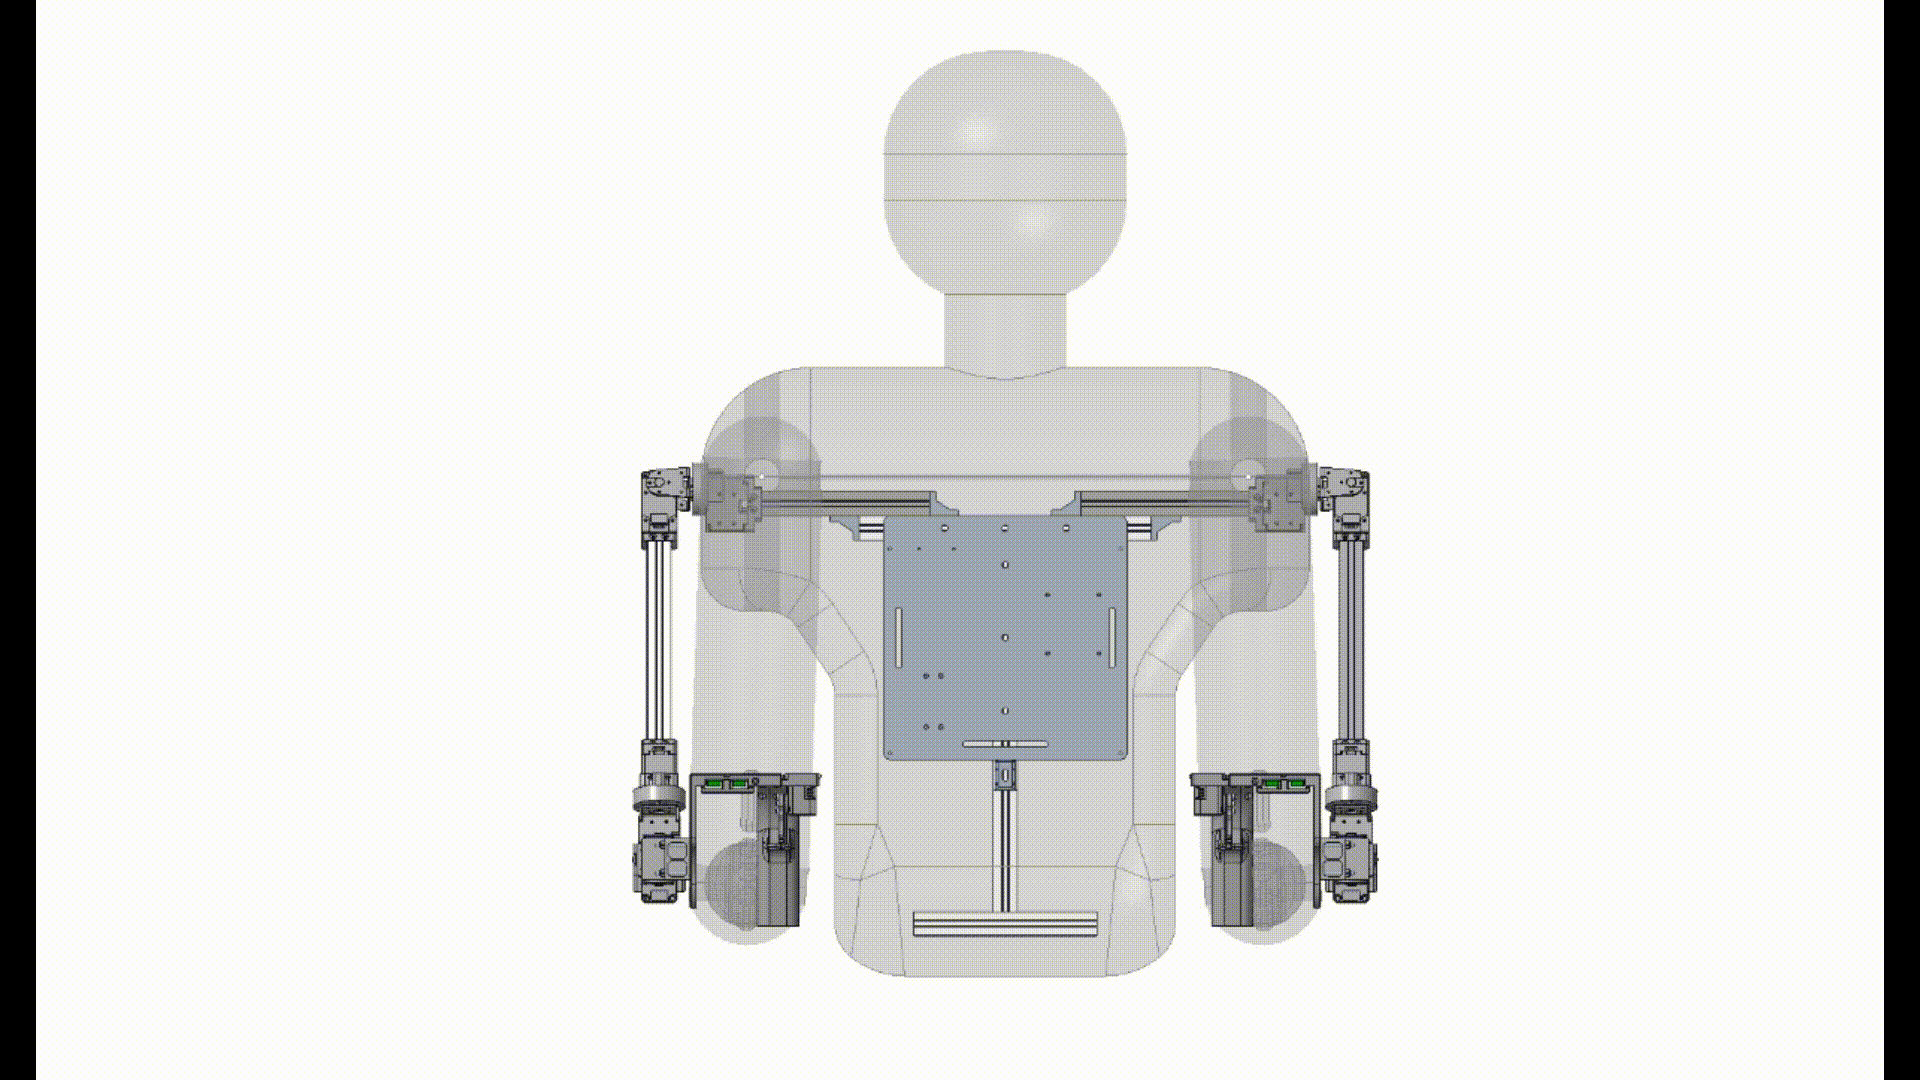
FFW-LH5 is currently in preparation for release.
- A1 / A2
- LG2 / FFW-LH5
| Properties | Specification (A1) | Specification (A2) |
|---|---|---|
| Dimensions (WxDxH) | 572.4x221.7x677.4 (mm) 22.5x8.7x26.7 (inch) | 401.7x190.3x502.8 (mm) 15.8x7.5x19.8 (inch) |
| Weight | 2.8 kg (6.17 lb) | 1 kg (2.2lb) |
| Actuator | Joint 1 ~ 7: Encoder Module | Joint 1 ~ 7: Dynamixel XL330-M077-T |
| Degrees of Freedom | - Total: 22 DOF - Arm: 7 DOF x 2 - Gripper: 1 DOF x 2 - Joystick: 3 DOF x 2 | - Total: 22 DOF - Arm: 7 DOF x 2 - Gripper: 1 DOF x 2 - Joystick: 3 DOF x 2 |
| Exterior Materials | Aluminum, Plastic | Aluminum, Plastic |
| Internal Communications | TTL | TTL |
| Communication Baudrate | 4 Mbps | 4 Mbps |
| Software | ROS 2 Support, Python, C++ | ROS 2 Support, Python, C++ |
| Properties | Specification (LG2) | Specification (FFW-LH5) |
|---|---|---|
| Dimensions (WxDxH) | 598x146x705 (mm) 23.5x5.7x27.8 (inch) | 597x211x842 (mm) 23.5x8.3x33.2 (inch) |
| Weight | 3 kg (6.6 lb) | 3 kg (6.6 lb) |
| Actuator | Joint 1 ~ 7: DYNAMIXEL-X | Joint 1 ~ 7: DYNAMIXEL-X |
| Degrees of Freedom | - Total: 22 DOF - Arm: 7 DOF x 2 - Gripper: 1 DOF x 2 - Joystick: 3 DOF x 2 | - Total: 60 DOF - Arm: 7 DOF x 2 - Hand: 20 DOF x 2 - Joystick: 3 DOF x 2 |
| Exterior Materials | Aluminum, Plastic | Aluminum, Plastic |
| Internal Communications | TTL | TTL |
| Communication Baudrate | 4 Mbps | 4 Mbps |
| Software | ROS 2 Support, Python, C++ | ROS 2 Support, Python, C++ |
DYNAMIXEL Details
The AI Worker utilizes various DYNAMIXEL actuators, each selected for specific joint applications:
- W1 / W2
- SG2 / BG2
| Joints | DYNAMIXEL Series | DYNAMIXEL Model |
|---|---|---|
| Arm Joints 1 ~ 2 | DYNAMIXEL-Y | YM080-230-R099-RH |
| Arm Joints 3 ~ 6 | DYNAMIXEL-Y | YM070-210-R099-RH |
| Arm Joint 7 | DYNAMIXEL-P | PH42-020-S300-R |
| Gripper | Robot Hands | RH-P12-RN |
| Head Pitch | DYNAMIXEL-X | XH540-V150-R |
| Head Yaw | DYNAMIXEL-X | XH430-V210-R |
| Lift | DYNAMIXEL-Y | YM080-230-B001-RH |
| Wheel Steer | DYNAMIXEL-Y | YM070-210-R051-RH |
| Joints | DYNAMIXEL Series | DYNAMIXEL Model |
|---|---|---|
| Arm Joints 1 ~ 3 | DYNAMIXEL-Y | YM080-230-R099-RH |
| Arm Joints 4 ~ 6 | DYNAMIXEL-Y | YM070-210-R099-RH |
| Arm Joint 7 | DYNAMIXEL-P | PH42-020-S300-R |
| Gripper | Robot Hands | RH-P12-RN |
| Head Pitch | DYNAMIXEL-X | XH540-V150-R |
| Head Yaw | DYNAMIXEL-X | XH430-V210-R |
| Lift | DYNAMIXEL-Y | YM080-230-B001-RH |
| Wheel Steer | DYNAMIXEL-Y | YM070-210-R051-RH |
For detailed specifications of each DYNAMIXEL model, please visit the ROBOTIS DYNAMIXEL website.
Gripper Specification

The RH-P12-RN is a multi-functional, 1-DOF two-fingered robot hand. It features an adaptive gripping design with passive joints, allowing it to grasp objects of various shapes. The hand utilizes a 10W DC motor and offers torque control and current-based position control, enabling it to handle objects made of different materials. Key features of the RH-P12-RN include its lightweight design (500g) and high payload capacity (5kg). It also has detachable fingertips that can be easily replaced with customized ones. The RH-P12-RN is designed for easy integration with the AI Worker platform, making it suitable for various applications in industrial environments.
Camera Specification
The AI Worker utilizes a multi-camera system for robust perception and manipulation capabilities.
Head Camera
A ZED Mini or Intel RealSense D455f camera is mounted on the head for wide-area environmental understanding and navigation.
- W1 / W2
- SG2 / BG2
| Feature | Specification |
|---|---|
| Model Name | Intel RealSense D455f |
| Type | Stereoscopic RGBD with 6DoF IMU |
| Key Use | Wide-angle depth perception, SLAM, obstacle avoidance |
| Field of View | 86°(H) x 57°(V) |
| Max Resolution | 1280 x 720 |
| Depth Range | 0.6m to 6m (23.62inch to 236.22inch) |
| More Information | Intel RealSense D455 |
| Feature | Specification |
|---|---|
| Model Name | Stereolabs ZED Mini |
| Type | Stereoscopic RGBD with 6DoF IMU |
| Key Use | Wide-angle depth perception, SLAM, obstacle avoidance |
| Field of View | 102°(H) x 57°(V) |
| Max Resolution | 1280 x 800 |
| Depth Range | 0.1m to 9m (3.9inch to 354.3inch) |
| More Information | Stereolabs ZED Mini Details |
Hand Cameras
Two Intel RealSense D405 cameras are integrated into the robot's hands/grippers, providing precise, short-range depth data for manipulation tasks.
- W1 / W2
- SG2 / BG2
| Feature | Specification |
|---|---|
| Model Name | Intel RealSense Depth Module D401 |
| Type | Stereoscopic RGBD |
| Key Use | Close-range depth sensing for grasping & manipulation |
| Field of View | 87°(H) × 58°(V) |
| Max Resolution | 1280 x 720 |
| Depth Range | 7cm to 50cm (2.7inch to 19.6inch) |
| More Information | Intel RealSense Depth Module D401 Details |
| Feature | Specification |
|---|---|
| Model Name | Intel RealSense D405 |
| Type | Stereoscopic RGBD |
| Key Use | Close-range depth sensing for grasping & manipulation |
| Field of View | 87°(H) × 58°(V) |
| Max Resolution | 1280 x 720 |
| Depth Range | 7cm to 50cm (2.7inch to 19.6inch) |
| More Information | Intel RealSense D405 Details |
LiDAR Specification
The AI Worker uses dual 2D ToF LiDAR sensors for robust long-range environment scanning and obstacle detection.
LiDAR: LakiBeam 1 (x2)
Two LakiBeam 1 units are mounted on the platform to provide wide horizontal coverage and reliable perception in industrial environments.
| Feature | Specification |
|---|---|
| Model Name | LakiBeam 1 |
| Type | 2D Single-line Pulsed ToF LiDAR |
| Key Use | Long-range environment perception, mapping, obstacle detection |
| Horizontal FOV | 270° |
| Detection Range | up to 25m (>=25m @ 90% reflectivity, >=15m @ 10% reflectivity) |
| Angle Resolution | 0.1° @ 10Hz / 0.25° @ 20/25/30Hz |
| Accuracy | ±2cm |
| Interface | Ethernet UDP / USB (RJ45, Type-C) |
| More Information | LakiBeam 1 Details |
Mobile Base Configuration (Swerve Drive)
The AI Worker's mobile base uses a swerve drive system that provides significant advantages over traditional omnidirectional wheel systems like mecanum wheels or omni wheels:
Advantages Over Omniwheels and Mecanum Wheels:
-
Superior Traction: Swerve drive uses conventional wheels with full surface contact, providing better grip and stability compared to omniwheels and mecanum wheels that have smaller rollers with limited ground contact.
-
Higher Efficiency: Without the passive rollers found in omniwheels and mecanum wheels, swerve drive transfers power more efficiently to the ground, resulting in better energy usage and longer operation time.
-
Greater Precision: Swerve drive offers more precise control over movement direction and velocity, as each wheel's steering and drive are independently controlled with no slip dynamics inherent to roller-based wheels.
-
Improved Load Capacity: The direct wheel contact allows swerve drive to handle heavier loads more effectively, making it ideal for industrial applications where the robot needs to carry or manipulate objects.
-
Better Performance on Various Surfaces: While omniwheels and mecanum wheels struggle on uneven surfaces or soft carpets, swerve drive maintains consistent performance across different floor types.
-
Reduced Vibration: The continuous wheel contact with the ground produces less vibration during movement, which is critical for tasks requiring precise manipulation.
The AI Worker's swerve drive configuration consists of three wheels positioned in a triangular arrangement, each with independent steering and driving capabilities:
- W1 / W2
- SG2 / BG2
| Part Name | Technical Name | Range |
|---|---|---|
| Right Wheel Steer | right_wheel_steer | -90° ~ 90° |
| Left Wheel Steer | left_wheel_steer | -90° ~ 90° |
| Rear Wheel Steer | rear_wheel_steer | -90° ~ 90° |
| Right Wheel Drive | right_wheel_drive | -360° ~ 360° |
| Left Wheel Drive | left_wheel_drive | -360° ~ 360° |
| Rear Wheel Drive | rear_wheel_drive | -360° ~ 360° |
| Part Name | Technical Name | Range |
|---|---|---|
| Right Wheel Steer | right_wheel_steer | -90° ~ 90° |
| Left Wheel Steer | left_wheel_steer | -90° ~ 90° |
| Rear Wheel Steer | rear_wheel_steer | -90° ~ 90° |
| Right Wheel Drive | right_wheel_drive | -360° ~ 360° |
| Left Wheel Drive | left_wheel_drive | -360° ~ 360° |
| Rear Wheel Drive | rear_wheel_drive | -360° ~ 360° |
Mechanical Specifications
Dimension
- W1
- W2
- A1
- A2
- BG2
- SG2
- LG2
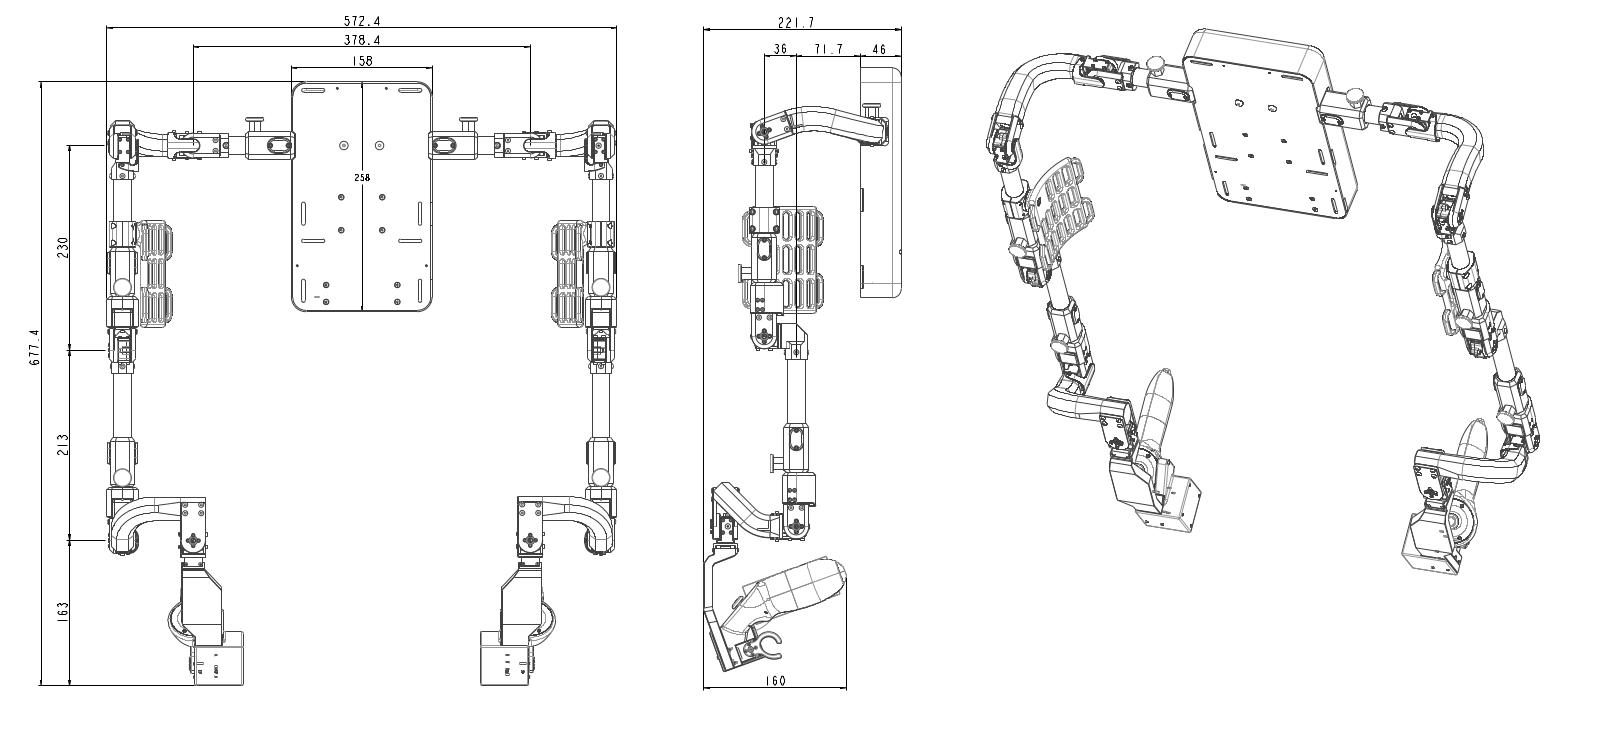
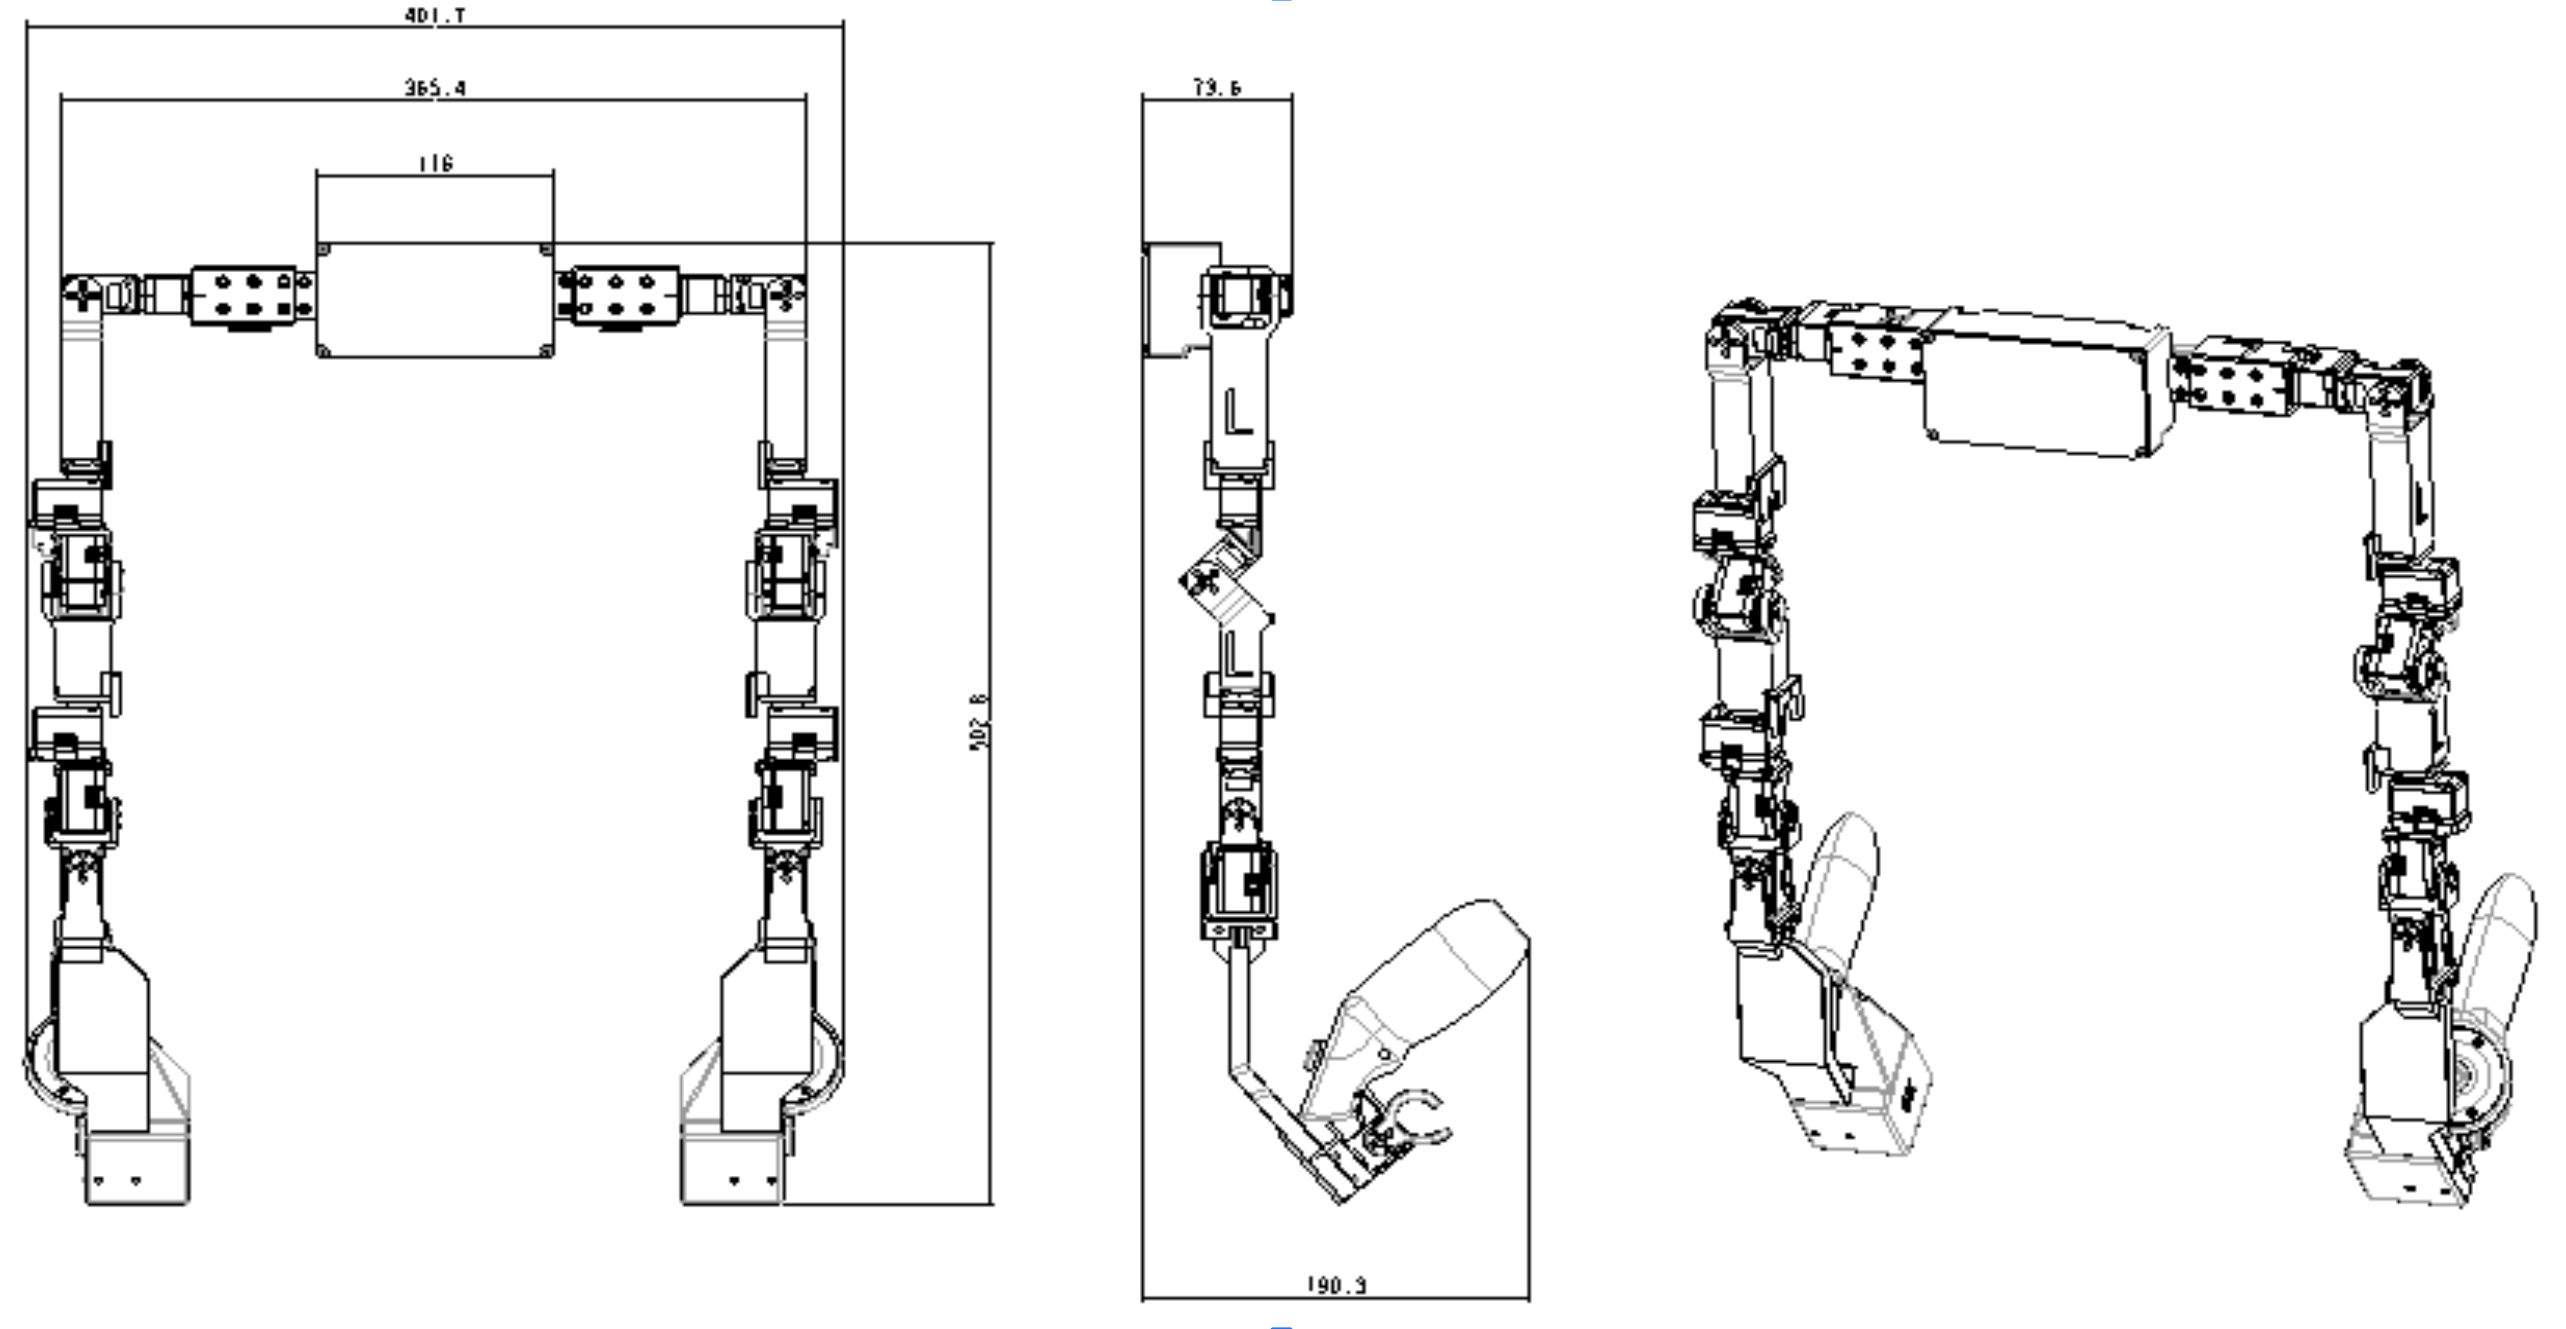
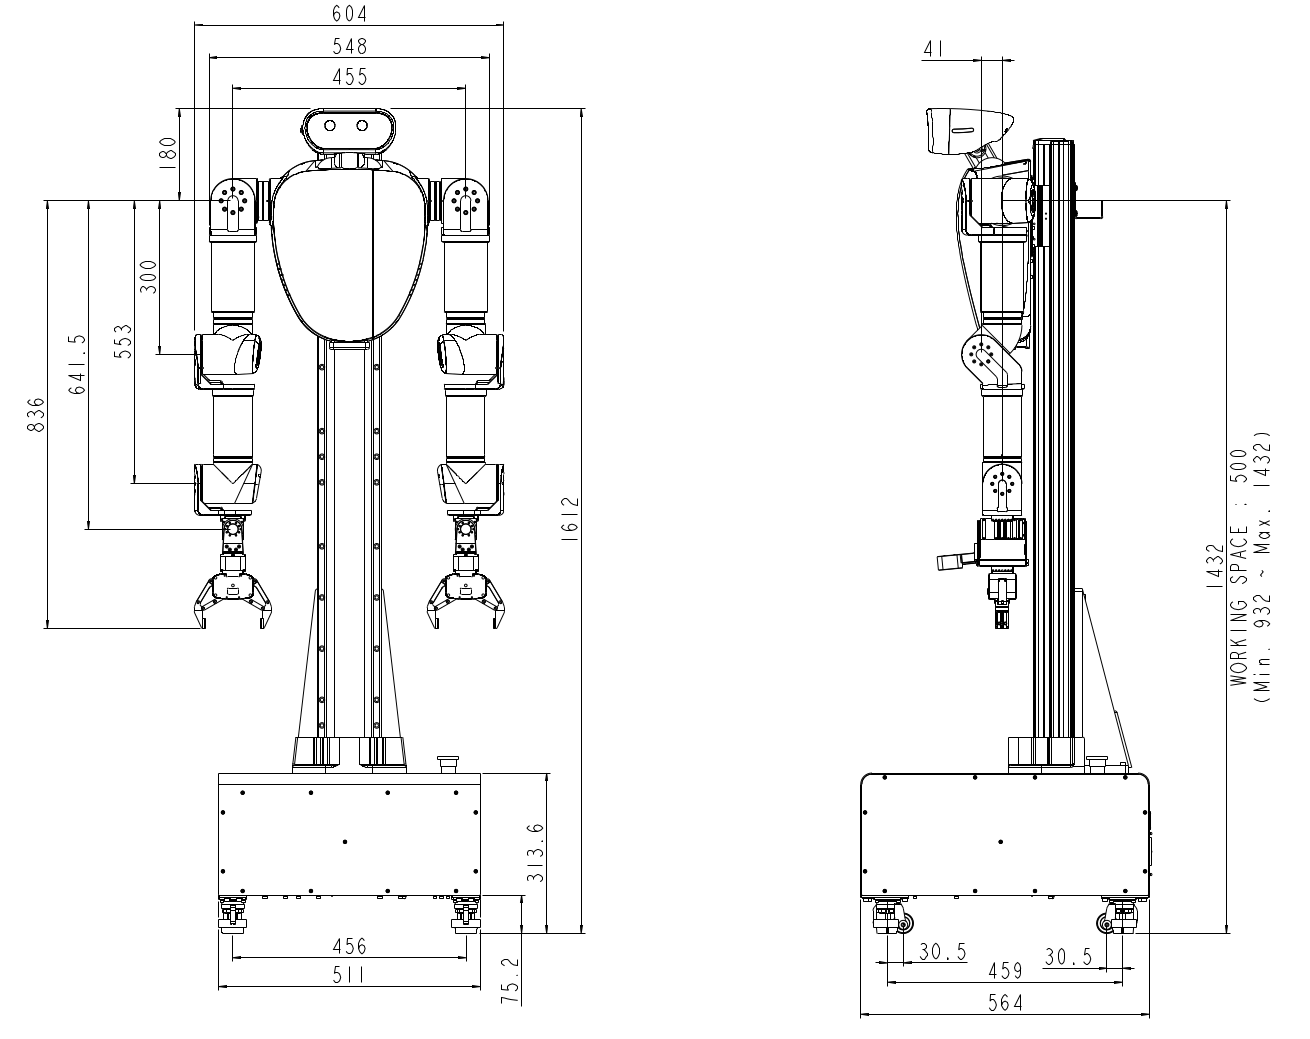
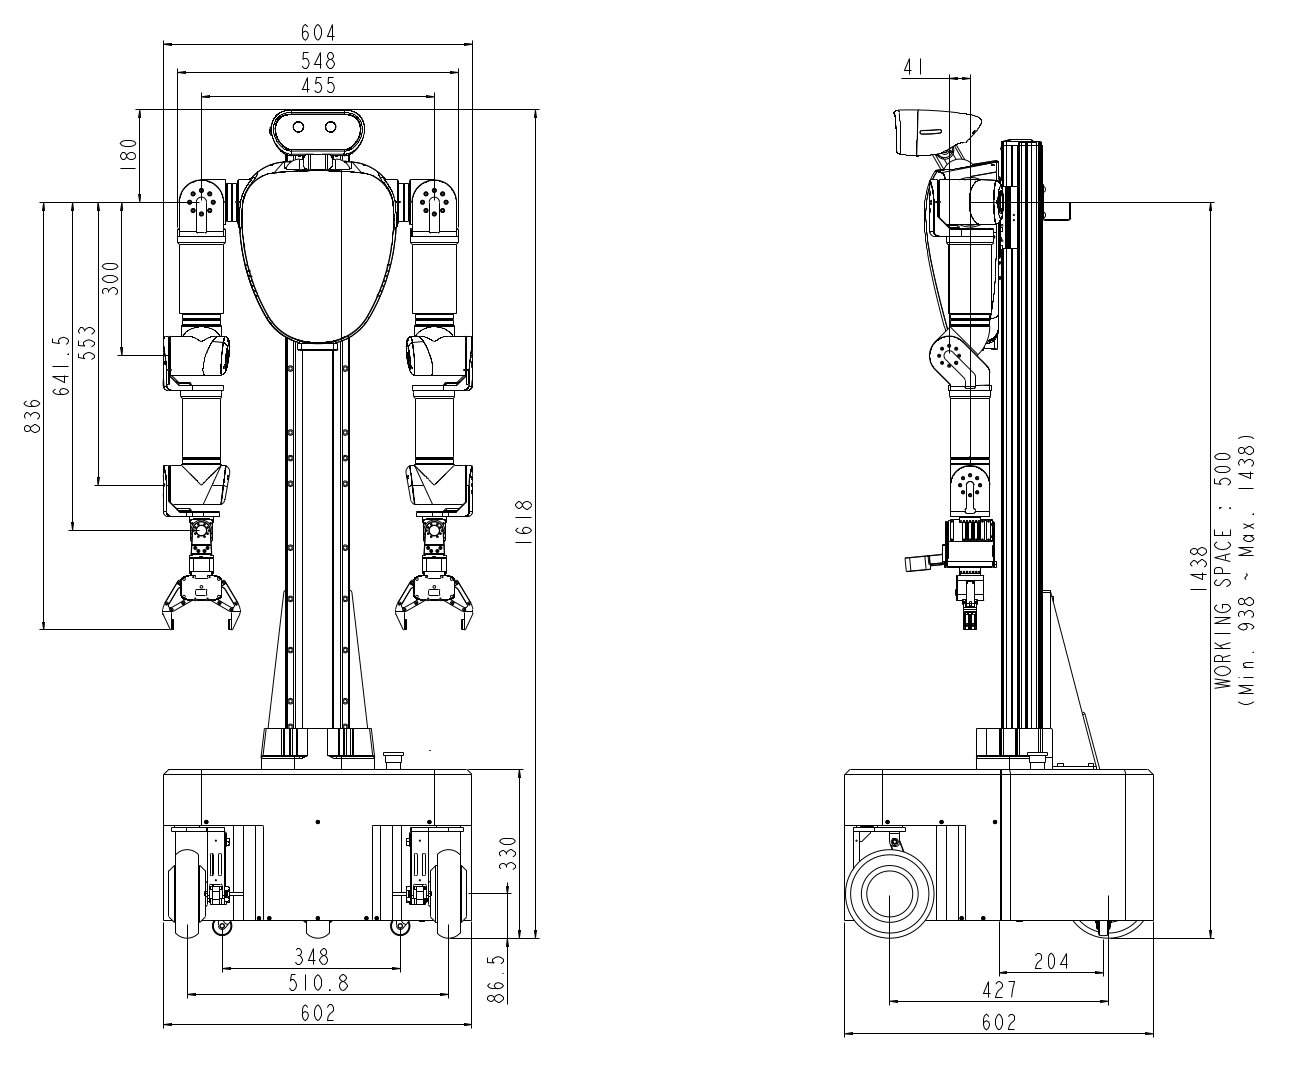
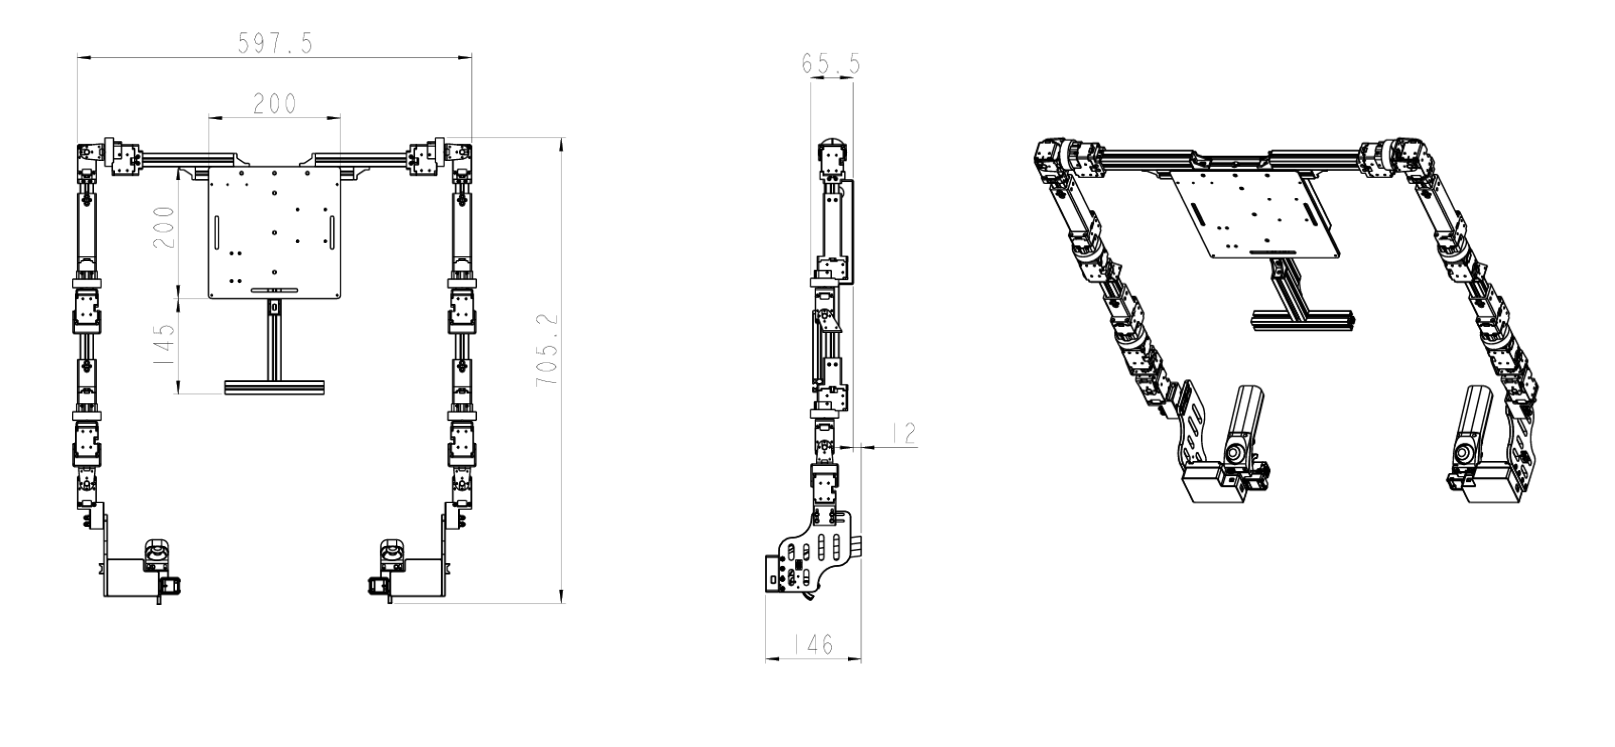
Joint Configuration and Nomenclature
- W1 / W2
- SG2 / BG2
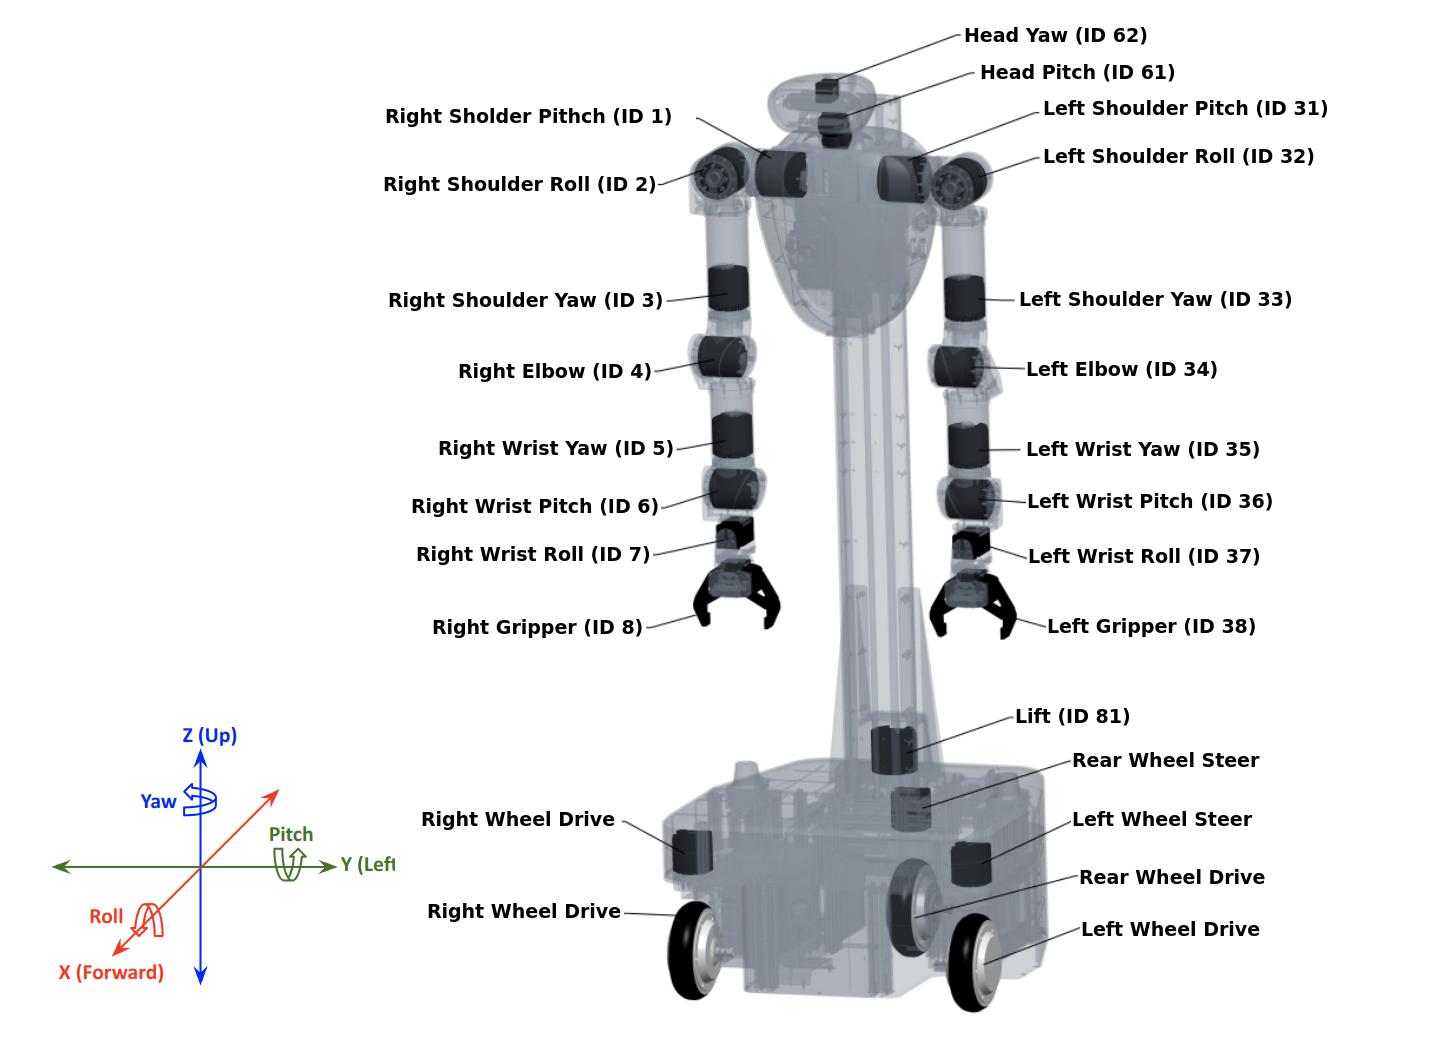
| ID | Joint Name | Technical Name | Range |
|---|---|---|---|
| 1 | Right Shoulder Pitch | arm_r_joint1 | -180° ~ 180° |
| 2 | Right Shoulder Roll | arm_r_joint2 | -190° ~ 10° |
| 3 | Right Shoulder Yaw | arm_r_joint3 | -180° ~ 180° |
| 4 | Right Elbow | arm_r_joint4 | -170° ~ 65° |
| 5 | Right Wrist Yaw | arm_r_joint5 | -180° ~ 180° |
| 6 | Right Wrist Pitch | arm_r_joint6 | -105° ~ 105° |
| 7 | Right Wrist Roll | arm_r_joint7 | -120° ~ 90° |
| 8 | Right Gripper | gripper_r_joint1 | 0 ~ 107.6 mm |
| 31 | Left Shoulder Pitch | arm_l_joint1 | -180° ~ 180° |
| 32 | Left Shoulder Roll | arm_l_joint2 | -10° ~ 190° |
| 33 | Left Shoulder Yaw | arm_l_joint3 | -180° ~ 180° |
| 34 | Left Elbow | arm_l_joint4 | -170° ~ 65° |
| 35 | Left Wrist Yaw | arm_l_joint5 | -180° ~ 180° |
| 36 | Left Wrist Pitch | arm_l_joint6 | -105° ~ 105° |
| 37 | Left Wrist Roll | arm_l_joint7 | -90° ~ 120° |
| 38 | Left Gripper | gripper_l_joint1 | 0 ~ 107.6 mm |
| 61 | Head Pitch | head_joint1 | -60° ~ 30° |
| 62 | Head Yaw | head_joint2 | -20° ~ 20° |
| 81 | Lift | lift_joint | 0 ~ 500 mm |
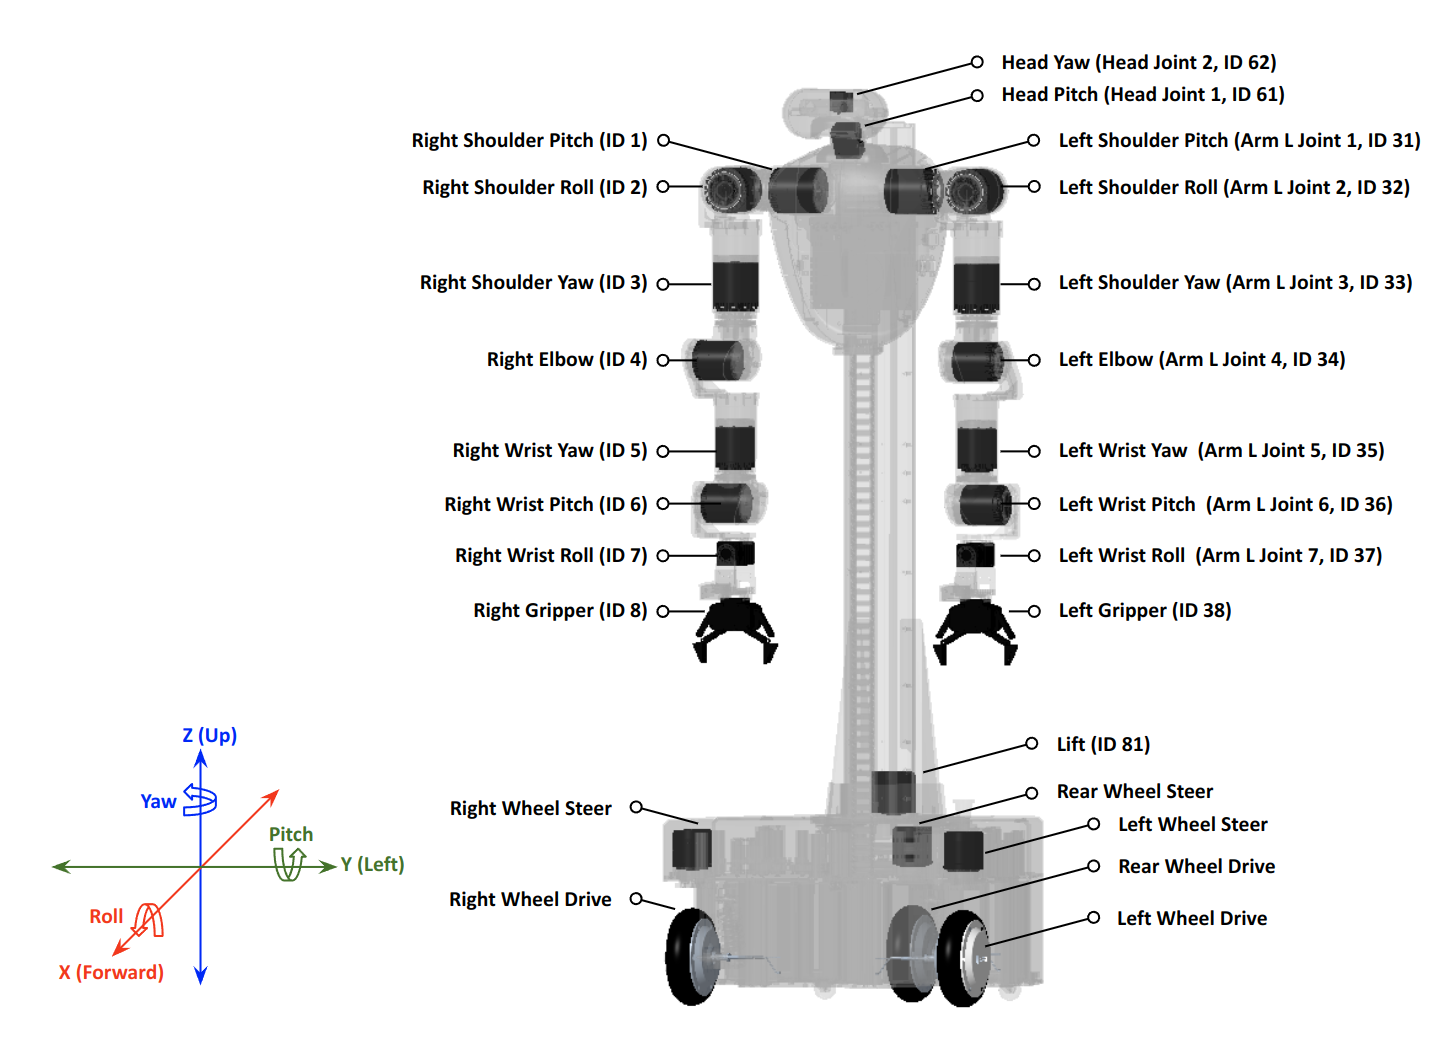
| ID | Joint Name | Technical Name | Range |
|---|---|---|---|
| 1 | Right Shoulder Pitch | arm_r_joint1 | -180° ~ 180° |
| 2 | Right Shoulder Roll | arm_r_joint2 | -190° ~ 10° |
| 3 | Right Shoulder Yaw | arm_r_joint3 | -180° ~ 180° |
| 4 | Right Elbow | arm_r_joint4 | -170° ~ 65° |
| 5 | Right Wrist Yaw | arm_r_joint5 | -180° ~ 180° |
| 6 | Right Wrist Pitch | arm_r_joint6 | -105° ~ 105° |
| 7 | Right Wrist Roll | arm_r_joint7 | -120° ~ 90° |
| 8 | Right Gripper | gripper_r_joint1 | 0 ~ 107.6 mm |
| 31 | Left Shoulder Pitch | arm_l_joint1 | -180° ~ 180° |
| 32 | Left Shoulder Roll | arm_l_joint2 | -10° ~ 190° |
| 33 | Left Shoulder Yaw | arm_l_joint3 | -180° ~ 180° |
| 34 | Left Elbow | arm_l_joint4 | -170° ~ 65° |
| 35 | Left Wrist Yaw | arm_l_joint5 | -180° ~ 180° |
| 36 | Left Wrist Pitch | arm_l_joint6 | -105° ~ 105° |
| 37 | Left Wrist Roll | arm_l_joint7 | -90° ~ 120° |
| 38 | Left Gripper | gripper_l_joint1 | 0 ~ 107.6 mm |
| 61 | Head Pitch | head_joint1 | -50° ~ 30° |
| 62 | Head Yaw | head_joint2 | -20° ~ 20° |
| 81 | Lift | lift_joint | 0 ~ 500 mm |
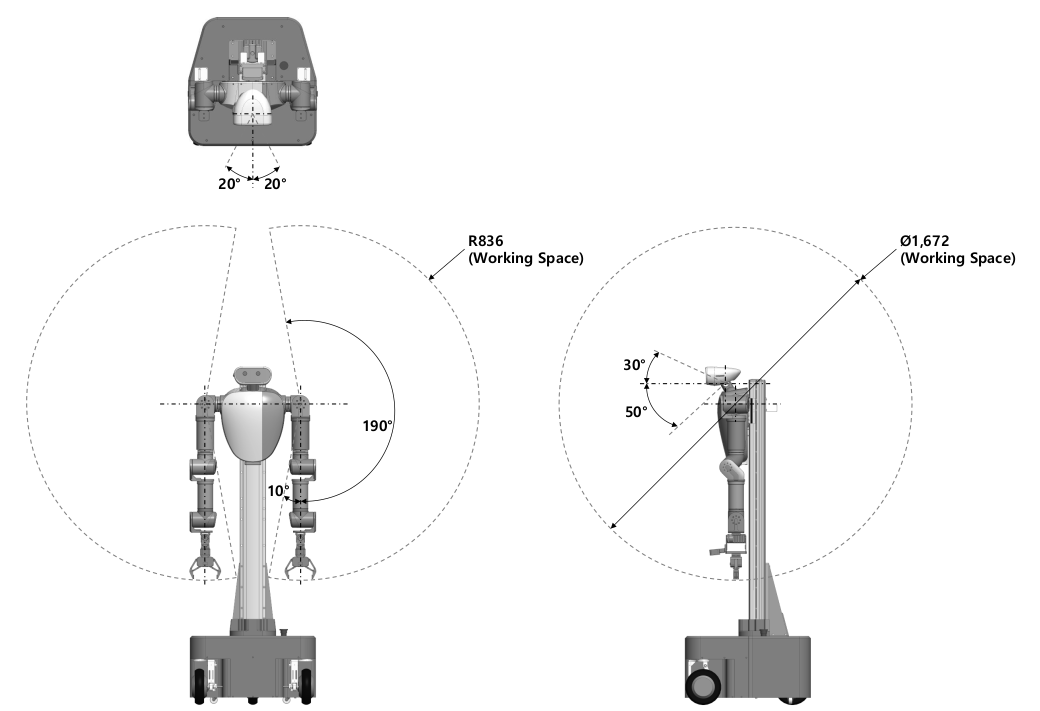
Workspace
- W1 / W2
- SG2 / BG2
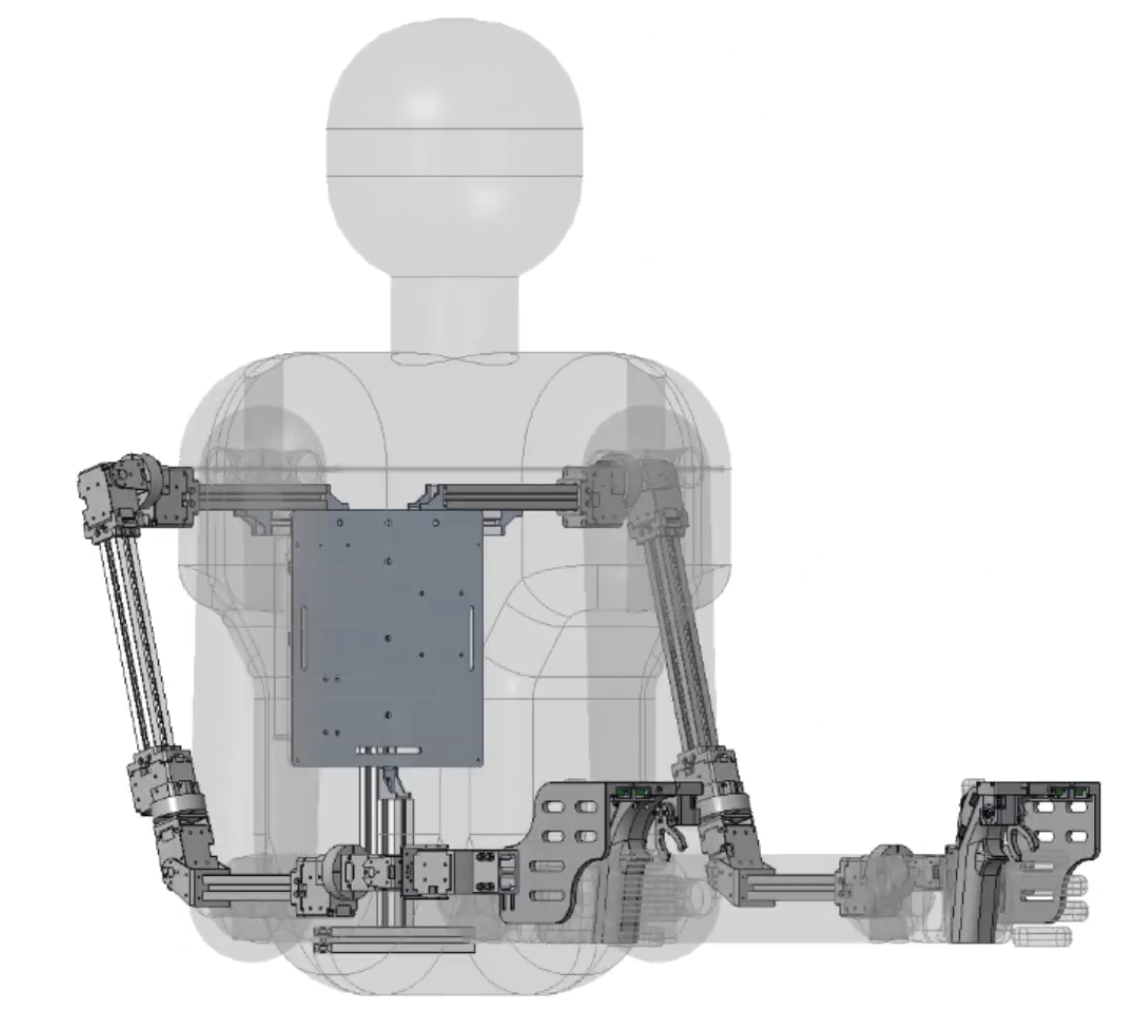
The torso workspace is the same for both W1 and W2 models.
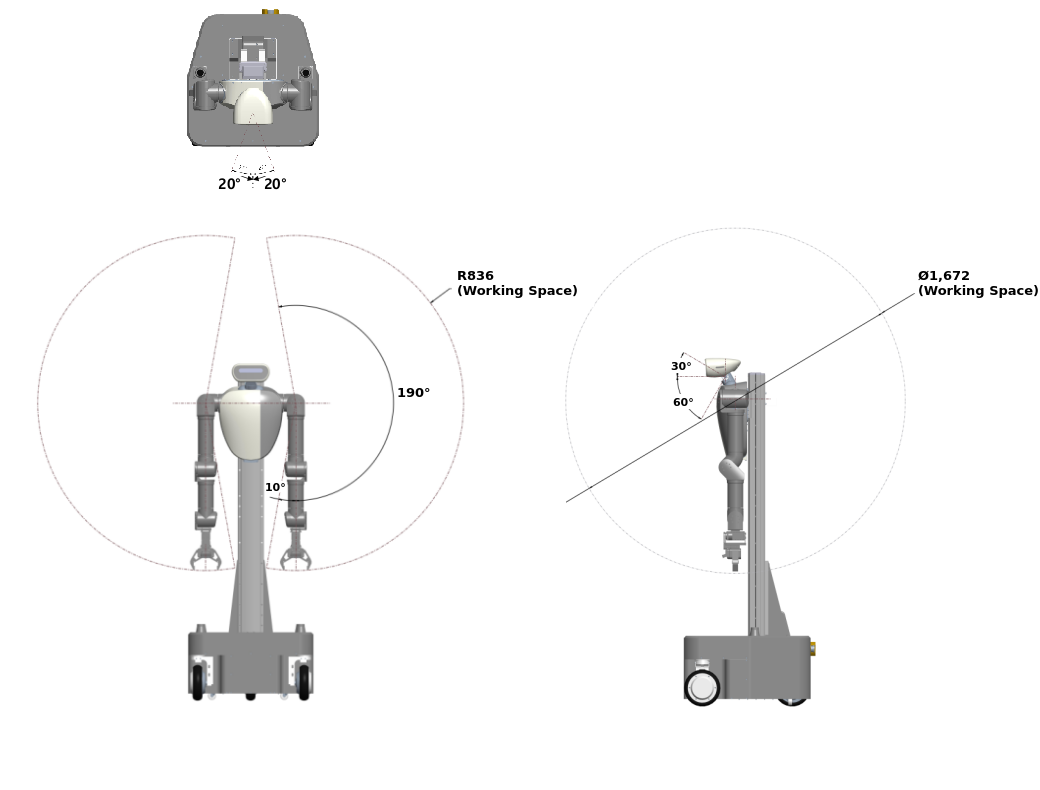
The torso workspace is the same for both SG2 and BG2 models.
Drawings and Downloads
| Resource | DWG | STEP | |
|---|---|---|---|
| W1 drawings | DWG | STEP | |
| W2 drawings | DWG | STEP | |
| BG2 drawings | DWG | STEP | |
| SG2 drawings | DWG | STEP | |
| LG2 drawings | — | — | STEP |
| W1 / W2 workspace | — | — | |
| SG2 / BG2 workspace | — | — |